Hackaday Links Column Banner

Hackaday Links: August 2, 2026

About a month ago, we brought you word that the commercial rescue mission designed by Katalyst Space to save NASA’s Swift gamma-ray observatory had reached orbit and early indicators were looking good. Unfortunately, it didn’t take long for things to start going sideways, and up until very recently, the situation seemed pretty dire. But according to an interview with Katalyst’s CEO published yesterday by Ars Technica, the company has made some impressive progress on getting things back under control.

For reasons unknown, the robotic vehicle started tumbling out of control last week. Shortly after that, mission controllers lost contact with Swift. After 24 hours without contact from the ground, the spacecraft automatically performed a sort of “hard reset” in an attempt to regain communications. That got it talking again, but somewhere along the way the craft overheated, which in turn cooked the control circuitry for the reaction wheels, which would usually be used to control its orientation. Not great, not terrible.

As of yesterday’s update, we now know that engineers have figured out a way to gimbal the thrust from the craft’s xenon-fueled electric thrusters — which were originally intended for orbit-raising — to counteract its spinning. It’s slow going as these thrusters don’t have a lot of kick, but it seems to be working. We’ll keep an eye on this one and let you know when we know more.
Continue reading “Hackaday Links: August 2, 2026”

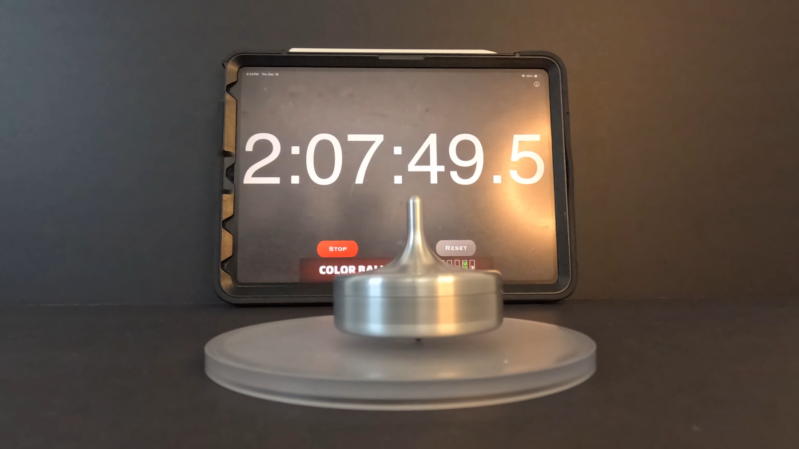
An aluminium top is shown spinning on a plastic disk in front of a tablet showing the text "2:07:49.5"

Self-Powered Top Spins For Hours

The meaning of Inception’s ending famously revolves around a top which spins forever in dreams, but in real life comes to a stop like any other top. Any other top, that is, except for [Aaed Musa]’s self-spinning top, which can continuously spin for about two hours before coming to a stop.

The one constraint was that every functional component had to be contained within the top’s shell, and [Aaed]’s first approach was to build a reaction wheel into the top. When a motor accelerates a weighted wheel, conservation of angular momentum applies an equal and opposite torque to the motor. The problem is that motors eventually reach a top speed and stop accelerating, which puts an end to the torque. This is known as saturation, and the only way to desaturate a reaction wheel is to slow it down, which counteracts the originally generated torque. [Aaed] originally planned to mount the motor in a one-way bearing, which would let it bleed off speed without producing torque against the rest of the top, but it was rather choppy in practice.

The solution occurred to [Aaed] while watching the aforementioned final scene, when it occurred to him that the wobbling of a top could actually generate rotation. A prototype proved that an off-center weight rotating at a constant speed did successfully spin the top by rotating the center of mass, and after that, it was a matter of incremental testing and improvement. A higher moment of inertia worked better, as did a lower center of gravity and a tip made from a hard, low-friction silicon nitride ball bearing. He made housings out of both 3D-printed plastic and CNC-milled aluminium, which each contained a tiny brushless motor, an electric speed controller, a microcontroller, and a small rechargeable lithium battery.

If you allow for external power, you can make the top itself the rotor of a motor, and drive it from a base. Alternatively, if you levitate your top in a vacuum, it could spin for longer than recorded history.

Tackling Tremors With DIY Technology

[It’s Triggy!] had a problem to solve. His grandma was having issues with hand tremors, which made the basic tasks of daily life difficult to perform. He decided to explore whether a high-tech solution could help best the tremors and make life easier.

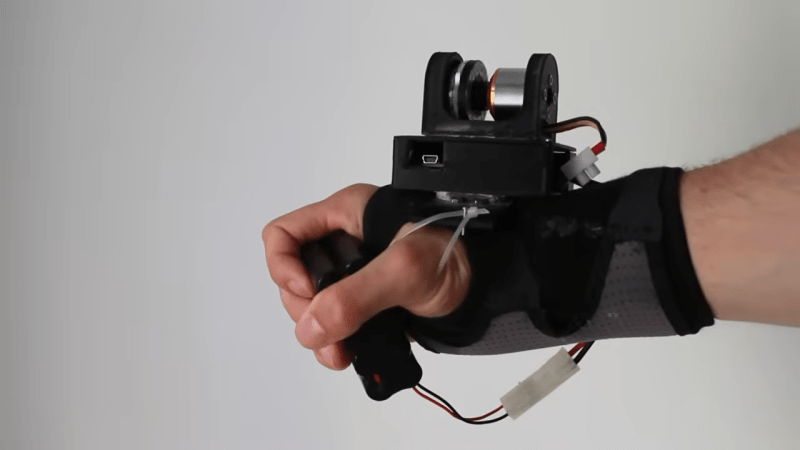
The video covers multiple ideas on how to stabilize a hand suffering involuntary tremors. The first build involved a gyroscope, which proved unsuccessful, but led to the idea of building a reaction wheel. The concept is simple — get the reaction wheel to counteract the forces from tremors to stabilize the hand. To achieve this, an accelerometer was employed to track the movements of the arm and the hand. The magnitude of the movement was then used to control a powerful brushless motor mounted on the wrist. If the tremor was driving a hard tilt to the left, the motor would spin up to create a counter-torque, cancelling out the involuntary movement. This worked to a degree, but the resulting device was large and noisy, which made it impractical.

This thus inspired a return to earlier work involving the use of a tuned mass damper to settle tremors. The combination of some 3D printed wrist mounts along with various spring and cantilever designs… ultimately didn’t work that well. By this point, [It’s Triggy!] had noticed the tremor was mostly in the hands, while the wrist stayed steady. Thus was inspired a wrist-mounted handle for the wearer to wrap their hand around. This allowed the use of simple handheld objects like kitchen utensils, with the wearer’s own grip suppressing the tremor successfully.

As this project demonstrates, sometimes high-tech solutions are the way to go, and other times… a more passive design will actually serve you better.

Continue reading “Tackling Tremors With DIY Technology”

Space-Based Datacenters Take The Cloud Into Orbit

Where’s the best place for a datacenter? It’s an increasing problem as the AI buildup continues seemingly without pause. It’s not just a problem of NIMBYism; earthly power grids are having trouble coping, to say nothing of the demand for cooling water. Regulators and environmental groups alike are raising alarms about the impact that powering and cooling these massive AI datacenters will have on our planet.

While Sam Altman fantasizes about fusion power, one obvious response to those who say “think about the planet!” is to ask, “Well, what if we don’t put them on the planet?” Just as Gerard O’Neill asked over 50 years ago when our technology was merely industrial, the question remains:

“Is the surface of a planet really the right place for expanding technological civilization?”

O’Neill’s answer was a resounding “No.” The answer has not changed, even though our technology has. Generative AI is the latest and greatest technology on offer, but it turns out it may be the first one to make the productive jump to Earth Orbit. Indeed, it already has, but more on that later, because you’re probably scoffing at such a pie-in-the-sky idea.

There are three things needed for a datacenter: power, cooling, and connectivity. The people at companies like Starcloud, Inc, formally Lumen Orbit, make a good, solid case that all of these can be more easily met in orbit– one that includes hard numbers.

Sure, there’s also more radiation on orbit than here on earth, but our electronics turn out to be a lot more resilient than was once thought, as all the cell-phone cubesats have proven. Starcloud budgets only 1 kg of sheilding per kW of compute power in their whitepaper, as an example. If we can provide power, cooling, and connectivity, the radiation environment won’t be a showstopper.

Continue reading “Space-Based Datacenters Take The Cloud Into Orbit”

Balancing Robot Gallery

Cube Teeter Totter: One Motor, Many Lessons

Balancing robots are always fun to see, as they often take forms we’re not used to, such as a box standing on its corner. This project, submitted by [Alexchunlin], showcases a cool single motor reaction cube, where he dives into many lessons learned during its creation.

At the outset, [Alexchunlin] thought this would be a quick, fun weekend project, and while he achieved that, it took longer than a weekend in the end. The cube’s frame was a simple 3D print with provisions to mount his MotorGo AXIS motor controller. This motor controller was initially designed for another project, but it’s great to see him reuse it in this build.

Once the parts were printed and assembled, the real work began: figuring out the best way to keep the cube balanced on its corner. This process involved several steps. The initial control code was very coarse, simply turning the motor on and off, but this didn’t provide the fine control needed for delicate balancing. The next step was implementing a PID control loop, which yielded much better results and allowed the cube to balance on a static surface for a good amount of time. The big breakthrough came when moving from a single PID loop to two control loops. In this configuration, the PID loop made smaller adjustments, while another control loop focused on the system’s total energy, making the cube much more stable.

By the end of the build, [Alexchunlin] had a cube capable of balancing in his hand, but more importantly, it was a great learning experience in controls. Be sure to visit the project page for more details on this build and check out his video below, which shows the steps he took along the way. If you find this project interesting, be sure to explore some of our other featured reaction wheel projects.

Continue reading “Cube Teeter Totter: One Motor, Many Lessons”

Two rings of magnets are shown encasing a circular channel in a white plastic piece. The channel is filled with liquid metal, and a loop of wire is about to be lowered into the metal.

Magnetohydrodynamic Motors To Spin Satellites

Almost all satellites have some kind of thrusters aboard, but they tend to use them as little as possible to conserve chemical fuel. Reaction wheels are one way to make orientation adjustments without running the thrusters, and [Zachary Tong]’s liquid metal reaction wheel greatly simplifies the conventional design.

Reaction wheels are basically flywheels. When a spacecraft spins one, conservation of angular momentum means that the wheel applies an equal and opposite torque to the spacecraft, letting the spacecraft orient itself. The liquid-metal reaction wheel uses this same principle, but uses a loop of liquid metal instead of a wheel, and uses a magnetohydrodynamic drive to propel the metal around the loop.

[Zach] built two reaction wheels using Galinstan as their liquid metal, which avoided the toxicity of a more obvious liquid metal. Unfortunately, the oxide skin that Galinstan forms did make it harder to visualize the metal’s motion. He managed to get some good video, but a clearer test was their ability to produce torque. Both iterations produced a noticeable response when hung from a string and activated, and achieved somewhat better results when mounted on a 3D-printed air bearing.

Currently, efficiency is the main limitation of [Zach]’s motors: he estimates that the second model produced 6.2 milli-newton meters of torque, but at the cost of drawing 22 watts. The liquid metal is highly conductive, so the magnetohydrodynamic drive takes high current at low voltage, which is inconvenient for a spacecraft to supply. Nevertheless, considering how hard it is to create reliable, long-lasting reaction wheels the conventional way, the greatly improved resilience of liquid-metal reaction wheels might eventually be worthwhile.

If you’re curious for a deeper look at magnetohydrodynamic drives, we’ve covered them before. We’ve also seen [Zach]’s earlier experiments with Galinstan.

Continue reading “Magnetohydrodynamic Motors To Spin Satellites”

A Transparent BB-8 Build Using Christmas Ornaments

The cool thing about the droids of Star Wars is that they’re not that hard to recreate in real life. R2-D2 is a popular choice, but you can even build yourself a neat little BB-8 if you’re so inclined. [Piyush] has built a particularly compelling example that’s transparent, which lets you see the internals and how it all works.

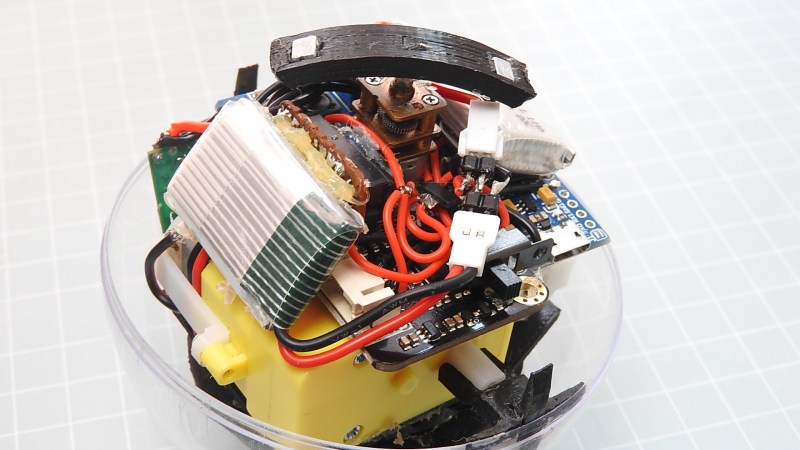
The build makes creative use of a pair of Christmas ornaments. They are perhaps the cheapest and easiest way to source a clear plastic sphere. One serves as the “head”, while the other serves as the larger spherical body. Inside, an Arduino Pro Micro is running the show. It’s hooked up to a L293D motor driver which runs the drive motors and the reaction wheel motor which provides stability, while a separate MOSFET is on hand to run the gear motor which controls the head.

There’s also an HC-05 module for Bluetooth communication, and a BNO055 sensor for motion tracking and ensuring the robot stays the right way up. 3D printed components are used prodigiously to cram everything together tightly enough to fit. There’s even a printed charging base to juice up the little droid. Controlling the robot is as simple as using a smartphone with an app created in the MIT App Inventor.

If you’ve never built a spherical rolling robot before—and few of us have—this design is a great reference for your own work. We’ve seen a few BB-8s over the years, most of which dropped shortly after the movie was released. Continue reading “A Transparent BB-8 Build Using Christmas Ornaments”