Hairy Armor For Combat Robot? It’s Not Terrible!

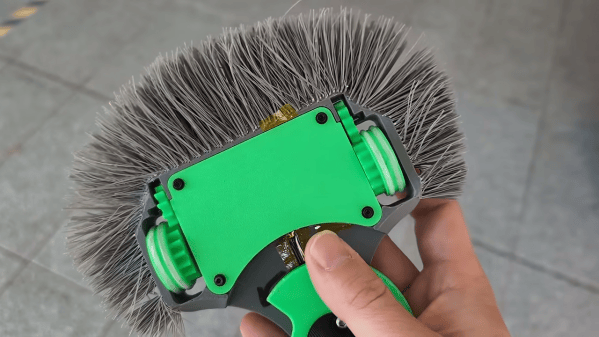
[Angus] of Maker’s Muse enjoys combat robotics, in which contenders zip about in an arena, attempting to disable one another with weapons that lift, spin, and smash. He got a funny idea a short while ago and wondered whether a stiff mane of bristles could serve as lightweight, ablative, impact resistant armor?

Just to set the stage, [Angus]’s new robot competes in the plastic antweight (or “plant”) division, in which robots are limited to 150 grams with both chassis and weapons made of plastic. In such circumstances, one can see how a mane of thick, rigid “hairs” might actually punch above its weight, so to speak.
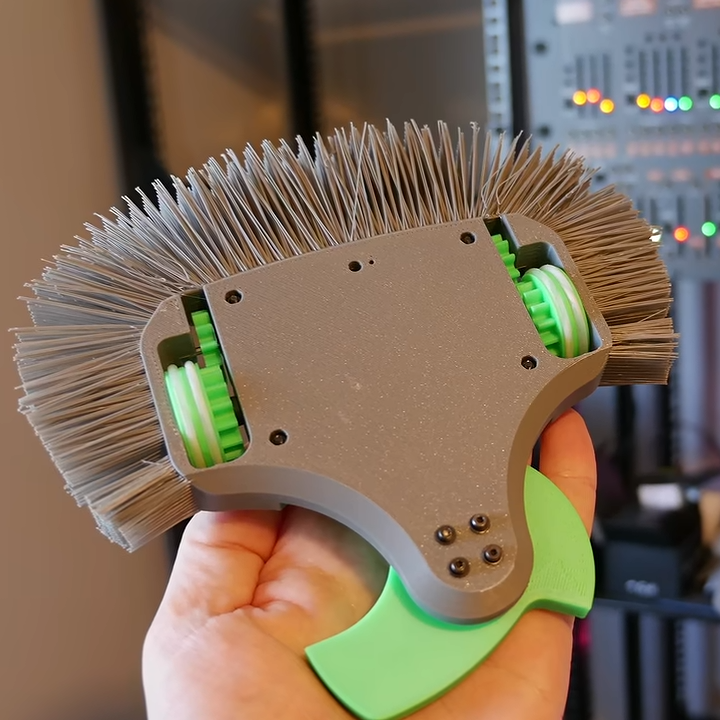
The green shape at the bottom is a spinning weapon. The bristles cover the sides and rear.

Nothing settles a question like a good experiment, so [Angus] sat down and redesigned his latest robot to replace its outer shell with a thick wad of bristles, in the style of a 3D printed lion’s mane. Filament is bridged between the model and an outer support structure, which is cut away afterwards to expose the “hairs”.

How well did it perform? Well enough to merit further study! Where past robots got their outer shells broken up, the hairy robot seems to have come through quite intact. It seems the idea might not be as silly as it first seemed, at least in the plastic antweight division.

3D printers have been fantastic in the field of combat robotics. First they were great because they made custom parts easier and more accessible to hobbyists, but things have evolved more since then. Now folks compete by putting motors and electronics inside almost entirely 3D printed robots. There’s never been a better time to get into combat robotics, and experiment with unorthodox designs.

If you want to try a hairy robot for yourself, be sure to watch the followup in which [Angus] improves the hair-generating process considerably.
Antweight Combat Robot Tips, Shared From Experience

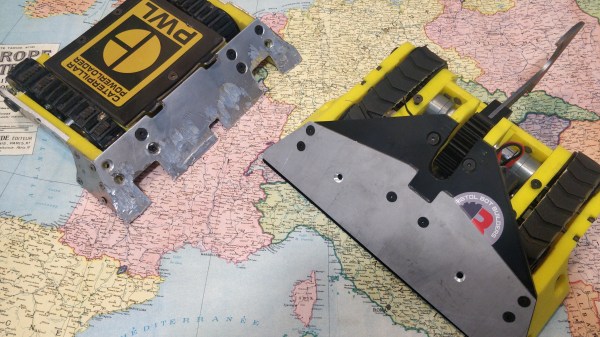
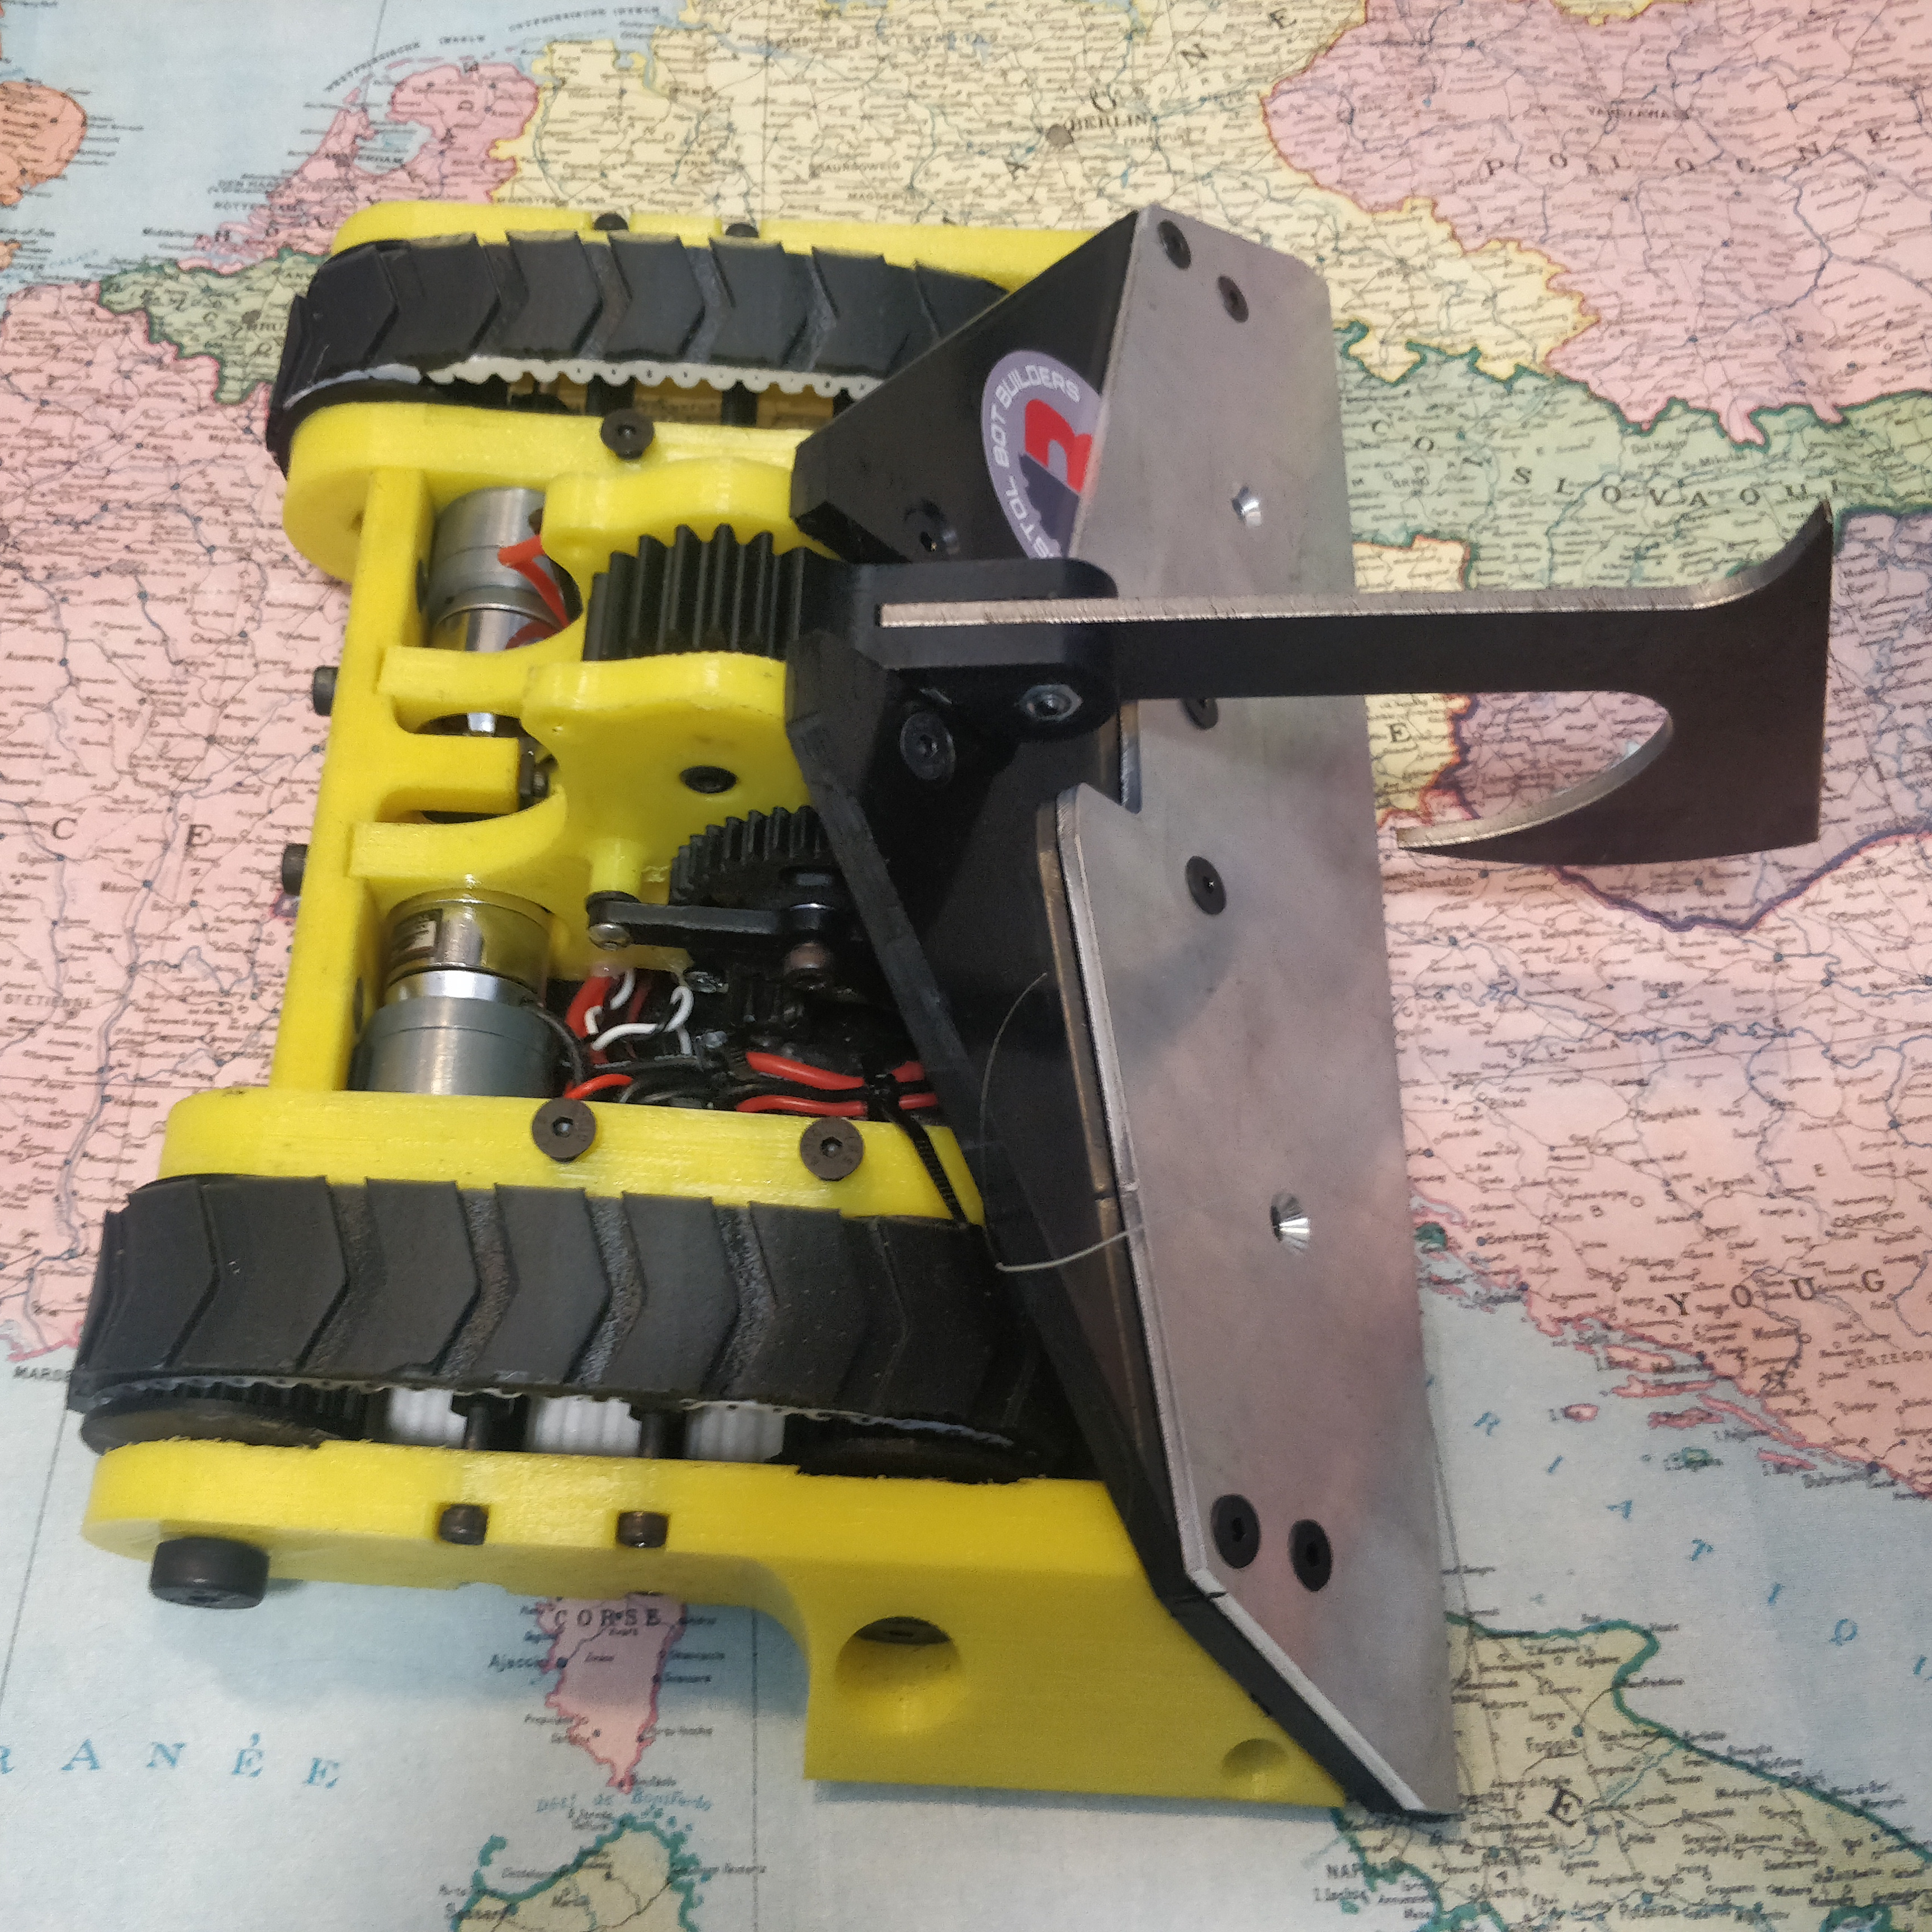
[Harry]’s newest robot, the MotherLoader V2, looks fantastic but was ultimately more of a learning experience and test bed for some experimental features. Luckily for us, [Harry] created a lengthy write-up detailing everything that he tried and revised.

3D printing and aluminum both feature heavily in antweight robots, in part because when contestants are limited to 150 grams it’s safe to say that every bit counts. We recommend reading [Harry]’s entire article to get all the details, but here are some of the bigger takeaways.

Treads provide a lot of contact surface, but there are a lot of ways they can go wrong. Pliability and grip have to be good matches for the robot’s design, otherwise the tread might bunch up or otherwise perform poorly when trying to maneuver. [Harry] had several dud efforts, but ended up with a great result by borrowing an idea from another competitor: composite tracks.

These have an inner track printed from flexible TPU filament, and an outer layer formed by casting silicone directly onto the 3D printed core. It’s a somewhat involved process, but the result is a durable and custom-fitted inner track on the inside, and a softer grip outside. Best of both worlds, and easily tailored to match requirements.

Speaking of TPU, [Harry] discovered that it can be worth printing structural parts with TPU. While ABS is usually the material of choice for durable components, printing solid parts in TPU has a lot to recommend it when it comes to 150 gram robots. Not only can TPU parts be stiff enough to hold up structurally, but they can really take a beating and happily spring back into shape afterwards.

We’ve seen [Harry]’s work before on antweight combat robots, and it’s always nice to peek behind the scenes and gaze into the details. Especially for processes like this, where failures are far more educational than successes.

A Crowned Pulley Keeps Robot’s Treads On Track

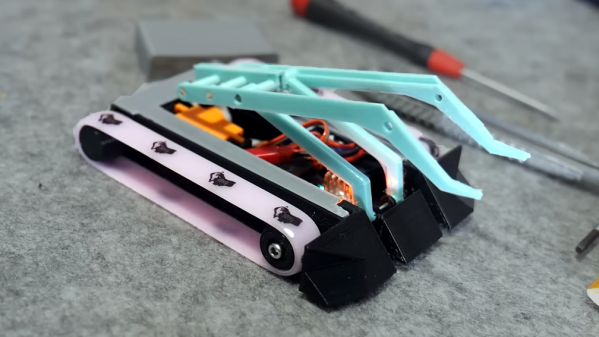
[Angus] at Maker’s Muse recently created a new and tiny antweight combat robot (video, embedded below) and it has some wonderfully clever design elements we’d like to highlight. In particular: how to keep a tracked robot’s wheel belt where it belongs, and prevent it from slipping or becoming dislodged. In a way, this problem was elegantly solved during the era of the steam engine and industrial revolution. The solution? A crowned pulley.

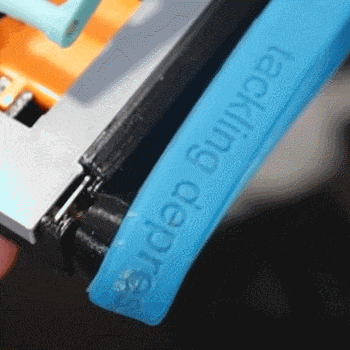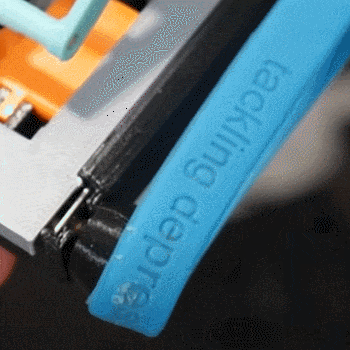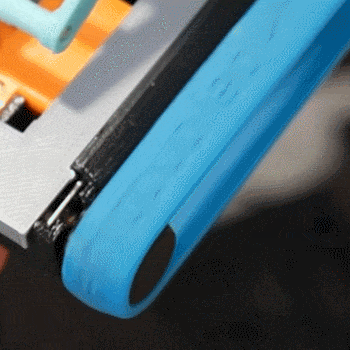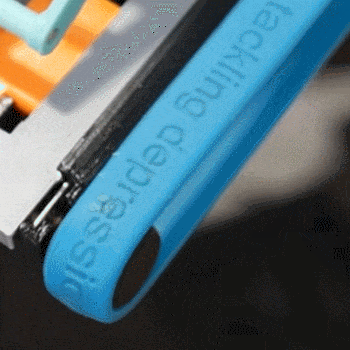
Silicone bracelet and crowned pulley result in a self-centering belt with a minimum of parts.

A crowned pulley is a way of automatically keeping a flat belt centered by having a slight hump in the center of the pulley, which tapers off on either side. Back when steam engines ran everything, spinning axles along the ceiling transferred their power to machinery on the shop floor via flat belts on pulleys. Crowned pulleys kept those flat belts centered without any need for rims or similar additions.

The reason this worked so well for [Angus]’s robot is partly its simplicity, and partly the fact that it works fantastically with the silicone wrist bracelets he uses as treads. These bracelets are like thick rubber bands, and make excellent wheel substitutes. They have great grip, are cheap and plentiful, and work beautifully with crowned pulleys as the hubs. It’s a great solution for a tiny robot, and you can how it self-centers in the image here.

Antweight robots are limited to 150 grams which means every bit counts, and that constraint leads to some pretty inventive design choices. For example, [Angus]’s new robot also has a clever lifter mechanism that uses a 4-bar linkage designed to lever opponents up using only a single motor for power. Watch [Angus] explain and demonstrate everything in his usual concise and clear manner in the video, embedded below.

Continue reading “A Crowned Pulley Keeps Robot’s Treads On Track” →

Small Combat Robots Pack A Punch In Antweight Division

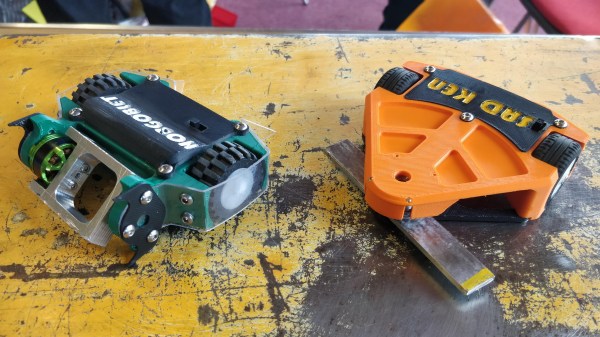
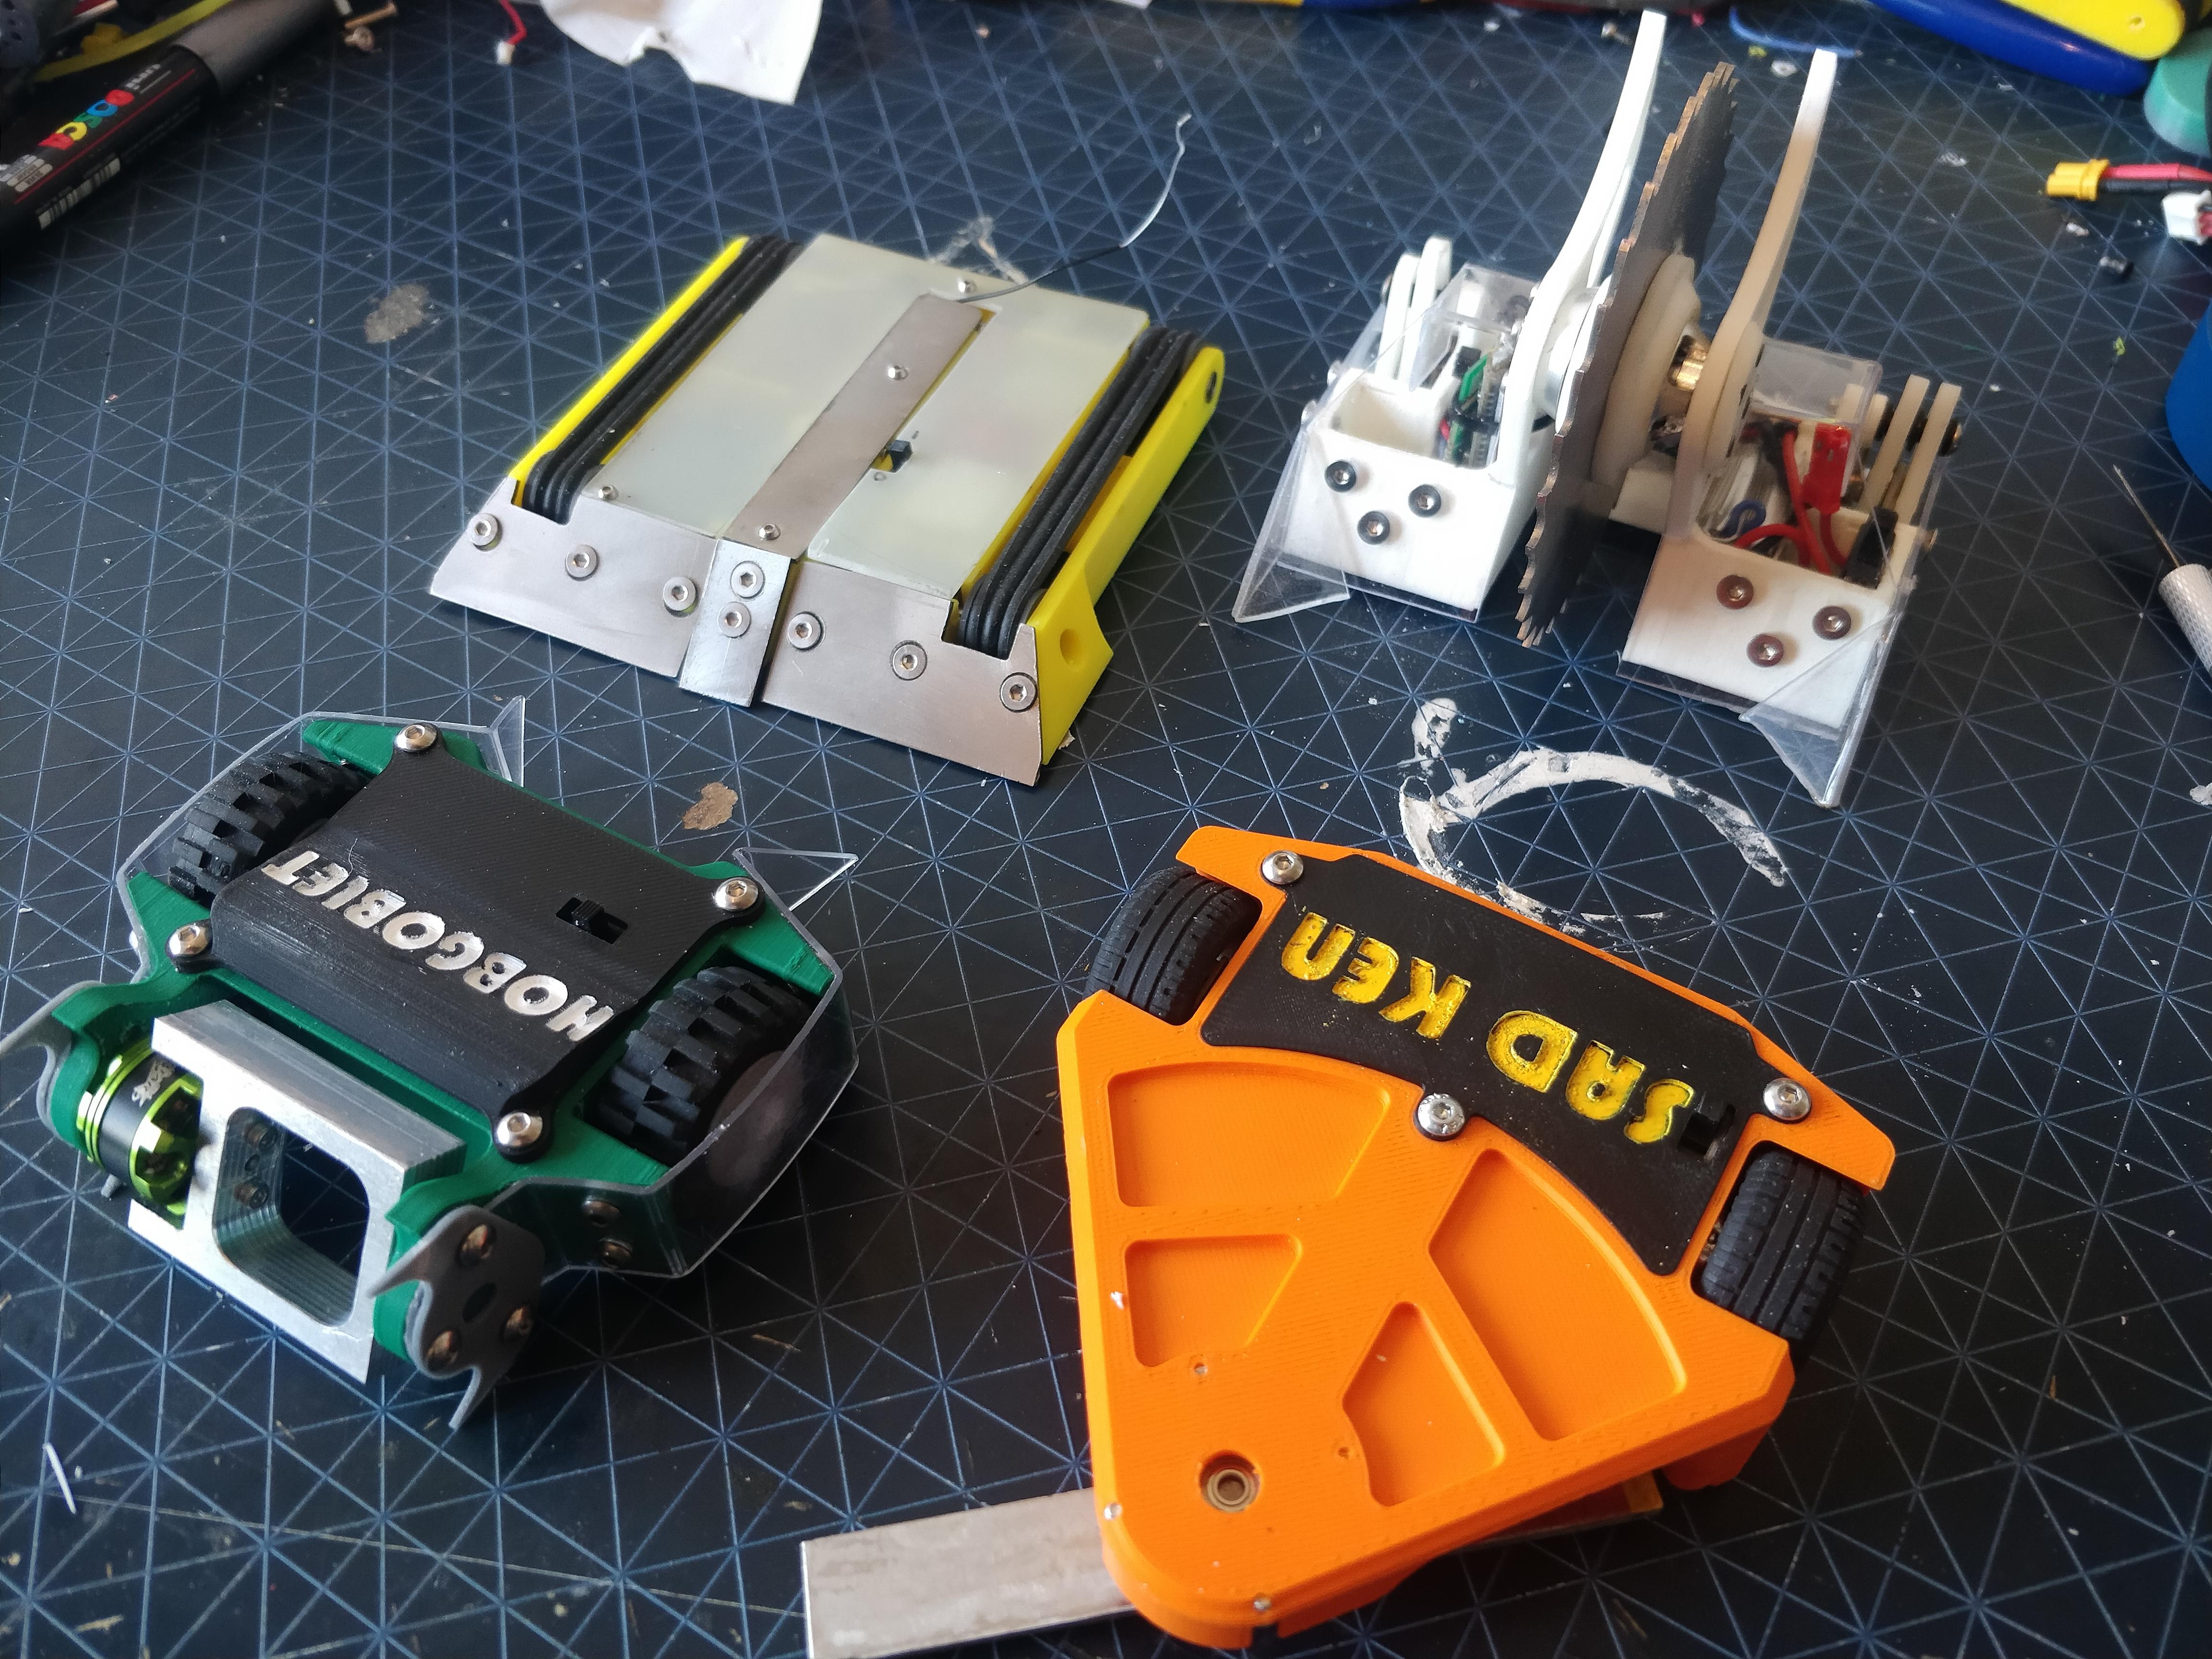
Two robots enter, one robot leaves! Combat robotics are a fantastic showcase of design and skill, but the mechanical contenders don’t have to be big, heavy, and expensive. There is an Antweight division for combat robots in which most contenders weigh a mere 150 grams, and [Harry Makes Things] shows off four participants for Antweight World Series (AWS) 64.

Clockwise: ReLoader, Shakma, Sad Ken, and HobGoblet antweight combat robots.

Each of them have very different designs, and there are plenty of photos as well as insightful details about what was done and how well it worked. That’s exactly the kind of detail we love to read about, so huge thanks to [Harry] for sharing!

In combat robotics, contenders generally maneuver their remote-controlled machines to pin or immobilize their opponent. This can happen as a result of damaging them to the point that they stop functioning, but it can also happen by rending them helpless by working some kind of mechanical advantage. Continue reading “Small Combat Robots Pack A Punch In Antweight Division” →