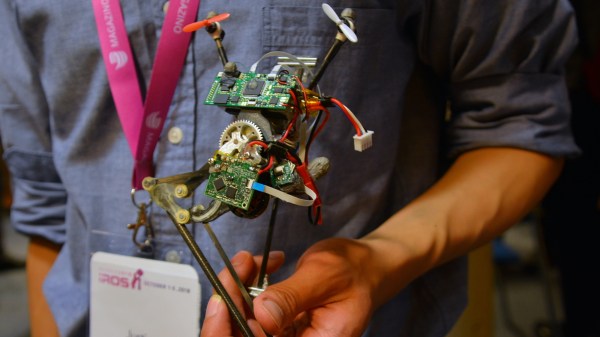
Robots that can jump have been seen before, but a robot that jumps all the time is a little different. Salto-1P is a one-legged jumping robot at UC Berkeley, and back in 2017 it demonstrated the ability to hop continuously with enough control to keep itself balanced. Since then it has been taught some new tricks; having moved beyond basic stability it can now jump around and upon things with an impressive degree of control.
Key to doing this is the ability to plant its single foot exactly where it wants, which allows for more complex behaviors such as hopping onto and across different objects. [Justin Yim] shows this off in the video embedded below, which demonstrates the Salto-1P bouncing around in a remarkably controlled fashion, even on non-ideal things like canted surfaces. Two small propellers allow the robot to twist in midair, but all the motive force comes from the single leg.
Continue reading “One-Legged Jumping Robot Shows That Control Is Everything”