Hacking A Video Walkie Talkie’s TXW818 MCU And Running DOOM

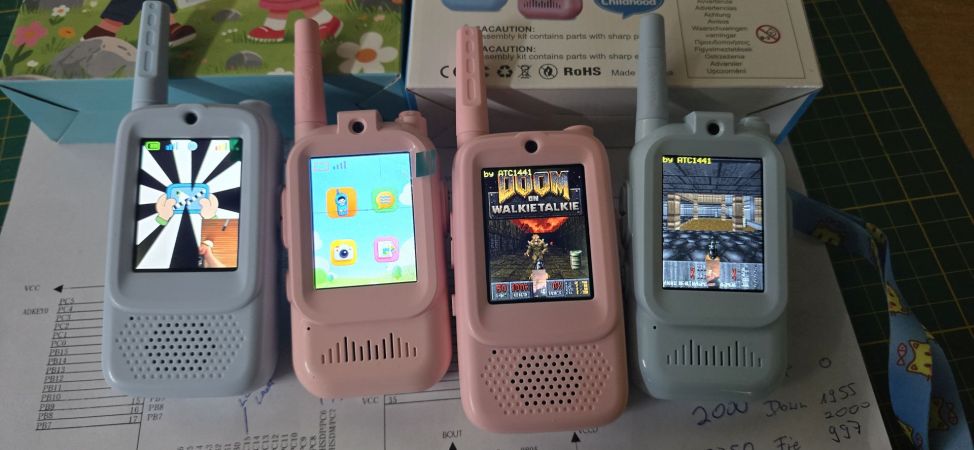
Recently cheapo video walkie-talkies popped up on everyone’s favorite online retailers, which naturally lured in the usual gaggle of reverse-engineering enthusiasts of cheap tat to see what’s inside these devices, as well as what more they can be made to do. Cue [Aaron Christophel] doing just that, with the typical DOOM demo as proof of concept.

Inside these cheerful little devices is a TXW818 MCU, made by TaiXin Semiconductor. It provides its own CK803 CPU core at 240 MHz with 272 kB of SRAM, as well as BLE and 2.4 GHz Wi-Fi support. For these walkie-talkies an additional 4 MB of PSRAM is provided as well as 2-4 MB of SPI Flash.

The display is a glorious 240×320 LCD, which actually fits rather well with a game like DOOM. As also explained on the GitHub project page, to build the project you simply have to fetch the CDK IDE and build the binary. After that it can be flashed with an STM32F103 ‘Blue Pill’ based board.

According to [Aaron] the SDK is rather convoluted and not that nice to work with, so it’s not a sleeper ESP32 alternative, but these cheap walkie-talkies could be nice to tinker with anyway. Other than playing games, of course, as the side buttons aren’t very conducive to gaming, and the limited Flash space required compressing the WAD game file.

Continue reading “Hacking A Video Walkie Talkie’s TXW818 MCU And Running DOOM“ →
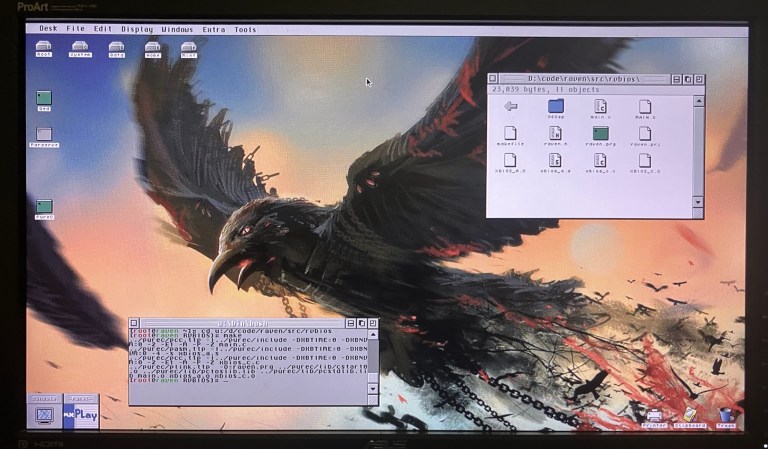
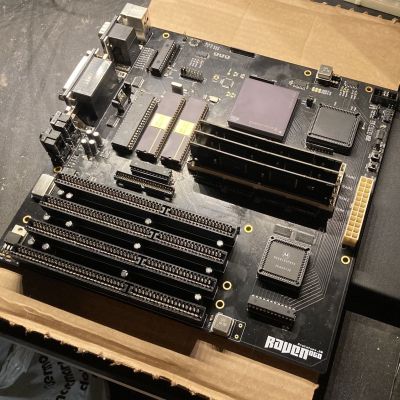
Meet The Raven: An Atari Clone Computer Based On The Motorola 68060

Some people who have a hankering to run GEM/TOS applications might just fire up an emulator, or maybe coax an old Motorola 68k-based Atari ST system back to life. Then there are people like [Anders Granlund], for whom hard mode is a way of life and making a custom mainboard around a genuine 68060 CPU and associated peripherals is a reasonable approach to pick. Thus quoth the Raven project.
The project commenced in 2024, when [Anders] started a thread on it over at the Exxos Forum which thus became pretty much the project log for the endeavor.

Both RAM and ROM ICs are on SIMM sticks, which seems like a pretty nifty idea compared to the typical socketed or soldered-in approach here, allowing for up to 48 MB of RAM and 16 MB of ROM.

On the custom ATX-compatible mainboard you get a total of 4 ISA slots, as well as everything from YM2149 audio, IDE HDD and legacy Atari peripheral support. All of which fits in a standard ATX case with an ATX power supply. If this tickles your fancy, you can find the design files for the current A1 board revision, though you will have to source your own ICs.

With all of it assembled you can run Atari’s TOS with its GEM UI, or the modern equivalent in the form of FreeMiNT.

Designing A Printable Cyclone Dust Separator For 99.95% Efficiency

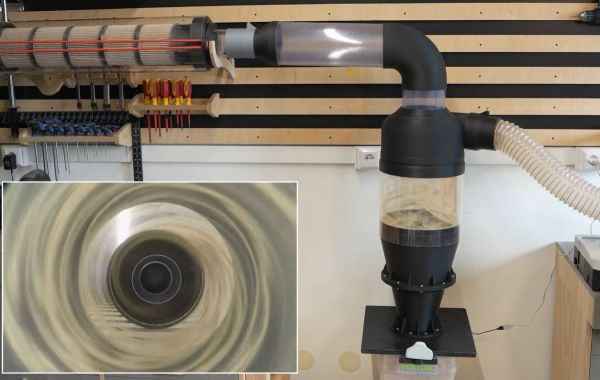
Filtering sawdust out of an airflow is easy until you try to do it with cyclone separation, but the obvious appeal here is of course not spending a fortune on filters. Over the years we have thus seen a lot of DIY takes on this concept alongside commercial offerings. Recently [Ruud] of the [Capturing Dust] YouTube channel gave it a fresh shake with a claimed 99.95% filtering efficiency that outperforms a commercial solution.

As a starting point the commercial and very succinctly named Oneida Air Super Dust Deputy Cyclone Separator was used, which retails for about $179 and claims a 99.9% filtrating rate of fine dust and debris. Based on its design a 3D model was created and printed with an FDM printer.

Initially only about a 98% rate was measured, but after some investigation this appeared to be due to the incoming and exciting airflows interfering. One tweak later to add some separation between the flows and a lot of testing of different configurations a final design was settled on that would seem to be rather quite efficient compared to the commercial option.

Continue reading “Designing A Printable Cyclone Dust Separator For 99.95% Efficiency” →

Putting Version 7.1 Of The Direct Granules FDM Extruder Through Its Paces

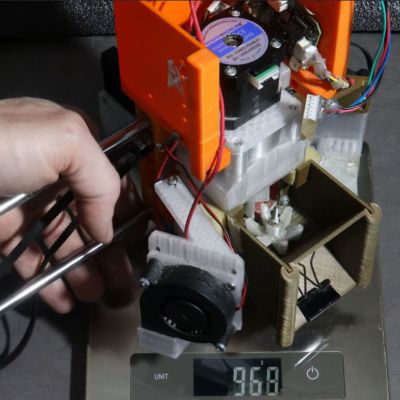
Whether you’re using granules or filament, FDM printing relies heavily on a consistent flowrate of the extruder. This is also the challenge with [HomoFaciens]’s direct granule extruder. Version 7.1 here refines some parameters before being put through a number of printing tests to see how close it comes to something you’d want to use for production.

There’s also an accompanying blog post, on which the project files can be found for those who are playing along at home.

A big part of this V7.1 change was to simplify the design for manufacturing, removing the brass insert of V7.0, instead requiring some manual labor using a drill bit and a hand reamer to get the inside of the extruder tube just right.

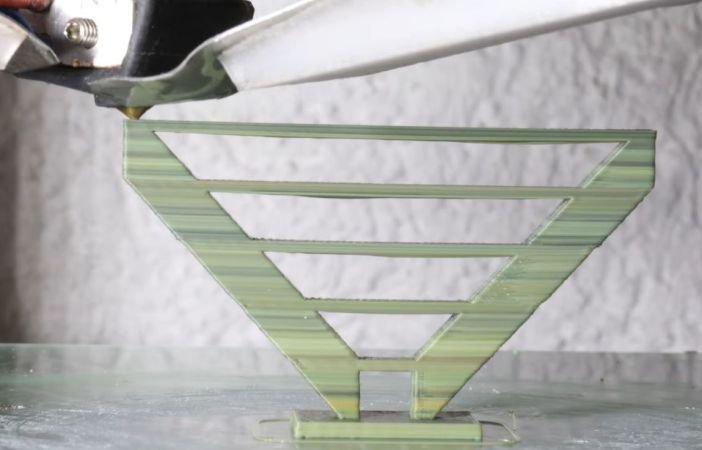
The section with the heating element was also extended, though this didn’t have as much of an effect as expected. During testing the overall results were actually pretty good, with the extruder able to keep up with bridging tests while the feared air bubbles from air intruding into the tube remained absent.

On the Prusa Mk4 FDM printer, there are some definite limitations on testing features like input shaping resulting in wavy patterns in some rest prints, but for upcoming tests a different FDM printer will be used which should more clearly show the potential of this extruder design.

Continue reading “Putting Version 7.1 Of The Direct Granules FDM Extruder Through Its Paces” →

Unitree GO-M8018-6 Motor Reverse Engineering

People seem to be rather into the Unitree Go2 quadruped robot, if only for the low price tag. But perhaps more interesting are the motors that propel it — they appear to be similar to the Go1’s GO-M8010-6 motors that Unitree also sells, with [Thomas Flayols] currently working on reverse-engineering its proprietary driver using the publicly available documentation for that motor and some reverse-engineering.

These motors are an assembly that includes a reducer, magnetic encoder, 3-phase inverter, current sensing, an RS-485 bus and a Cortex-M0-based CMS32M57xx MCU, all in a very capable package intended for robotics applications where a compact actuator is needed.

The first step of reverse-engineering involved the physical PCB, made all the more difficult as Unitree was so kind as to remove all markings on the ICs. Fortunately using an X-ray machine and some sleuthing it was possible to deduce the MCU and other components. Following this SWD/OpenOCD access to the MCU could be established and the firmware key extracted from the bootloader SRAM.

Although the firmware was encrypted, a locally recovered key was found to decrypt it. This allowed for an initial custom firmware to be developed, which [Thomas] hopes to develop into a fully featured open source firmware. Doing so would obviously open these motors to a larger audience outside of Unitree’s ecosystem, as they are pretty good value for what they offer mechanically.

It might give the associated Go2 robot a new life too considering the serious malware accusations and security issues pertaining to its firmware.

Improving An Aquarium Chiller With An Industrial Controller Transplant

A healthy aquarium ecosystem requires very specific conditions, with factors like the salinity and temperature having to be just right to keep said ecosystem happy. As some species are adapted to fairly cold water, this requires the use a water chiller. Recently [The Blunt Oracle] modified one of these aquarium-focused chillers with a much better controller to make it both more accurate and potentially more efficient as well.
The target for the surgery was a generic Shanhuchong Y-160 chiller that after a brief teardown turned out to use an STC-1000 style controller. The biggest disadvantage with this unit is probably that it just has one temperature probe, which monitored the temperature of the heat exchanger rather than that of the chilled water tank.

This controller was replaced with a Wi-Fi-equipped Elitech ECS-974T sourced for $50 off AliExpress that uses the same 71 x 29 mm form factor. Following that it was just a matter of some creative rewiring – as shown in the top image – and installing the twin temperature probes of the new controller.

Being able to monitor also the temperature of the chilled water adds a layer of redundancy that’s very welcome after splurging thousands of clams on a fancy aquarium and its inhabitants. As a bonus the Wi-Fi interface allows for it to be monitored and controlled remotely, with [The Blunt Oracle] pushing the Home Assistant configuration in a PR as well that recently got merged. They’d also like to extend their thanks to Elitech for having pretty good documentation that really helped with creating the HA configuration file, which is a rarity with many of such controllers.

How The Banana Pi BPI-R4 Pro Violates The First Rule Of OpenWRT Club

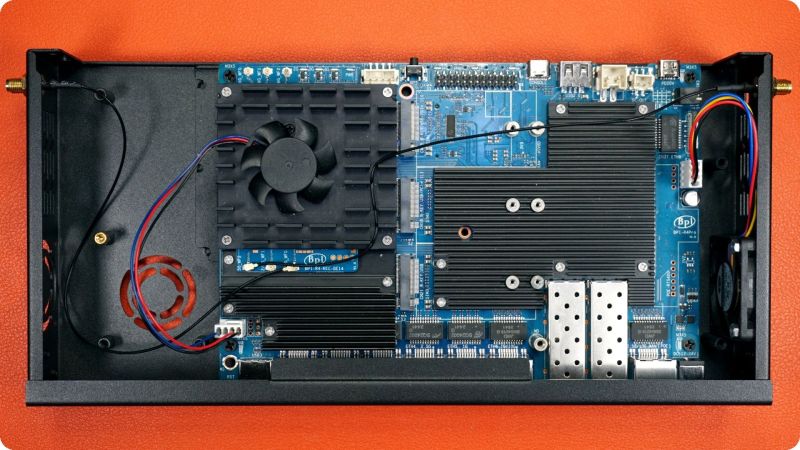
As fun as ARM and RISC-V single-board computers (SBCs) are, all too often getting the most out of the hardware requires the use of an unofficial firmware image. So too with the Banana Pi BPI-R4 Pro router SBC that has been out for a while, as OpenWRT support for it still very much unofficial. This is where [Interfacing Linux] goes on a bit of a rant while assembling one of these puppies into a sleek metal enclosure.

The first rule of OpenWRT Club is of course that you never run an unofficial image on any hardware that’s part of any network you care about. This is somewhat upsetting, as the testing shown in the video below reveals that performance is great when running it.

Currently OpenWRT support is painfully working its way through development, per the OpenWRT PR thread, so there’s hope that official support will appear at some point. As with all of such SBCs the question is always whether official support appears before the hardware has been rendered firmly obsolete. Until then the community Debian 13 image might actually be safer.

Continue reading “How The Banana Pi BPI-R4 Pro Violates The First Rule Of OpenWRT Club” →