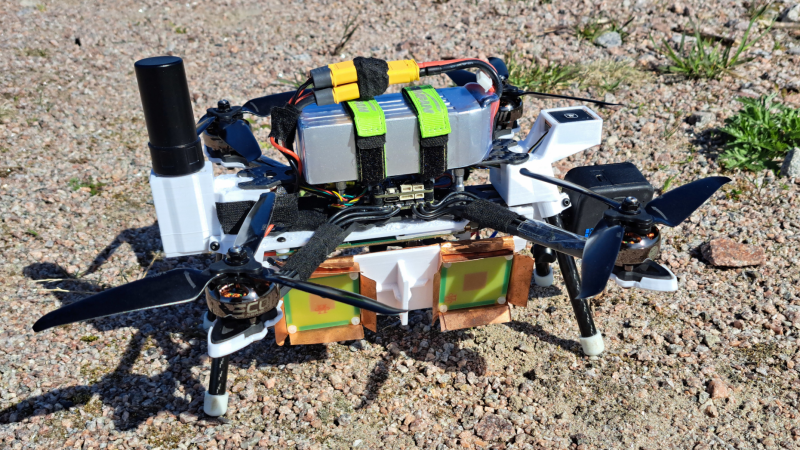
A drone is shown, carrying underneath it a white plastic box. On the side of the box are two patch antennas. A camera extends from one end of the box, and a large GPS antenna from the other end.

Synthetic Aperture Radar Drone Gets Interferometric Imaging

It’s been more than a year since [Henrik Forstén] built the first iteration of his synthetic-aperture radar (SAR) imaging drone, and he’s certainly been productive in the meantime. Not only did he develop a much more powerful autofocus algorithm to clean up the radar images, but he also extended the software to create high-resolution interferometric images.

The main limitation of the original radar system was the GPS, which only had a resolution of about one meter; the autofocus algorithm owed much of its improved clarity to an improved estimation of the drone’s position. A simpler, though more expensive, solution was to add an RTK-capable GPS receiver. RTK (Real-Time Kinematic) receivers use a fixed ground station to constantly transmit a correction signal, letting them reach a couple centimeters of accuracy. Since the drone doesn’t actually need to know its position in real time, it can also use PPK (Post-Processing Kinematic) positioning, which compares recorded GPS signals after the flight to obtain similarly accurate positions.

[Henrik] also implemented a few other hardware improvements, including stabilizing the phase-locked loop used to generate the radar’s frequency sweep. The controller FPGA’s SD card interface had too low a bandwidth to record data in real time, so [Henrik] also implemented a simple, fast compression algorithm to speed that up. Most significantly, he also developed a program for interferometric imaging. The drone flies the same path twice at different altitudes; by comparing phase information from different passes, it’s possible to detect a target’s elevation. Normally, the radar program assumes constant elevation, making tall objects seem to lean toward the radar source; an interferogram, on the other hand, allowed [Henrik] to generate a detailed elevation map.

[Henrik] is no stranger to synthetic aperture radar; we’ve previously covered a bike-mounted iteration and a budget SAR system. If the concepts behind this are still a bit fuzzy, we’ve also covered a guide to making your own SAR setup.
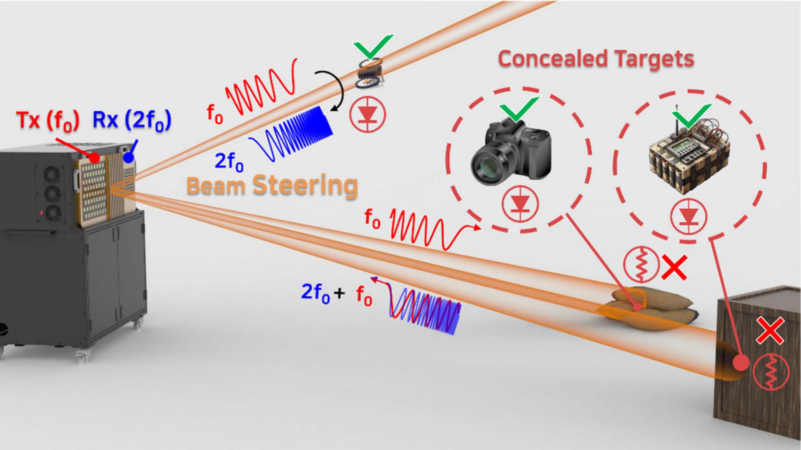
A diagram of a radar system is shown. A pair of antennas is shown on the left, with beams illuminating a number of electronic devices, labelled as "Concealed Targets."

Harmonic Radar Finds Hidden Electronics

For as long as small, hidden radio transmitters have existed, people have wanted a technology to detect them. One of the more effective ways to find hidden electronics is the nonlinear junction detector, which illuminates the area under investigation with high-frequency radio waves. Any P-N semiconductor junctions in the area will emit radio waves at harmonic frequencies of the original wave, due to their non-linear electronic response. If, however, you suspect that the electronics might be connected to a dangerous device, you’ll want a way to detect them from a distance. One solution is harmonic radar (also known as nonlinear radar), such as this phased-array system, which detects and localizes the harmonic response to a radio wave.

One basic problem is that semiconductor devices are very rarely connected to antennas optimized for the transmission of whatever harmonic you’re looking for, so the amount of electromagnetic radiation they emit is extremely low. To generate a detectable signal, a high-power transmitter and a very high-gain receiver are necessary. Since semiconductor junctions emit stronger lower harmonics, this system transmits in the 3-3.2 GHz range and only receives the 6-6.4 GHz second harmonic; to avoid false positives, the transmitter provides 28.8 decibels of self-generated harmonic suppression. To localize a stronger illumination signal to a particular point, both the transmit and receive channels use beam-steering antenna arrays.

In testing, the system was able to easily detect several cameras, an infrared sensor, a drone, a walkie-talkie, and a touch sensor, all while they were completely unpowered, at a range up to about ten meters. Concealing the devices in a desk drawer increased the ranging error, but only by about ten percent. Even in the worst-case scenario, when the system was detecting multiple devices in the same scene, the ranging error never got worse than about 0.7 meters, and the angular error was never worse than about one degree.

For a refresher on the principles of the technology, we’ve covered nonlinear junction detectors before. While the complexity of this system seems to put it beyond the reach of amateurs, we’ve seen some equally impressive homemade radar systems before.

Recognizing Activities Using Radar

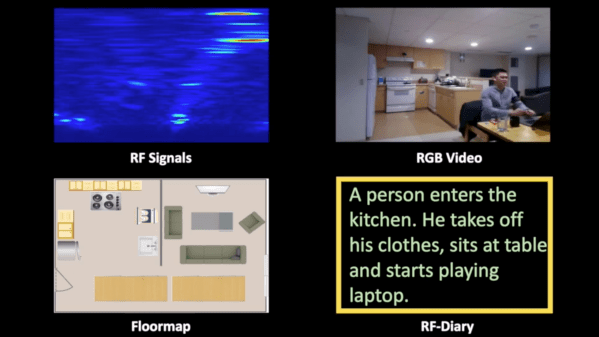
Caring for the elderly and vulnerable people while preserving their privacy and independence is a challenging proposition. Reaching a panic button or calling for help may not be possible in an emergency, but constant supervision or camera surveillance is often neither practical nor considerate. Researchers from MIT CSAIL have been working on this problem for a few years and have come up with a possible solution called RF Diary. Using RF signals, a floor plan, and machine learning it can recognize activities and emergencies, through obstacles and in the dark. If this sounds familiar, it’s because it builds on previous research by CSAIL.

The RF system used is effectively frequency-modulated continuous-wave (FMCW) radar, which sweeps across the 5.4-7.2 GHz RF spectrum. The limited resolution of the RF system does not allow for the recognition of most objects, so a floor plan gives information on the size and location of specific features like rooms, beds, tables, sinks, etc. This information helps the machine learning model recognize activities within the context of the surroundings. Effectively training an activity captioning model requires thousands of training examples, which is currently not available for RF radar. However, there are massive video data sets available, so researchers employed a “multi-modal feature alignment training strategy” which allowed them to use video data sets to refine their RF activity captioning model.

There are still some privacy concerns with this solution, but the researchers did propose some improvements. One interesting idea is for the monitored person to give an “activation” signal by performing a specified set of activities in sequence.

Continue reading “Recognizing Activities Using Radar” →