Open Source Acoustic Drone Detection

Drones have become a potent military threat, particularly on the small scale. Nimble multi-rotor drones are fast, difficult to spot, and can cause plenty of harm if allowed to go about their work unhindered. The first step to dealing with this issue is detection—a problem that [Agam Rossen] has put some work into.

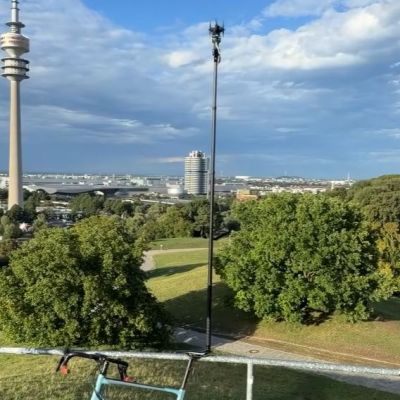
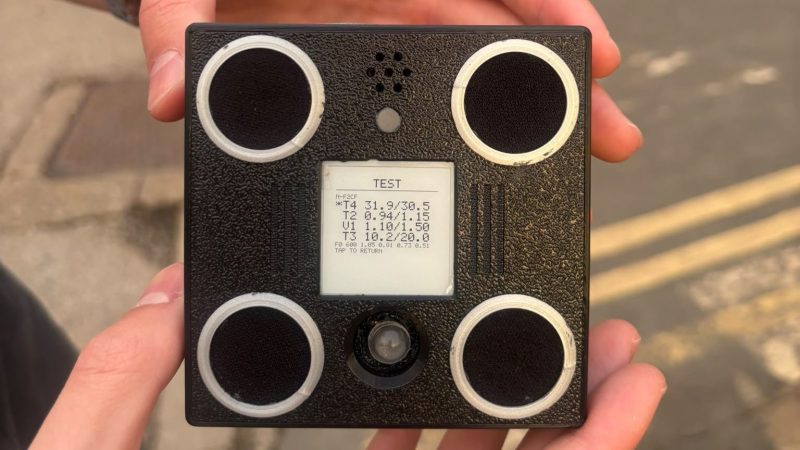
The result is VolAnti—an open-source drone detector. This route was chosen as a reliable way to detect incoming multi-rotors, since spinning propellers tend to create a telltale sound that can be plucked from the noise quite specifically. In a world where fiber optic drones eschew RF emissions, it also proves particularly useful for early warning of such craft.

VolAnti relies on a small four-microphone array, with the I2S output of all four mics summed together. The output is then fed into a 2048-point FFT running every 32 ms on an ESP32-S3. A comb score is given to try and pick out different blade rates from 70 Hz to 2000 Hz. Multiple detection algorithms run in parallel, because [Agam] noted a problem—using an adaptive noise floor would miss drones that arrived in the area and hovered in place. With the noise not varying, it would get filtered out by the adaptive floor, so one algorithm in the four runs with no floor to catch drones that aren’t moving. Files are on GitHub for those curious to learn more.

We’ve featured other acoustic detection projects before, too. If you’re working on something similar, or conversely, you have the inside scoop on how to hide a drone’s noise signature, don’t hesitate to let us know on the tipsline.
Continue reading “Open Source Acoustic Drone Detection”

Making A Pole Balance Itself With Propellers

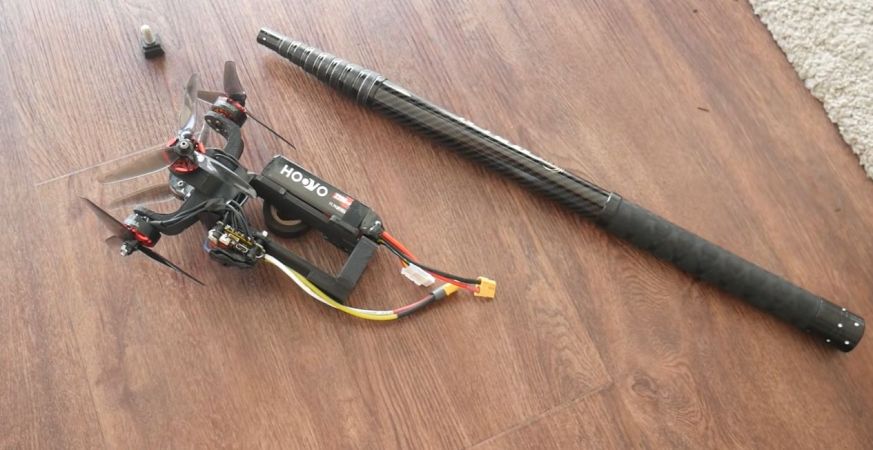
A fun trick with a pole is to try to balance it so that it can stand on one end. This can be done in a few ways, such as by exerting a force on either end to counterbalance any force that threatens to make it fall over. The approach that [Peter Ryseck] chose was to cobble together what is effectively a flying drone for on top of a standing pole, without cheating such as by simply lifting it off the ground.
Getting to the point where the drone could react quickly enough to changes in the pole’s orientation was the hardest part, as the quieter, larger propellers also have a lot more inertia. This ruled out using 10″ blades, while triple 5″ blades seemed to work well enough. For the avionics a standard quadcopter control board and software is used, with the programming such that it’ll react appropriately without causing additional instabilities.

Naturally making this work took some trial and error, with issues like oscillations plaguing the system. One unexpected problem was that the pole – taken from a pool fishing net – was flexible enough to add its own instabilities to the system. In the video all these issues and their solutions are explained in detail, along with the ultimate result. One very neat solution here for example is to have the pole lean into the wind, which is a more stable configuration than insisting on having the pole be at a perfect ninety degrees with the ground.

Continue reading “Making A Pole Balance Itself With Propellers”

Simulating UAVs In Unreal Engine

When it comes to building real-world flying vehicles, testing can be arduous and expensive. You have to find somewhere to fly, then you have to contend with environmental conditions and the possibility of damaging your craft if things go wrong. Simulation is a great solution to this, allowing testing without so much risk. To that end, [AlexanderRex] whipped up a platform for testing UAVs from the comfort of your computer desk.

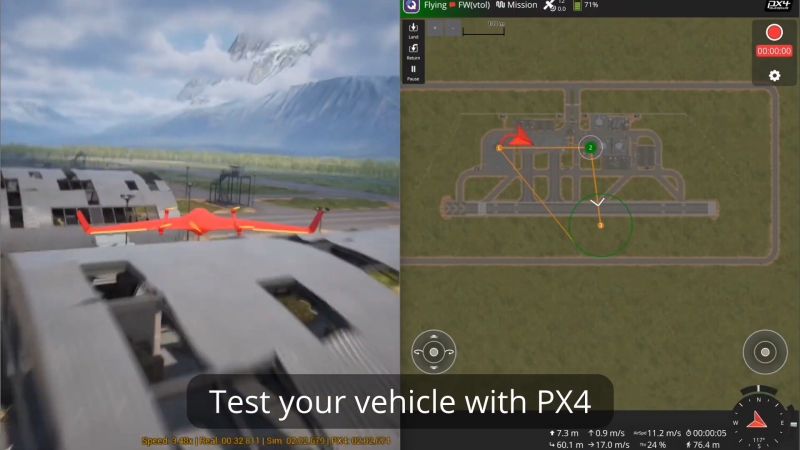
PteroSim is intended as a comprehensive test bench for simulating autonomous aerial vehicles. It can run PX4, ArduPilot, and Betaflight binaries right in the simulator. The autopilot code is given simulated sensor data, and in turn responds with actuator commands, just as it would in a real craft. The simulator runs the flight dynamics using JSBSim, and the resulting scene is rendered in Unreal Engine 5.

If you’ve ever wanted to quickly road test different autopilot settings without heading out to the field or risking hardware, this is a great way to do so. It’s hard to beat the speed of iteration that is possible when testing on the computer on your desk. We’ve featured similar work before, too.

Continue reading “Simulating UAVs In Unreal Engine”

Submersible Drone Analyzes Ice

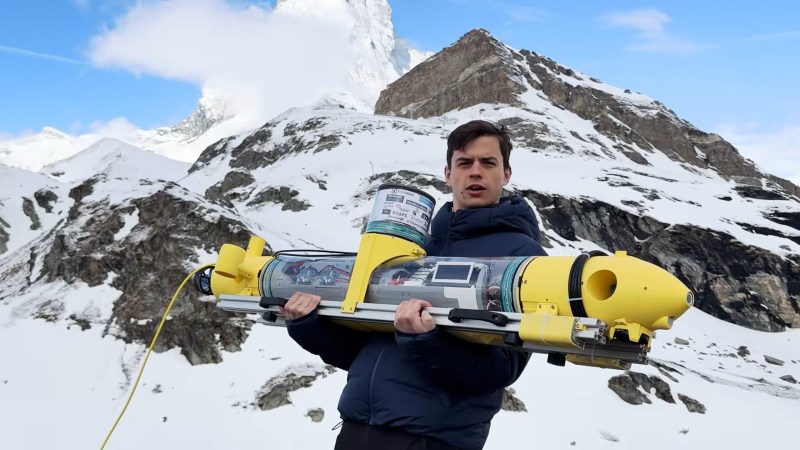
Doing anything on a frozen lake can carries some amount of risk. Nevertheless, every year events ranging from car racing to ice skating are held on them. As such, proper safety precautions are needed, the most important of which is ensuring the ice is thick enough to withstand the weight of whatever may be on it. This is done by cutting holes into the ice and measuring its depth in several locations. But this is a dangerous and imperfect process only giving a rough picture of actual thickness. So to solves these problems, a team of students at ETH Zurich made an ice measuring submersible drone. 

The concept of ice measurement employed is, on paper, reasonably simple. When a sonar pulse is sent out, some of the energy will return off the bottom of the ice sheet, but some of it will pass through creating a second return. By measuring the difference in these two returns, the thickness can be calculate with a high degree of precision. Attach the sonar to a submersible and give it a positioning system and you can simply get a thickness map, right? Well, employing theory in practice is a far more complicated prospect as the students soon found out.
Continue reading “Submersible Drone Analyzes Ice”

Hackaday Europe 2026: Half Quad, Half Blimp: Test. Fly. Survive.

A great many drones out there, whether homebuilt or store-bought, follow the same basic format. Four motors, some kind of controller, and a lithium-polymer battery supplying the juice to keep everything in the air. It’s a format that produces a remarkably capable air vehicle, suitable for everything from high-speed camera work to urban search and rescue.

With that said, the format does have its limitations. [Suryansh Sharma] has been working on alternative designs for fancy and interesting drones that are half quadcopter and half blimp, and he came to Hackaday Europe 2026 to tell us all about it.

Continue reading “Hackaday Europe 2026: Half Quad, Half Blimp: Test. Fly. Survive.”

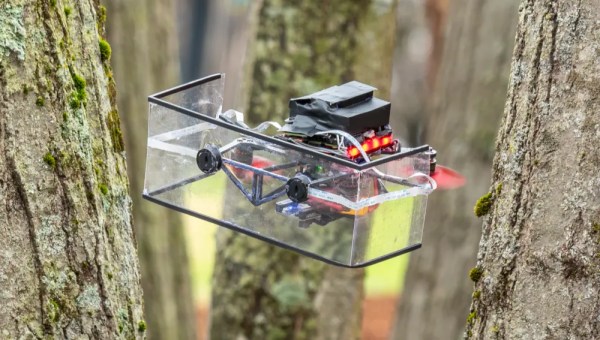
A quadcopter with a clear, U-shaped shield up front and red propellers navigates between a close stand of moss-covered trees.

Echolocation For Drones

Bats are remarkable creatures, able to fly at night or inside the confines of caves without light to guide their way. A team of researchers at Worcester Polytechnic Institute (WPI) has determined how to use low power ultrasonic sensors to guide drones in obscured environments.

While radar, lidar, and GPS are all great for navigation and sensing, they can run into issues when light is obscured or can take too much power to be practical for the limited battery life of a drone. The researchers found that a dual sonar array could be used to implement a much lower power sensing system for a drone that performs well in environments that would stymie a computer vision system.

A shield placed behind the array cuts down on the sound of the propellers that would otherwise drown out the signal, and further signal analysis via a neural net separates the echoes of objects in front of the drone from the background. The prototype could navigate in various simulated environments like forests, smoke, and snow. It looks like it even got a chance to go for a flight in the actual woods. All the code and hardware designs are Open Source, so have at it!

We’ve covered mosquito-inspired drone sensors before, and if you want to get into echolocation yourself, apparently humans can learn to do it too.

Continue reading “Echolocation For Drones”

Spidery Drone Goes Near-invisible By Spinning Really, Really Fast

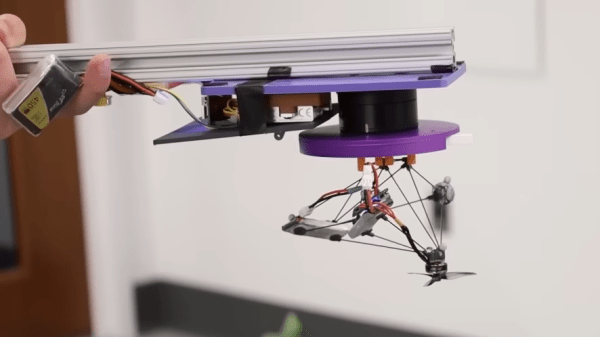
Researchers demonstrate that something interesting happens when a small drone with a spindly airframe spins at a high speed: it very nearly turns invisible. The spidery device is shown mounted in its launcher in the image above. The dark blur at the rightmost side is an outlet on the wall behind the drone, not motion blur from a moving part.

There’s not much to do about the noise, but a high-speed spin becomes nearly invisible.

It’s called the Phantom Twist, and while we’ve seen single-motor drones that spin around a central axis before, they have always incorporated a wing-like structure or cleverly leverage the magnus effect to generate lift.

There’s not a lot of detail about the Phantom Twist’s hardware design but it appears to use a downward-angled motor for lift, relying on a high-speed control system to maneuver and maintain altitude.

This does away with the need for a wing, at the cost of only being stable while rotating at a high speed. We imagine it is also a touchy design that depends greatly on being balanced just so.

A hand launcher spins the device up before releasing it for flight. The visual effect once it is up and running is pretty striking; see for yourself in the short video, embedded just below.

Continue reading “Spidery Drone Goes Near-invisible By Spinning Really, Really Fast”