Chernobyl’s Robots, Or The Hackathon From Hell

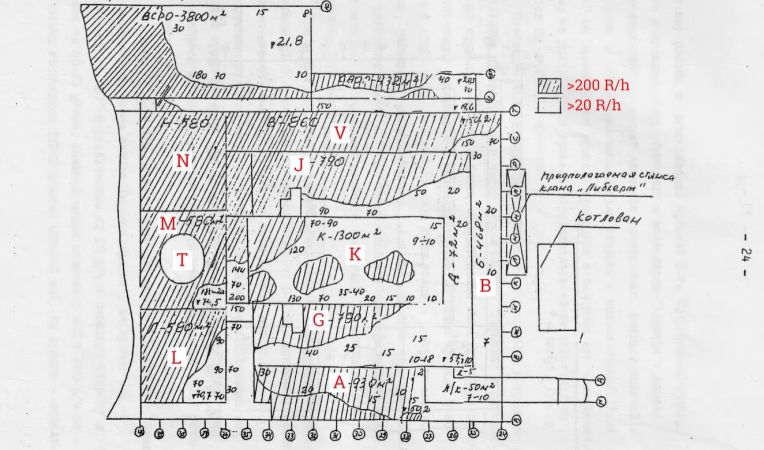
When the Chernobyl Nuclear Power Plant’s #4 reactor experienced an extreme criticality event on that infamous day in 1986, the resulting steam explosion and lack of any kind of containment building meant that parts of the core were scattered throughout the site. In an extensive update to the original 2023 video, the [Chornobyl Family] covers the mad scramble to design robots to perform on-the-ground measurements, and ultimately remove all this debris for safe disposal.
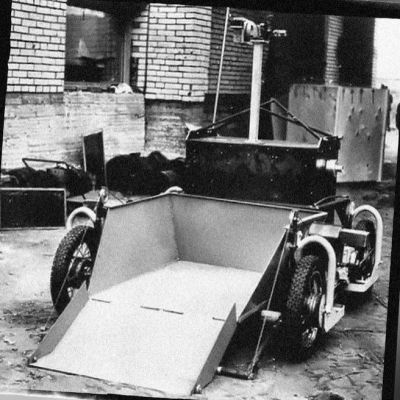
The TR-1A, an early debris removal robot. (Source: Chornobyl Family, YouTube)

This essentially took the form of a hackathon, involving teams from all over the USSR and allied nations, creating the most diverse range of robots that 1980s Soviet technology and later Western technology could muster.

Many of these robots didn’t perform very well, or at all, mostly due to the bypassing of any kind of testing before deployment. Especially at the beginning of the clean-up the robots were being pushed into the high-radiation zones as soon as they were finished, with not only mechanical issues being a problem, but also with e.g. inaccurate radiation measurements by the RR-1 robot, that overstated measurements by more than a factor of ten. Meanwhile the RR-2 and RR-3 were too top-heavy and after deployment by helicopter simply tipped over. Eventually manual measurements proved to be faster and safer.

Early debris removal robots like the TR-1A were rather simplistic, with successive generations of robots over the next weeks and months improving on it. The use of a combustion engine instead of batteries provided to be a boon, as combustion engines are far less affected by radiation.

The BAER Beloyarets used an airport cart as the basis, with its electronics relying on vacuum tube technology and relays, with an internal combustion engine. This proved to be one of the most reliable designs and it’s been largely preserved on display in the Chornobyl Exclusion Zone, with many others of these robots also being on display around the nuclear plant or in the city of Chornobyl.

Overall an absolutely dizzying number of robotic designs were invented on the spot, adapted from existing designs or repurposed for operation in a high-radiation zone. Eventually bulldozer designs like the STR-1 helped to push radioactive debris off the roofs into containers, massively reducing the radioactive contamination of the area.

The fact that following #4’s RUD the other three RBMK units were able to keep operating safely without risks to its operators, and with the zone now safe for tourists, is a real testament to the success of the worst hackathon imaginable. Many of the lessons learned are relevant today, including during the decommissioning of Fukushima Daiichi’s melted-down cores.

Continue reading “Chernobyl’s Robots, Or The Hackathon From Hell” →
A 3D Printed Cycloidal Gearbox

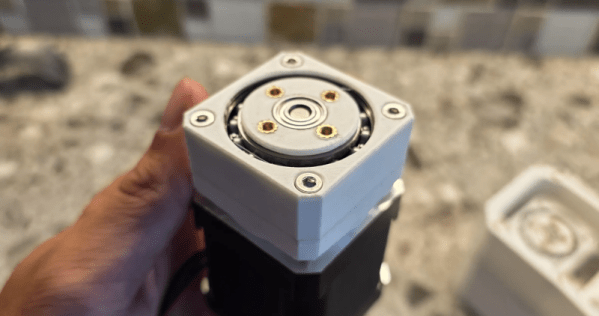
Stepper motors are undeniably useful, but sometimes they need a bit of gearing to help perform their task. [Gjhudson2008] has a compact gearbox for NEMA 17 or 23 steppers that is mostly 3D printed. How compact? The gearbox, named VANTIX, is exactly the height of a standard NEMA 17 axle.

However, for it to be that thin, your stepper has to have the D-bore on the shaft go all the way down. Some steppers leave a shank uncut at the base, and that won’t work for VANTIX.

The recommendation is to print in ABS with a 0.2 mm nozzle for certain parts to help improve tolerance. Most of the assembly is either press fit or installed during the printing process. Some parts of the gearbox are better to print with a larger nozzle, too.

There are some heat-set inserts and, of course, you’ll need lube to keep everything moving smoothly. There are a few top plates you can print to fit various mounting scenarios.

We have seen a number of similar designs. We’ve also looked at some e-bike-inspired drives.

Stewart Platform Walker Gains Feeling In Legs From Resistors

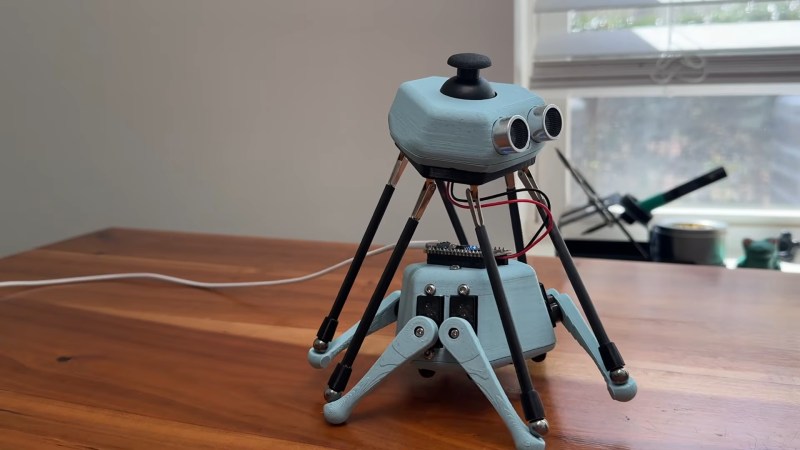
Stewy is a very interesting robot, with some slightly odd kinematics. Its head is a Stewart platform, which is a common-enough 6-DOF actuated plate normally used with a fixed base. By connecting legs to the same servos running the Stewart platform, [JD] turned it into an adorable hexapod walker. The walker had a problem, though: it can’t feel its feet, and [JD] thinks that would make it much more mobile on uneven surfaces. So he got some resistors to turn the cheap servos in its legs into force-sensing actuators.

Well, almost. He’s not actually putting strain gauges or anything like that into the legs; he’s just measuring the voltage drop across a resistor in series with the servos. Since the motors draw more current the more torque they’re putting out, he has a very quick and easy way to sense the current and thus the torque using good old Ohm’s law and an analog input on the microcontroller driving the robot. It’s a simple hack, but the data he’s getting is surprisingly good for how much work it is to add to a robot, as you can see in the video — at least once he slowed down the servos a touch.

Perhaps this isn’t a ground-breaking innovation, but [JD] does a very good idea explaining it. Of course if you want to use resistors to sense force directly, force-sensitive resistors are a thing that we’ve seen in everything from Twister-mat MIDI controllers to self-leveling 3D printers.

Continue reading “Stewart Platform Walker Gains Feeling In Legs From Resistors” →

Tiny Desktop Robot Has Radar

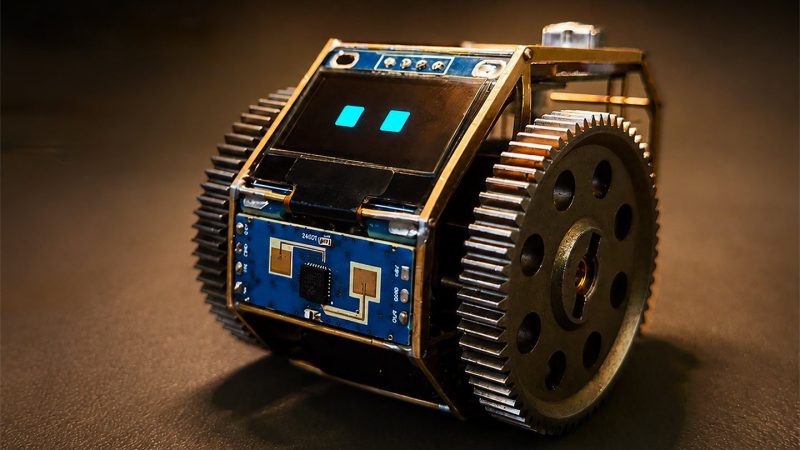
One thing our futuristic world is largely lacking in is droids and robot companions and the like. [solitary dev] is helping to rectify that problem by building a little robot called TongDou.

As [solitary dev] tells it, TongDou is a “tiny open-source desktop gremlin.” An ESP32-S3 serves as TongDou’s brain, buried inside a tasteful brass chassis. An OLED display is TongDou’s face, and he uses a pair of wheels driven by gearmotors for locomotion. A speaker plays back pre-recorded voice lines, while a 24 GHz radar and an IMU enables TongDou to keep track of the space it’s moving through. They are publishing the design files on GitHub so other makers can build their own if so desired.

[solitary dev] hopes to develop TongDou into something to make a “workspace feel less dead.” It’s not dissimilar from the way studios used to use robots to liven up otherwise hackneyed movies and TV shows, and we could absolutely use some of that whimsy in the real world. We’ve featured other fun desktop companions before, too.

Continue reading “Tiny Desktop Robot Has Radar” →

Custom Beach Robot Handles The Hard Work

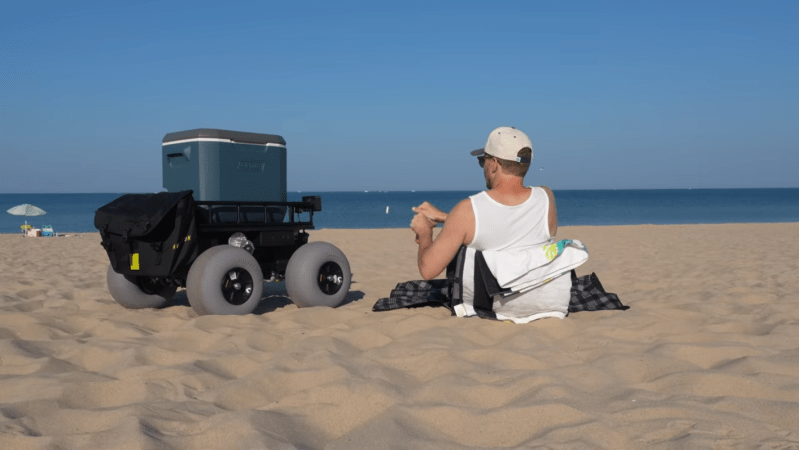
A day at the beach can involve hauling a surprising amount of gear, from coolers, towels, blankets, chairs, and umbrellas, and if children are involved the amount of beach stuff needed seems to go nonlinear very quickly. Some turn to beach carts with large, low-pressure pneumatic tires, but even that seemed like too much work for [John] who built this remote controlled cart for his summertime needs.

The cart is based around an old cargo rack from an e-bike. To mount all of the robotic components, a sheet of plywood was cut and attached to the underside. Two motors are used to drive the rear wheels independently, allowing for differential steering rather than adding the complexity of a steering system. Some safety features are built in to this design as well, including lights for night driving, a start button controlling a relay for the motors and electronics, and a time-of-flight sensor to stop the robot if it encounters an obstacle.

The ESP32 at the center of the build ties all of the electronics together, and a smartphone app lets the user remotely pilot the rover. It’s not autonomous (yet) but a fair alternative to dragging all of one’s beach gear through the sand without any assistance. You could also minimize your excursions through the sand by timing your visits at high tide, but [John] is out on the Great Lakes so this may be of marginal utility here.

Continue reading “Custom Beach Robot Handles The Hard Work” →

Open Source Vacuum Avoids Cloud

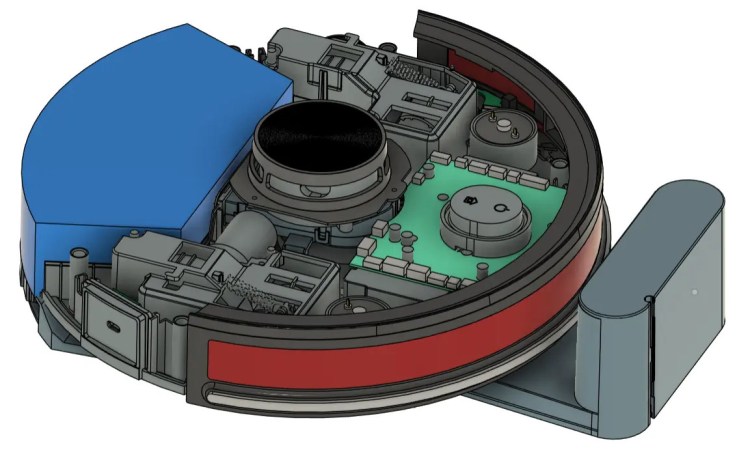
As more and more of the technology that we paid for turns becomes a subscription, there’s slowly been a momentum shift in the open source world of building replacements for these intrusive rent-seekers. We see this all of the time for self-hosted media and communications servers, but now we’re starting to see it in hardware as well. The OOMWOO robotic vacuum cleaner is completely open source, from hardware to software, and requires no cloud services whatsoever.

Although it’s open source, not every component is something one could buy off the shelf. It does require a 3D printer for most of the parts, but assuming that requirement is met most of the rest of the build comes together easily enough. For compute it relies on a Raspberry Pi running ROS 2 software and is set up to integrate easily with other existing open tools and projects such as Home Assistant. Like its proprietary cousins it can sense and map the rooms its placed in, but this platform uses an inexpensive 2D lidar system to keep costs down.

Right now the project is not quite complete, so we’ll all have to keep our eyes on this one as the team building it progresses. But they do have most of the software development done and the bill-of-materials is in progress. As an open project it’s being developed by many volunteers and there are a lot of areas available to contribute to as well, all currently set up on the project’s GitHub page. Right now many of those areas of effort are adapting the 3D printer files to off-the-shelf parts.

With the rocky status of the Roomba ecosystem, projects like this are more important than ever.

Fibrous Muscles For Humanoid Robotics

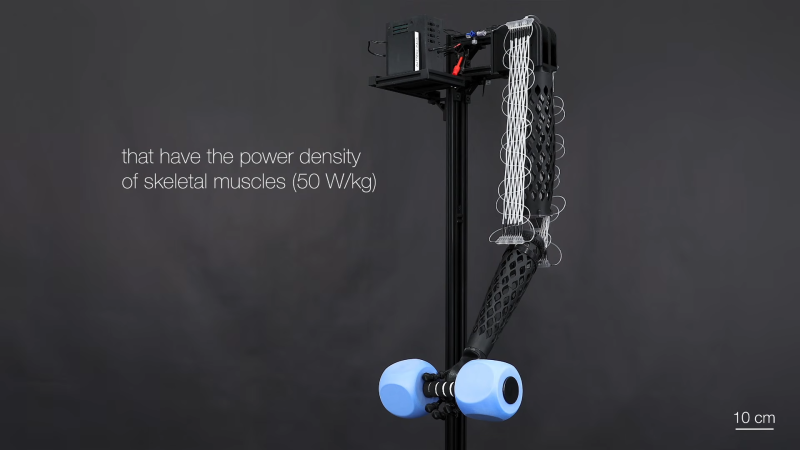
At the current rate of robotics development, you might assume that we’re close to Skynet taking over. However, while we  likely wouldn’t do well in a physical fight against a robot, we can at least keep the bragging rights of having the cooler actuators. Or at least, that was the case before a new actuator came into town — introducing “Electrofluidic Fiber Muscles”.

Traditional robotic actuators use motors of some kind with a variety of gearboxes or linkages to turn rotational movement into usable movement. This isn’t always the most effective way to run some robotics movements, especially when modeling humans. This is why many have turned to pressurized modes of actuation. Though most don’t show quite the promise of the new player.

Electrofluidic Fiber Muscles use pressure to shorten muscle strands, similar to past actuators. However, these are a tad different, taking advantage of electrofluidic pressure. A small current under high voltage is able to drive a pressure gradient in a long tube. This tube can then be connected to both an extensor and flexor portion of an actuating circuit, similar to a biological mechanical system. Better yet, this driving pressure pump can be spun around the fibers themselves, making a tight package.

Unfortunately, it will probably be a bit till we see this inside a hobbyist robot. Until then, make sure to check out some other actuator feats!

Continue reading “Fibrous Muscles For Humanoid Robotics” →