Feeding The Fire By Robot

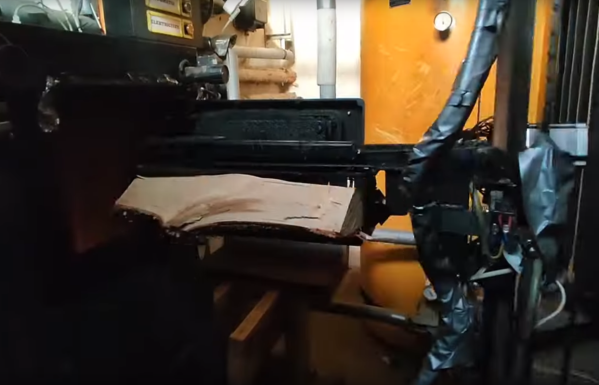
It might seem a little bit counterintuitive, but one of the more carbon-neutral ways of heating one’s home is by burning wood. Since the carbon for the trees came out of the air a geologically insignificant amount of time ago, it’s in effect solar energy with extra steps. And with modern stoves and well-seasoned wood, air pollution is minimized as well. The only downside is needing to feed the fire frequently, which [Anders] solved by building a robot.

[Anders]’ system is centered around a boiler, a system which typically sits in a utility area like a basement and directs its heat to the home via another system, usually hot water. An Arduino Mega controls the system of old boat winches and various motors, with a grabber arm mounted at the end. The arm pinches each log from end to end, allowing it to grab the uneven logs one at a time. The robot also opens the boiler door and closes it again when the log is added, and then the system waits for the correct set of temperature conditions before grabbing another log and adding it. And everything can be monitored remotely with the help of an ESP32.

The robot is reportedly low-maintenance as well, thanks to its low speed and relatively low need for precision. The low speed also makes it fairly safe to work around, which was an important consideration because wood still needs to be added to a series of channels every so often to feed the robot, but this is much less often than one would have to feed logs into a boiler if doing this chore manually. It also improves on other automated wood-burning systems like pellet stoves, since you can skip the pellet-producing middleman step. It also eliminates the need to heat your home by burning fossil fuels, much like this semi-automated wood stove.
Continue reading “Feeding The Fire By Robot” →

Vroomba Gets Upgrades And A Spoiler

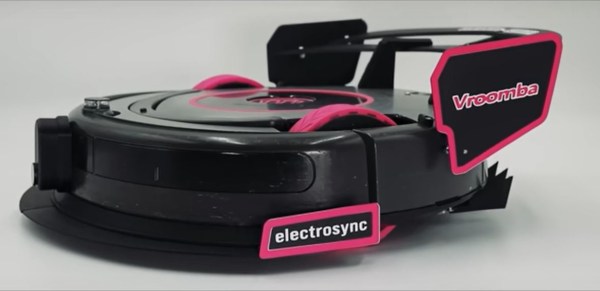
[Electrosync] is the creator and driver of the world’s fastest robotic vaccum cleaner, the Vroomba. It’s a heavily modified roomba capable of speeds of around 60 kph, well beyond the pedaling speed of most bicyclists. Despite being rejected by Guinness for a world record, we’re fairly confident that no other vacuum cleaners have gotten up to these speeds since the Vroomba first hit the streets. That’s not going to stop [electrosync] from trying to top his own record, though, and he’s brought the Vroomba some much needed upgrades.

The first, and perhaps most important, upgrades are to some of the structural components and wheels. The robot is much heavier than comparable RC vehicles and is under much greater strain than typical parts are meant to endure, so he’s 3D printed some parts of the chassis and some new wheels using a nylon-carbon fiber filament for improved strength. The wheels get a custom polyurethane coating similar to last time.

Continue reading “Vroomba Gets Upgrades And A Spoiler” →

Voice Controlled Rover Follows Verbal Instructions To Get Around

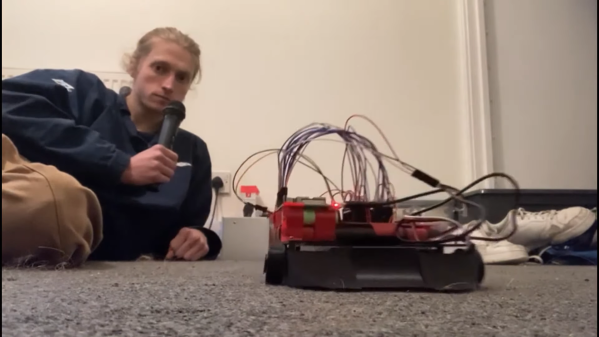
Typically, when we want to tell a robot where to go, we either pre-program a route or drive it around with some kind of gamepad or joystick controller. [Robotcus] decided to build a simple robot platform that drove around in response to voice commands instead.

The robot is based around a Raspberry Pi Zero, charged with instructing the motor controllers to drive the ‘bot around. The Pi Zero is also in charge of interpreting the voice commands via Google’s speech recognition tool. The ‘bot itself is a fairly simple design using brushed gearmotors for propulsion and a 3D-printed chassis to tie everything together.

The car is capable of understanding five commands – drive, turn left, turn right, go backwards, and “attack”. The last command simply activates a flipper from the robot’s former life as a battlebot. Things ran okay at first, but the Pi Zero was slow at processing commands. The wheels also had minimal traction. A full-fat Raspberry Pi solved the latter issue, while a new chassis provided better grip.

It’s a simple project, but one that taught [Robotcus] plenty about programming and building small robots in the process. Like so many learning experiences, it’s easy to see how the robot starts out flailing uselessly and eventually starts to perform as intended. It’s always nice to see that progression. Video after the break.

Continue reading “Voice Controlled Rover Follows Verbal Instructions To Get Around” →

Infrared Following Robot Built As Proof-of-Concept For Autonomous Luggage

Once upon a time, the poor humans of the past had to lug around suitcases and trunks with their own arms. Then, some genius figured out that you could just put wheels on and make everyone’s life a million times easier. Now, what if you didn’t even have push, because your luggage could just follow you instead? Well, students [Yuqiang Ge] and [Yiyang Zhao] have figured out a proof of concept for how that could work.

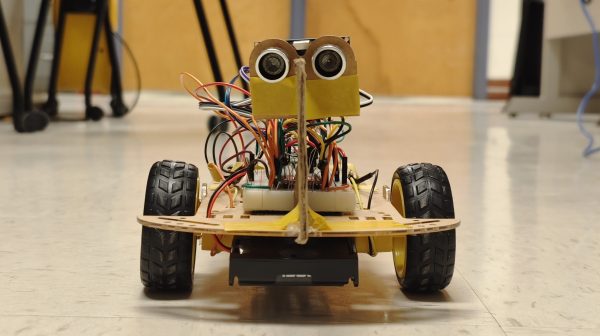
Their build is a small robotic platform that they assembled for their ECE5730 final project. The tiny wheeled robot is programmed to rotate on the spot until its infrared sensors pick up a signal. In turn, the user is intended to carry an infared beacon for it to lock onto. A pair of sensors are used on the robot platform, separated by a board to serve as a blind. The robot determines the relative signal strength from each sensor, and uses that to vary PWM signals to the two DC drive motors to steer the robot platform to seek and follow the infrared beacon.

It’s a neat idea, and looks to work pretty well in a university corridor. It even has an ultrasonic range sensor to (ideally) stop when it gets too close to the user. Whether it would survive the tumult of a crowded airport is another thing entirely, but that’s what the engineering process is about. Indeed, the very concept has been commercialized already!

Following-robots are a common student project, and one well worth exploring if you’re new to the robotic field.

Continue reading “Infrared Following Robot Built As Proof-of-Concept For Autonomous Luggage” →

Build Yourself A Screw Propelled Robot To Tackle The Dirt

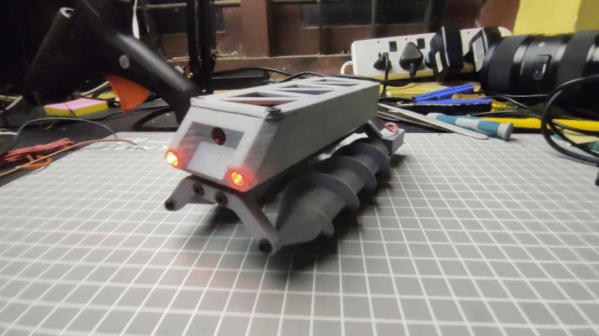
Wheels and tracks are common choices for robot propulsion, but they’re not the only game in town. You can do some nifty things with long extruded screws , and they work pretty well in soft terrain. [gokux] set about building a small robot using this propulsion method using 3D printed parts.

The build uses a Seeed Studio XIAO ESP32S3 as the brains of the operation. This provides wireless connectivity for remote control, as well as a way to get a low-latency video feed out of the robot from the OV2640 camera. The ESP32 controls a pair of brushed DC gearmotors via a DRV8833 motor driver. Each drives one of the two screws on the robot. By driving the two screws separately, the robot has simple skid steering. Two 18650 lithium-ion cells provide power for the robot, and are charged via a TP4056 battery charger module.

If you want to build a small robot that can handle soft terrain well, screw drives could be just the solution you’re looking for. They’re usually a bit slow, though, especially for human-scale conveyances, so don’t write off wheels or tracks if you don’t have to. And, of course, when your build is done, don’t forget to put it online and tell us all about it!

Gesture-Controlled Robot Arm Is A Nifty Educational Build

Traditionally, robot arms have been controlled either by joysticks, buttons, or very carefully programmed routines. However, for [Narongporn Laosrisin’s] homebrew build, they decided to go with gesture control instead.

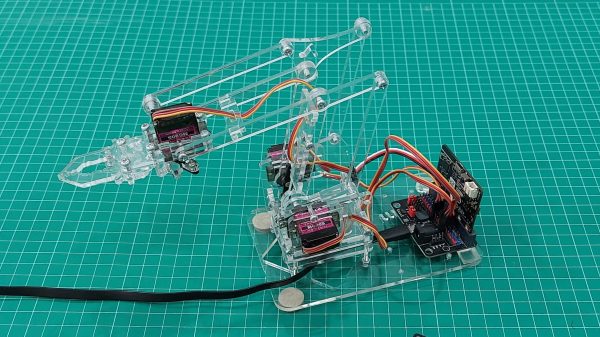
The MeArm robotic arm is built using laser cut acrylic parts, and can be had in a kit if so desired. It features four servo motors, charged with rotating the arm’s base, pushing the arm forwards and backwards, up and down, and actuating its gripper. The servos are under the command of a micro:bit microcontroller board, which itself receives signals from a second micro:bit which is strapped to the human wishing to control the arm. The second micro:bit detects gestures with its accelerometer, and then sends the relevant commands to the robotic arm’s micro:bit over its built-in radio link. The arm controller then commands the servos to execute the maneuver.

It may be a small robotic arm that doesn’t have the capacity to lift much, but that’s not the point. This project is a great way to teach students how to program microcontrollers, work with sensor inputs, and just generally how to solve engineering puzzles. To that end, it looks like [Narongporn] has a great project on hand for teaching their students. Video after the break.

Continue reading “Gesture-Controlled Robot Arm Is A Nifty Educational Build” →

Robot Goes To Summer Camp

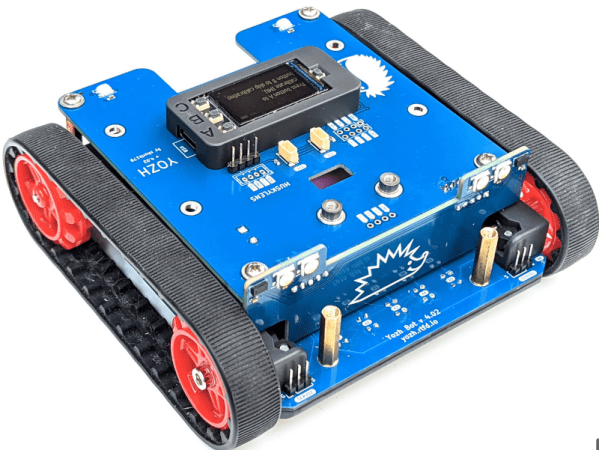
There are a lot of hobby and educational robots that have a similar form factor: a low, wide body with either wheels or tracks for locomotion. When [Alexander Kirilov] wanted to teach a summer robot camp, he looked at several different commercial offerings and found all of them somewhat lacking. His wish list was a neat-looking compact robot that was easy to extend, had various sensors, and would work with Python. Finding nothing to his liking, he set out to make his own, and Yozh robot was born.

The robot certainly looks neat. There is a color TFT display, seven reflective sensors pointing down, two laser time-of-flight sensors facing forward, an IMU, and some LEDs. There are plenty of expansion ports, too. You can check out the code that runs it, too.

Continue reading “Robot Goes To Summer Camp” →