Hairy Armor For Combat Robot? It’s Not Terrible!

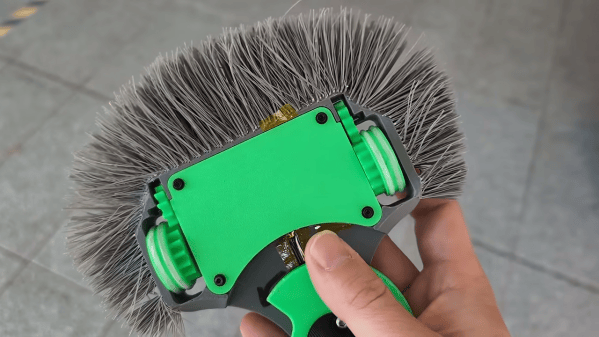
[Angus] of Maker’s Muse enjoys combat robotics, in which contenders zip about in an arena, attempting to disable one another with weapons that lift, spin, and smash. He got a funny idea a short while ago and wondered whether a stiff mane of bristles could serve as lightweight, ablative, impact resistant armor?

Just to set the stage, [Angus]’s new robot competes in the plastic antweight (or “plant”) division, in which robots are limited to 150 grams with both chassis and weapons made of plastic. In such circumstances, one can see how a mane of thick, rigid “hairs” might actually punch above its weight, so to speak.
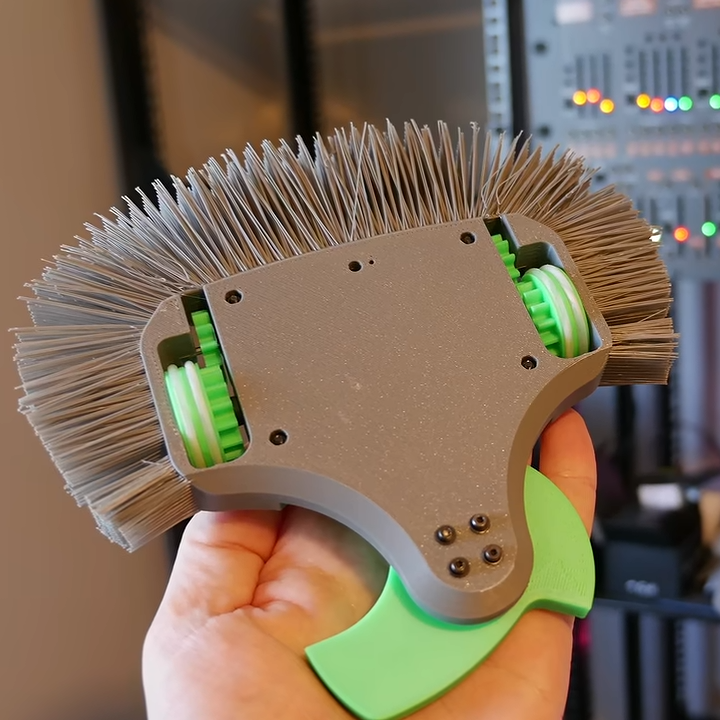
The green shape at the bottom is a spinning weapon. The bristles cover the sides and rear.

Nothing settles a question like a good experiment, so [Angus] sat down and redesigned his latest robot to replace its outer shell with a thick wad of bristles, in the style of a 3D printed lion’s mane. Filament is bridged between the model and an outer support structure, which is cut away afterwards to expose the “hairs”.

How well did it perform? Well enough to merit further study! Where past robots got their outer shells broken up, the hairy robot seems to have come through quite intact. It seems the idea might not be as silly as it first seemed, at least in the plastic antweight division.

3D printers have been fantastic in the field of combat robotics. First they were great because they made custom parts easier and more accessible to hobbyists, but things have evolved more since then. Now folks compete by putting motors and electronics inside almost entirely 3D printed robots. There’s never been a better time to get into combat robotics, and experiment with unorthodox designs.

If you want to try a hairy robot for yourself, be sure to watch the followup in which [Angus] improves the hair-generating process considerably.
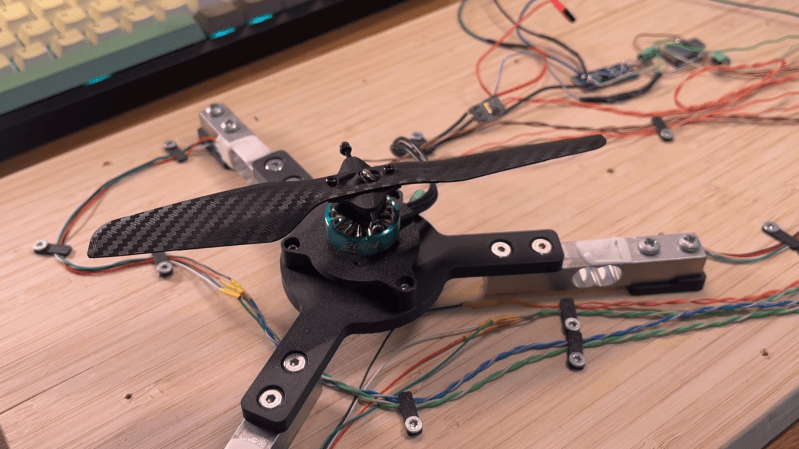
A 3D-printed propeller is shown mounted on a motor on a triangular test stand. Each corner has a load cell, and wires run from it to the right.

Building A Swashplate-less Helicoper Rotor

A helicopter blade uses a swash plate and a set of linkages to change the angle of the blades. Not only does it vary the collective pitch to increase or decrease thrust, but it varies each blade’s pitch throughout each rotation, letting it produce more lift on one side of the rotor. This presented a problem to [worked in theory] — he’s building an RC helicopter from scratch, and this mechanism added both complexity and weight. Instead, he started looking for a way to get around the problem.

There were two options to eliminate the linkages: a linkage-less swashplate design used in Black Hornet drones, and an under-actuated design using angled hinges to control the blade angle. [worked in theory] started with the Black Hornet design, which has the end of each blade run along the swashplate on wheels, while a central spring presses them down. Friction in the hinge and wheels proved too high, and it stopped responding at higher speeds. A second, lower-friction design seemed promising, but it still required actuators, and thus weight, to control the swashplate. [worked in theory] therefore moved on to the under-actuated approach. In this design, the blades are mounted on angled hinges — by varying the motor’s speed throughout each rotation, inertia causes the blades to swing backwards or forwards, changing their pitch.

[worked in theory] tested two such rotor designs: one with one hinge per rotor, and one with one hinge for both rotors. The design using a single hinge seemed less sensitive to friction, was more responsive in testing, and had a more linear control response, so he used that. To actually make the blades, [worked in theory] 3D printed them as flat blanks, then thermoformed them using printed molds. During testing, the blades needed weights added to pull them back toward the standard angle under constant rotation; fortunately, though, this had the side effect of damping out unwanted vibrations.

There’s still a long way to go before the helicopter’s finished, but this is quite an impressive start. This is the second under-actuated propeller we’ve seen recently, both inspired by [Tom Stanton]’s original design.

Continue reading “Building A Swashplate-less Helicoper Rotor” →

Transforming A Tungsten Ditelluride Monolayer Into A Transistor

In the world of silicon semiconductors, the process of creating transistors and similar structures involves various rounds of modifications and additions in order to create the requisite functional layers. A less involved approach would simply create these structures in-situ, with research the past years having focused on transition-metal dichalcogenide (TMDC) monolayers to do exactly this. Recently [Seok Young Min] et al. reported (paywalled, Phys.org summary) on creating transistors in-situ in a tungsten ditelluride (WTe2) monolayer.

By selectively changing parts of the top layer into tungsten oxide (WOx) as an insulator and other sections into n-type WS2 and p-type WSe2 the researchers were able to create functional MOSFETs, without the normally requisite grafting on of different materials. An obvious advantage of this is that this can be done at an atomic scale, potentially achieving densities significantly higher than with industry standard silicon semiconductor technology.

WTe2 is not the only TMDC that could be viable here, of course, with other researchers investigating the use of MoSe2 for a similar purpose, as in this research by [N. Lu] et al. from 2014. This being the creation of 2D semiconductors, referring to the thin layers of these monolayer TMDCs, along with potentially other materials such as graphene.

Hackaday Links Column Banner

Hackaday Links: October 25, 2026

Some disappointing, but perhaps not entirely unsurprising news this week out of Denmark — after announcing last year that they would transition away from Microsoft’s proprietary software, the realities of making it work seem to have caught the government off guard. The word is that a trial program immediately ran into problems when government employees that had been given Collabora tried to collaborate with their peers running Office, and has since been quietly abandoned.

Although there’s probably a joke to be made about different parts of the government not knowing what the other ones are talking about, the reality is that if one group of staffers can’t reliably access the data being produced by another, that’s a pretty big problem. Of course, had they simply asked us nerds, we could have advised them that these sort of issues are inevitable if you don’t fully commit to the effort.

Had the entire government moved to the Open Document Format (ODF) at once they would have avoided the issue, at least when it came to newly created documents, but obviously that’s a considerably larger undertaking than installing Collabora or OpenOffice on a few dozen machines and calling it a day. There’s no word yet on how this stumble will impact Denmark’s larger effort to free themselves of proprietary software, but we’d hazard a guess it’s not a great sign. Hopefully things go better for the Dutch.

Continue reading “Hackaday Links: October 25, 2026” →

A 3D Printed Marble Clock, But It’s Scrolling Text

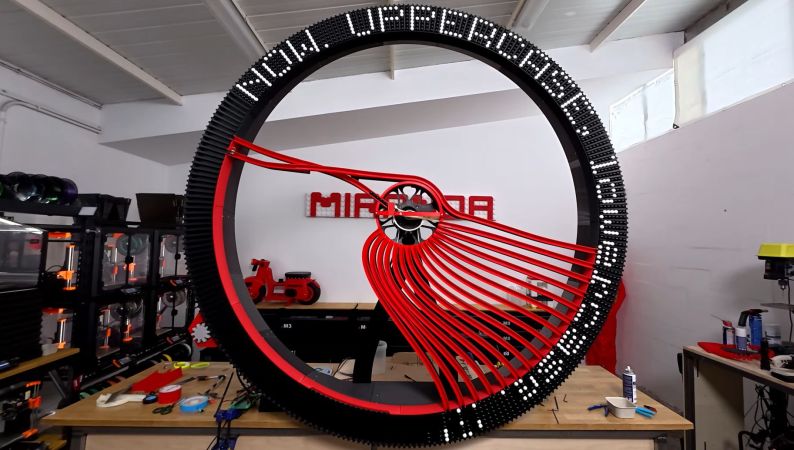
With the topic of marble clocks having been quite well explored at this point, it raises the question of how easy it would be to take the basic principle and create a text display using black and white marbles. As [Ivan Miranda] found out in a recent marble text scroller project, this is far from easy.

The reason why a scrolling text display was picked comes down to not wanting to be limited to a fixed number of digits. This resulted in a round wheel design, with inner steel ball bearings and a stepper motor on both the wheel and an inner selector mechanism. These respectively align the marble channels and pick the right color of marbles to be dropped into any of the wheel’s slots, creating the right sequence of marbles for the target text.

Perhaps the most amazing thing about it is that it’s an absolutely massive structure, yet it’s all 3D printed and bolted together. It took a number of trial-and-error cycles, and debugging issues like the IR sensors getting confused by daylight, but it now mostly seems to work all right.

There are still some remaining issues, such as having to manually home the wheel before starting, and the ratio of black vs white marbles can cause unexpected gaps in the final text. Despite this the text is quite legible and definitely infinite.

Continue reading “A 3D Printed Marble Clock, But It’s Scrolling Text” →

Mesh Network Telephony Over Bluetooth On Android Phones

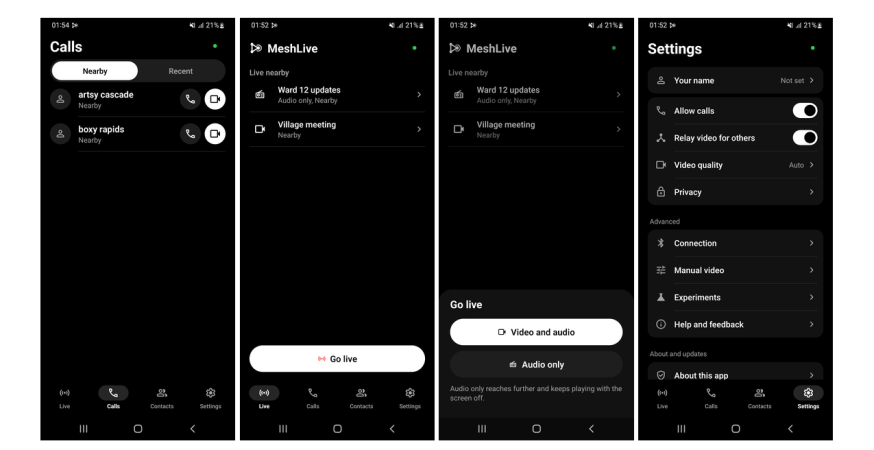
Telephony is a bit of a mixed bag. On the one hand, being able to talk to people in far off places is kind of neat, at least in theory. On the other hand, you’re usually reliant on a centralized network, which isn’t ideal to the mindset of most hackers.[Gautam]’s MeshLive project deals with that last one, offering a decentralized mesh network solution based on Bluetooth for Android phones that can handle both voice and video.

Rather than relying on dedicated hardware, this particular mesh piggybacks on your phone, and exists only as an Android application. Calls are end-to-end encrypted for both voice and video — though two-way video calling is still experimental. More testing has gone into video broadcasting, where a stream goes out one-way. The capability is available for voice, as well.

Each user has a unique identifier that can be scanned to create contacts, but it isn’t otherwise clearly identifiable to everybody. You’ll only appear with a random name that changes every 15 minutes to other users in range who aren’t your contacts. Range is of course the Achilles heel of this project, since it’s using the Bluetooth hardware of ordinary smartphones. It’s possible to extend the range of Bluetooth significantly with the right hardware, but we imagine most folks aren’t carrying directional antennas around with them. While every phone does forward the signal to as many others as it can, it can only do so for about 20 meters.

Of course LoRa remains the protocol of choice for mesh networking, though it’s normally used for text messages only. We have seen voice packets over LoRa, but anything LoRa requires dedicated hardware while this only requires an app.

Continue reading “Mesh Network Telephony Over Bluetooth On Android Phones” →

Simple, Reliable RF Remote Control

Some of the first remote controls available to consumers used sound, visible light, or even just wires to communicate with their parent device. It was many years between these first rudimentary remotes before they standardized around infrared or RF signaling. Even then it was a while before remote controls were reliable enough to not have to think about anymore. They’ve gotten so good now that there are small modules available that let us quickly build these devices to perform all manner of tasks.

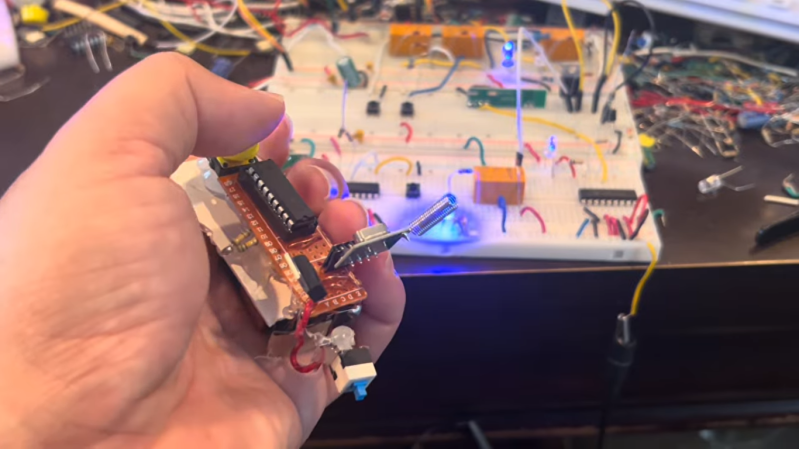
[Igor Brichkov] is demonstrating this project because his garage door remote control suddenly stopped working. The RF receiver and transmitter circuits are readily available and inexpensive, but they need some support circuitry to work properly. The transmitter is paired with an encoder which is provided a binary code by wiring various pins to power and ground. This “code” is sent to the receiver which has a decoder and listens for that specific code. When the codes match it changes the state of one of its pins, which is used in this case to short the garage door’s remote terminals and signal it to open the door.

Although the resulting handheld remote with its single button looks a bit like something from 1950s science-fiction, it’s an effective solution. Especially when compared to possibly trying to reprogram a proprietary remote, find one from a company that doesn’t exist anymore, or rebuild one that operates on a bizarre frequency. With access to the physical hardware, it turns out a lot of things are controlled by just shorting pins together, and anything can do that from wires to RF transmitters.

Continue reading “Simple, Reliable RF Remote Control” →