
We’ve started to noticing a lot of commercial electric bikes on the street. Last year we looked at an electric trike project, after the break find out what people have been up to lately with similar projects.
This Week In (our) History
Time to look way back into the Hackaday archives, well back to 2005 at least. This is a new feature to follow up and revisit some of our favorite projects of the past. Our first installment includes the week of May 24-31 2005.
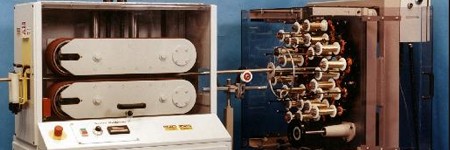
Pictured above we see one of the amazing cable braiding machines from UK based Cobra Machinery. This link was found on a post about creating your own high end speaker wires from cat5 cable. At the time we hoped to find a DIY braiding machine. No such luck today but we did come across and interesting site in the process. diyAudoProjects has a ton of great how to guides for all things audio. They even have a few walkthroughs for creating your own speaker wires.
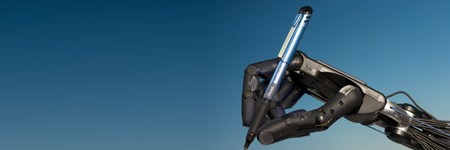
We looked at the robotic dexterous hand from The Shadow Robot Company. Browsing through their high rez image gallery its pretty clear to see the product has been progressing nicely: 24 degrees of freedom complete with force feedback and a GPL based software package.
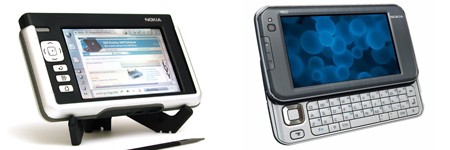
Three years ago we covered the Nokia 770 internet appliance and it’s upcoming SDK. The device has now been replaced by the Nokia N810 (pictured on the right). However, open source support from Nokia has continued to develop. We found a blog from software developer Ari Jaaksi where he talks about Nokia’s involvement in the community. Recently he discussed the latest news from MAEMO, the platform used for open source development of Nokia internet tablets and other Linux-based devices.
Picaxe Tachometer
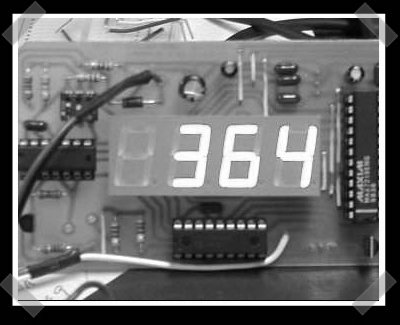
It might seem like we’re on a vehicle hacking kick this weekend, but [Rex] built an excellent custom digital tach for his race car. It uses the classic seven segment displays, a PICAXE microcontroller and works with most engines. He’s released full source and PC board designs to boot. This looks like a great little tachometer project for you microcontoller fiends out there.
Silicon Hacking

Wired recently posted an article and video detailing our friend [Chris Tarnovsky]’s process for hacking smart cards. In the video, [Chris] shows how he strips away physical components of the chips inside the smartcards using various gadgets and chemicals.
The first step is to remove the chip from its plastic frame. After soaking it in acid for about 10 minutes, the epoxy is removed and the chip is exposed. After that the outer layer is loosened by soaking the chip in two solutions of acetone, the second being the “clean” one. Then the chip is placed on a hotplate where a drop of fuming nitric acid is applied with a dropper; the chip is washed again in an ultrasonic cleaner, removing any residue left.
[Chris] then returns the chip to the card. He will apply nail polish to act as a masking material. He scratches a hole through the polish with a needle held by a micro positioner in the area of interest. The hole is treated with hydrofluoric acid and then etched in short intervals until the desired layer of silicon is exposed. At this point, the card is fully prepped.
Now by powering the chip with the needle resting on the bus, [Chris] can read the code on the chip by sending it various commands and watching how it reacts. To see more of [Chris]’s reverse engineering work, check out Flylogic Engineering’s Analytical Blog. It’s a enjoyable read even if you’re new to silicon hacking.
Robotic Cats
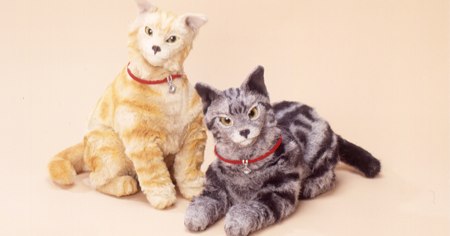
It’s caturday, so let’s post some freaking cats. With a little research we found commercial, hobbyist, research, and cyborg cats.
First up is NeCoRo. Released in 2001, this is probably the most recognized commercial robot cat; renowned for its creepiness.
Nanobot Nanosoccer
Medgadget recently published a post about a soccer competition for nanobots at RoboCup. The nanobots compete on a field that measures 1500 by 2500 micrometers with goals on the long sides jutting 500 micrometers out. Like normal soccer athletes, the nanobot teams attempt to push the ball – in this case, a silicon dioxide disc with a 50 micrometer diameter – into the goal. The nanobot competitors are monitored by an optical microscope and are remotely controlled by magnetic signals sent across the arena.
The National Institute of Standards and Technology (NIST) and RoboCup have already held two nanobot competitions in the last year. Nanobots made by different teams from various universities compete to test various abilities that will be critical for their practical applications in medicine, manufacturing, and other industries.
Though it is referred to as nanosoccer, the competition is actually a triathlon. The bots must sprint to the goal with the ball in one event, then maneuver the ball around stationary “defenders” and into the goal in the next event, and finally score as many goals as possible within 3 minutes. NIST and RoboCup hope to show the practical potential of nanobots with this competition and have a little fun in the process.
[via Medgadget]
Digidash: Digital Dashboard For Megasquirt
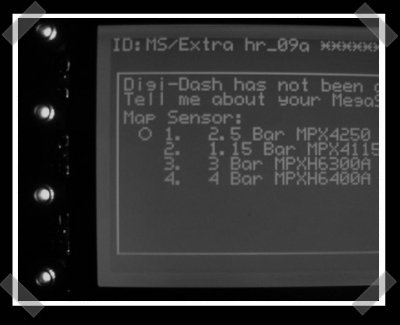
The Digidash project is an open source digital dashboard designed just for the megasquirt EFI system we mentioned in our diy EFI motorcycle post. Unfortunately, the site doesn’t link the hardware design. From the description, I’m assuming that it’s essentially a graphic LCD driven by an Atmel microcontroller that talks to the Megasquirt to get the display info.









