Steam power is a staple of the steampunk aesthetic, thermodynamics, and a checkpoint for the budding mechanical engineer studying heat cycles. But because food is largely made of water, steam is also common in the culinary arts. So it’s no surprise that when thermodynamics is applied to cooking, exciting things can happen.
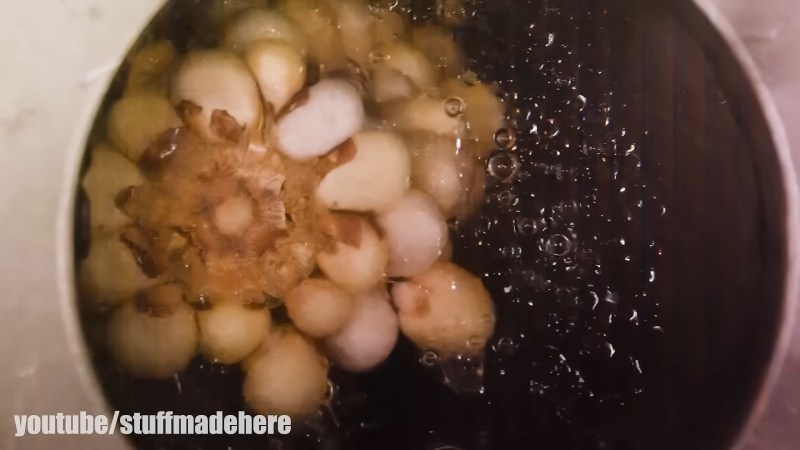
This particular example of steam-powered culinary happenings is inspired by industrial potato-peeling machines. By adding high-pressure, high-temperature steam to a pressure vessel with potatoes inside, heat can transfer more easily to the inside of the potatoes. Because the pressure is so high, however, the water in the skin won’t boil. This is fundamentally the same concept as a pressure cooker. However, what’s different is that instead of a pressure cooker’s slow release, these industrial peeling machines rely on explosive decompression, flash boiling the water underneath the potato’s skin. This rapidly expanding steam rips away the skin in a nice clean sheet.
But, to [Stuff Made Here’s] disappointment, there were no videos of the process on the internet. But, fortunately for us, being an engineer of complicated machines means that there is one now that you can watch below.
There are plenty of stories about inventors who see a problem and decide they can do better. But Van Phillips had a little more motivation than most. The problem was his own leg. In 1976, Phillips was a 21-year-old college student when a water-skiing accident cost him his left leg below the knee. If that wasn’t bad enough, the prosthetic leg he received afterward wasn’t exactly a technological marvel. Prosthetic limbs of the era were generally designed to look and act something like a biological leg and foot, but “act” might be giving them too much credit. They were passive structures that provided something to stand on and roll over while walking.
Phillips wanted to do more than walk. There was just one problem: he wasn’t an engineer. Before the accident, he had been studying business. So, if he was going to build a better leg, first he was going to have to learn how.
Back To School
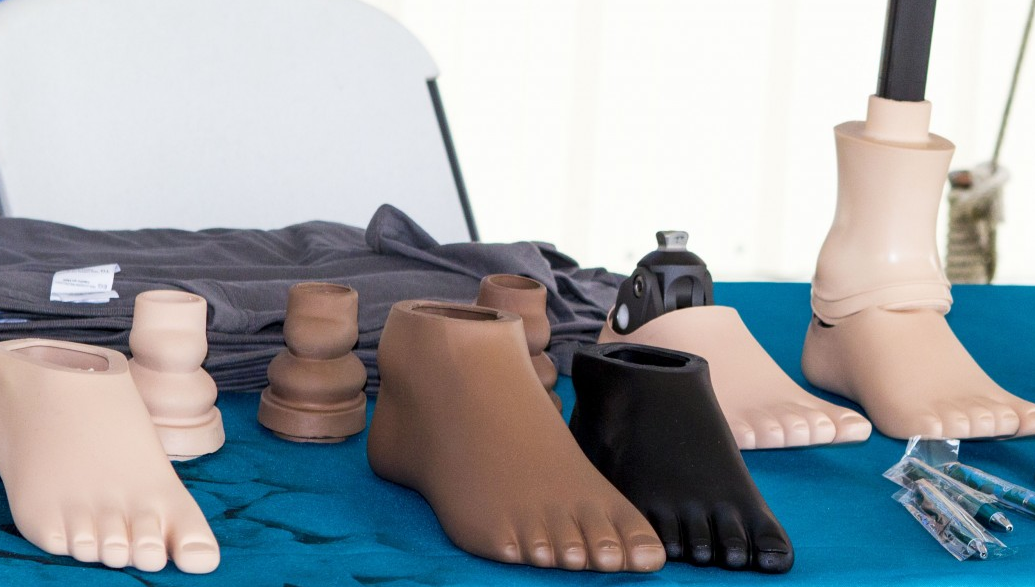
Traditional prosthetic feet (public domain)
Phillips became fascinated with prosthetics and eventually studied prosthetic design at Northwestern University’s Prosthetic-Orthotic Center. He also worked at the University of Utah’s prosthetics laboratory, where he had access to both the people and equipment he needed to experiment.
The conventional wisdom was that a prosthetic foot should imitate a human foot. That seems perfectly reasonable — evolution has had quite a long time to work on the design. But there’s a problem with simply copying the shape. A real foot isn’t just a foot-shaped object attached to the bottom of your leg. Muscles, tendons, and ligaments store and release energy as you walk or run. Your Achilles tendon, in particular, acts very much like a spring. A conventional prosthetic foot might look right, but it didn’t have anything corresponding to that spring.
Phillips eventually stopped worrying so much about making something that looked like a foot. Instead, he decided to make something that worked like one.
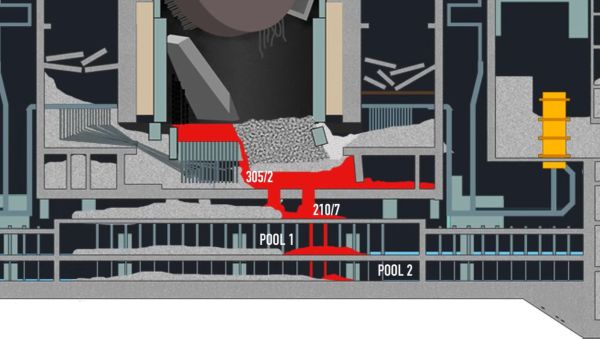
With the massive steam explosion that shredded the #4 RBMK reactor at the Chernobyl Nuclear Power Plant in 1986 it suddenly made robots that could survive a high ionizing radiation environment into the hottest item on the planet. Over the course of forty years many generations of such robots were developed, tested, improved upon or discarded, all to explore and handle hazardous waste throughout the depths of the #4 reactor’s remains.
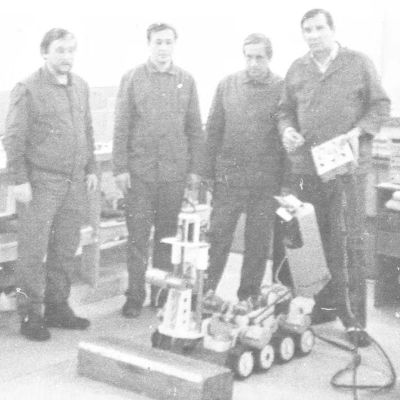
Researchers of the ISP NPP next to one of the TR robots. (Credit: ISP NPP)
Even if the entire development and decisions here would easily fit a couple of feature length movies, the recent documentary by the [Chornobyl Family] provides a solid overview of the engineering challenges, the issues encountered along the way and the forced evolution of initially very basic designs into the robotics that today trundle and wriggle around inside reactor #4, as well as their cousins over at the couple of stricken reactors at Japan’s Fukushima Daiichi power station.
Unlike the other robots developed from 1986 onwards to provide general clean-up of scattered core material outside of the core, these robots had to venture deep inside, where radiation levels were the highest and correspondingly the challenges much more severe. This was such a problem that initially it were humans who did the exploration, as robots proved to be too fragile and too prone to getting stuck.
Until the 1990s exploration of the ruined core was quite limited, also because of a lack of urgency. While the outside clean-up and construction of the sarcophagus had to be done as quickly as possible, the core exploration was more slow and methodical, based around trying to establish its condition, what core material remained inside and try to take samples of interesting objects like the well-known ‘elephant’s foot’.
When we last left off, I had just set up a new SLA resin printer and was on the verge of doing the initial round of printing to see just how resin printing in 2026 compares to way back in 2020. Surely SLA printing had to be easier and less fussy than it was in 2020?
During these weeks of printing, setting up printers and taking a gander at the various workflows that certain printers and their manufacturers try to push you into I have both produced a series of not too shabby prints and some delightful spaghetti. I also flipped a few proverbial tables and formed some strong opinions on 3D printing workflows, of which some can considered to be family-friendly.
Without further ado, let’s get into some updates, a bit of ranting, and even some printing results.
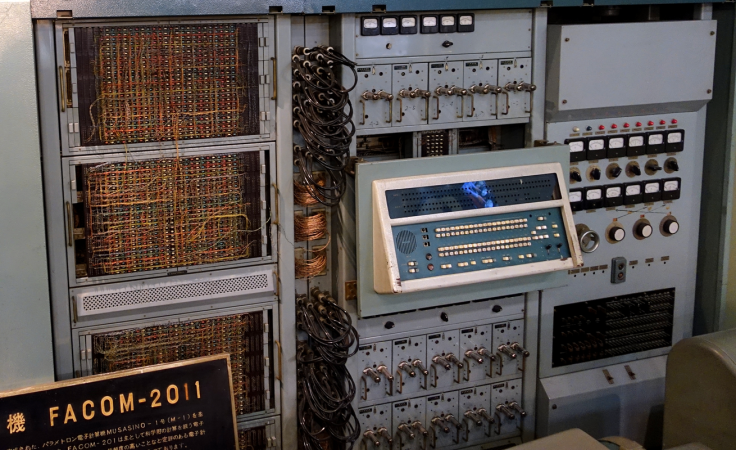
However you make a digital computer, you need something to represent a binary digit. Usually this is some form of switch: a relay, a tube, or a transistor, although there have been other ways to represent state. In 1954, [Eiichi Goto] of Japan invented the parametron, a resonant circuit using a ferrite core and a capacitor that could be moved between two phases.
According to [Goto’s] 1959 paper, the device is effectively a parametric oscillator, similar to some used at UHF frequencies by hams. The idea is that a tuned circuit is set to some frequency and driven with twice that frequency.
A What?
A parametron is essentially a resonant circuit made with inductors or capacitors whose reactance is varied at twice its resonant frequency. That “pumping” causes the circuit to oscillate at half the pump frequency. The neat trick is that there are two equally stable oscillation states at half the pump frequency, separated from each other by 180° of phase. Those two phases become binary 0 and 1. Depending on the incoming signals, one phase will win over the others.
Recently thermal power stations have been in the news quite a bit, mostly in the context of them being throttled back or shut down due to the river water used to cool them either getting too warm or said river having dropped to a level where it can no longer provide cooling water. Obviously this is a problem, but it helps to understand how we got to this point and what can be done to fix it.
Thermal power stations – also called power plants – come in a wide variety of shapes and sizes, ranging from old-school coal- and gas-fueled power stations to modern nuclear power plants. Something like a concentrated solar power (CSP) station is also a thermal power station, as all of them have a heat source that’s used to generate electricity from, whether that’s a boiler, nuclear reactor core or a big vat of sodium heated up by the Sun via massive mirrors or oil-filled tubes in parabolic throughs.
Except for open-cycle gas turbines (OCGTs) – which are basically jet engines connected to a generator – this thermal energy is then used to generate steam that drives a steam turbine. Once most energy in the steam has been depleted, it has to be condensed back into e.g. water, so that it can be led back to the steam generator. How this condensing step is performed is the question here, with a number of methods available.
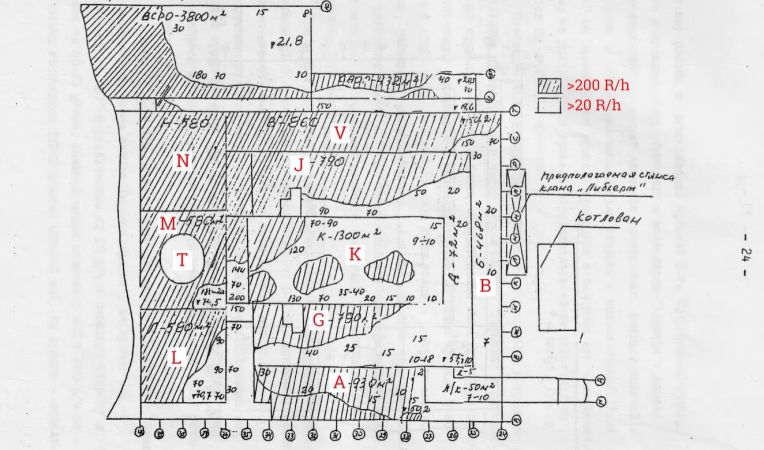
When the Chernobyl Nuclear Power Plant’s #4 reactor experienced an extreme criticality event on that infamous day in 1986, the resulting steam explosion and lack of any kind of containment building meant that parts of the core were scattered throughout the site. In an extensive update to the original 2023 video, the [Chornobyl Family] covers the mad scramble to design robots to perform on-the-ground measurements, and ultimately remove all this debris for safe disposal.
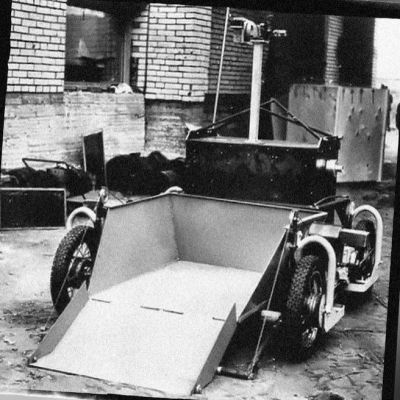
The TR-1A, an early debris removal robot. (Source: Chornobyl Family, YouTube)
This essentially took the form of a hackathon, involving teams from all over the USSR and allied nations, creating the most diverse range of robots that 1980s Soviet technology and later Western technology could muster.
Many of these robots didn’t perform very well, or at all, mostly due to the bypassing of any kind of testing before deployment. Especially at the beginning of the clean-up the robots were being pushed into the high-radiation zones as soon as they were finished, with not only mechanical issues being a problem, but also with e.g. inaccurate radiation measurements by the RR-1 robot, that overstated measurements by more than a factor of ten. Meanwhile the RR-2 and RR-3 were too top-heavy and after deployment by helicopter simply tipped over. Eventually manual measurements proved to be faster and safer.
Early debris removal robots like the TR-1A were rather simplistic, with successive generations of robots over the next weeks and months improving on it. The use of a combustion engine instead of batteries provided to be a boon, as combustion engines are far less affected by radiation.
The BAER Beloyarets used an airport cart as the basis, with its electronics relying on vacuum tube technology and relays, with an internal combustion engine. This proved to be one of the most reliable designs and it’s been largely preserved on display in the Chornobyl Exclusion Zone, with many others of these robots also being on display around the nuclear plant or in the city of Chornobyl.
Overall an absolutely dizzying number of robotic designs were invented on the spot, adapted from existing designs or repurposed for operation in a high-radiation zone. Eventually bulldozer designs like the STR-1 helped to push radioactive debris off the roofs into containers, massively reducing the radioactive contamination of the area.
The fact that following #4’s RUD the other three RBMK units were able to keep operating safely without risks to its operators, and with the zone now safe for tourists, is a real testament to the success of the worst hackathon imaginable. Many of the lessons learned are relevant today, including during the decommissioning of Fukushima Daiichi’s melted-down cores.