Pitting A Modern Chess Engine On A Pentium PC Against 1996’s Deep Blue

Although premature optimization can be a really bad thing, late optimization is sometimes unavoidable because we simply didn’t know about certain algorithms yet to massively improve the solving of a problem. When the 1990s was all about beating chess grandmasters at their game, IBM went so far as to build a the Deep Blue custom super computer for it. This is what [Nicholas Carlini] managed to effectively beat using a version of the Stockfish chess engine running on an era-appropriate Pentium PC.

A common way to measure one’s skill in chess involves the Elo rating system, named after chess master and physics professor [Arpad Elo]. As a relative system, it can be used to compare different players including chess engines against each other, with IBM’s Deep Blue scoring 2700, with the modern-day Stockfish engine hitting around 3700. This makes Stockfish statistically much more likely to win against a human chess grandmaster than Deep Blue, but also raises the question of how much of this advantage is due to Stockfish running on a much faster system.

To investigate the impact here, [Nicholas] used a Pentium Pro 200 MHz system with 64 MB of RAM (Fast Page or EDO SIMMs), which would have been a rather nice system for about 1995. Two chess engines were ported to this platform, being Crafty and Stockfish. Next both engines were tweaked with the help of an LLM coding bot to see what difference various compilation flags and algorithms would make.

Based on the results it would seem that the answer is ‘yes’: this 200 MHz Pentium Pro could have likely beaten even a chess grandmaster like [Kasparov] and Deep Blue in at least a few games, though without going back in time by about thirty years we’ll never know for certain.

Header: Wilfredor, CC0
Robot Chess But Each Piece Is A Small Robot

A topless chess piece. (Credit: 3DprintedLife, YouTube)

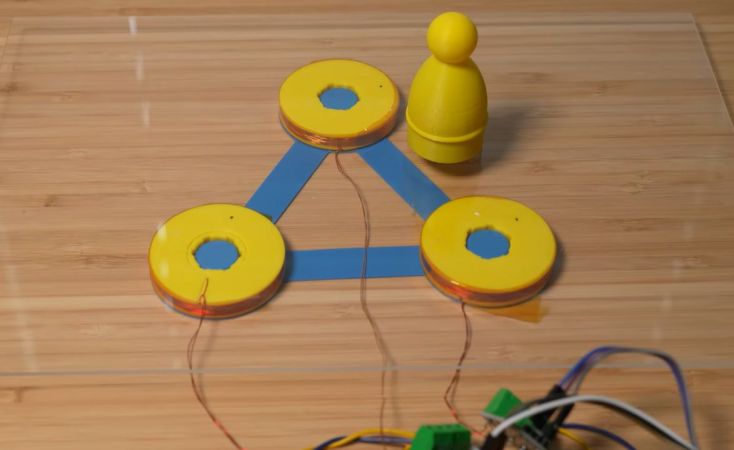
We have seen a number of self-playing chess boards over the years, but the general theme has been standard chess pieces moved by either an internal electromagnet or an external robotic arm. This is, of course, a reasonable choice, as it reduces complexity, and sometimes you can even use standard chess pieces on a regular board. But what if each piece could move by itself? That seems cooler, so that’s what [3DprintedLife] did with 3D-printed chess pieces that are also tiny robots.

Although technically not the first, as you can buy the commercial Chessnut Move offering, this being an open hardware and source project makes it a lot more interesting, also because the general design is generic enough to be usable for applications other than just playing chess.

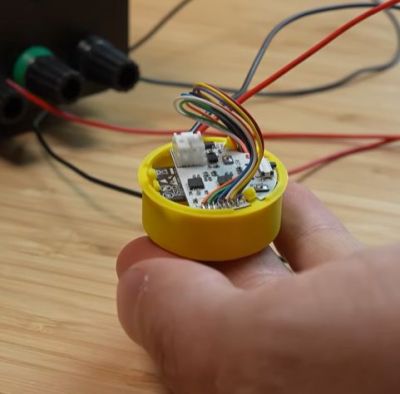
The MiniBots, as the individual pieces are called, are built around a custom PCB with an ESP32-C3 module, two PMO8-2 miniature stepper motors with requisite drivers, a magnetometer, and are powered by a 170 mAh LiPo battery. Communication with the central hub is done using ESP-NOW, with each MiniBot using its own dedicated channel.

This hub’s mainboard also runs on an ESP32-C3 for the wireless interface, while the processing is handled via a serial link with a Raspberry Pi SBC that runs the main Python-based software. Localizing the individual pieces on the board is done by scanning electromagnets embedded in the board and using the readings from the individual magnetometers to triangulate the positions.

Although at the end of the video a basic prototype sort of works, the ESP32-C3, being a single-core MCU, tripped up the firmware, necessitating some changes that should be in the next update, along with power saving and easier recharging being issues to address.

If you want to see a more conventional chess robot, we’ve seen plenty.

Continue reading “Robot Chess But Each Piece Is A Small Robot” →

For Such A Small Program, ZX81 1K Chess Sure Packs A Lot In

The Sinclair ZX81 was hardly the most accomplished of 1980s 8-bit microcomputers, but its ultra-low-budget hardware was certainly pressed into service for some impressive work. Perhaps the most legendary piece of commercial software in this vein was 1K Chess, which packed an entire chess engine into the user-available bytes in the unexpanded 1K ZX’s memory map. [MarquisdeGeek] has taken this vintage piece of code in 2026 and subjected it to a thorough analysis, finding all the tricks along the way.

Though hackers have since found ways to trick the ’81 into displaying bitmap graphics, using it as intended is text-only with some limited block graphics. The chess board then is text-only, and its illusion of “thinking” about moves comes courtesy of the on-screen board doubling as the play area memory. In the GitHub repository you can find decompiled and annotated versions as well as the original ZX binary, with as a bonus a screen capture of the game as it appears as BASIC with the ZX’s odd means of storing Z80 code in REM statements.

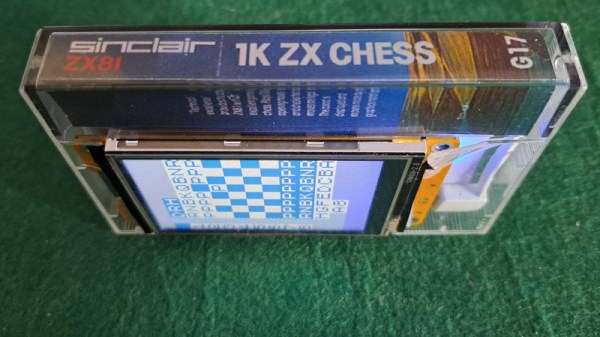
If that wasn’t enough, in his note giving us the tip he reveals that much of the work was done in a ZX emulator running in a Dragon emulator, and gives us a fun glimpse of the game running in an emulator on a Cheap Yellow Display inside 1K Chess cassette box. We like it, a lot!

If you need a greater ZX81 fix, take a look at how this machine chased the beam to make TV graphics on the cheap.

Cynus Chess Robot: A Chess Board With A Robotic Arm

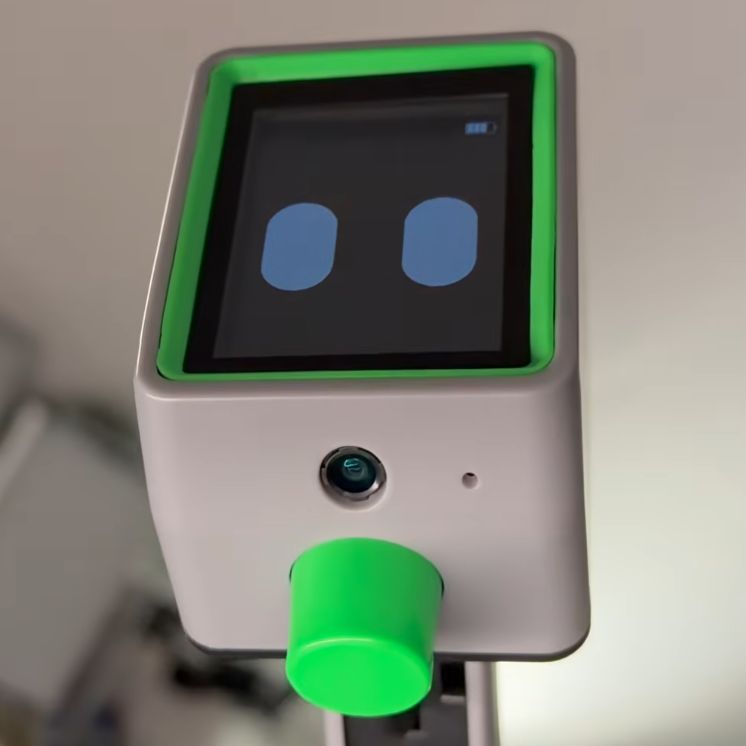
Downward-facing camera and microphone in the arm. (Credit: Techmoan, YouTube)

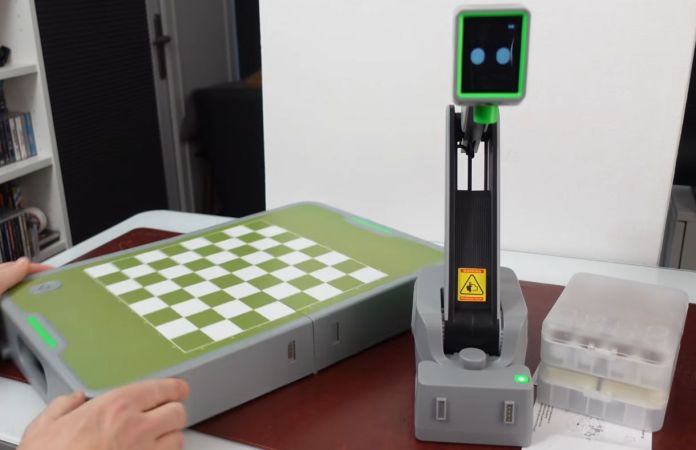
There are many chess robots, most of which require the human player to move the opposing pieces themselves, or have a built-in mechanism that can slide the opposing pieces around to their new location. Ideally, such a chess robot would move the pieces just like how a human would, of course. That’s pretty much the promise behind the Manya Cynus chess robot, which [Matt] over at the Techmoan YouTube channel bought from the Kickstarter campaign.

Advertising itself as a ‘Portable AI Chess Robot’, the Manya Cynus chess robot comes in the form of a case that unfolds into a chess board and also contains the robotic arm that contains the guts of the operation. Powered by the open source Stockfish chess engine, it can play games against a human opponent at a few difficulty levels without requiring any online connectivity or a companion app. It moves its own pieces by picking up the metal-cored chess pieces with its arm, while its front display tries to display basic emotions with animated eyes. A 3-MP downward-facing camera is located on the head section, along with a microphone.

As for how well it works, [Matt] isn’t the best chess player, but he had a fair bit of fun with the machine. His major complaints circle around how unfinished the firmware still feels, with e.g., invalid moves basically ignored with only a barely visible warning popping up on the screen. In general, he’d rather classify it as an interesting development kit for a chess robot, which is where the BLE 5.1-based interface and a purported Python-based development environment provided by Manya seem to come into focus.

Continue reading “Cynus Chess Robot: A Chess Board With A Robotic Arm” →

Taser Chess Teaches Valuable Lessons The Hard Way

Over the last few centuries, behavioral psychologists have documented all kinds of ways of modifying our actions and the actions of various animals. From the famous Skinner boxes to many modern video game mechanics, animals and humans alike can learn through the addition or subtraction of various rewards and punishments. And it doesn’t only impact simple actions either; [Everything is Hacked] took this idea to the extreme, using painful electric shocks to teach himself to avoid making blunders while playing chess.

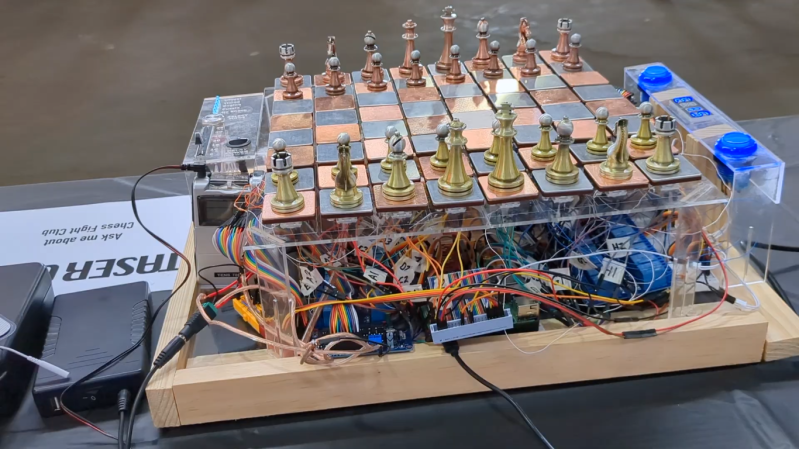
This positive punishment system uses a medical device called transcutaneous electrical nerve stimulation (TENS) to deliver an electric shock to the skin. The electrical jolt is routed through a custom-built, conductive chess board where each square is isolated from the others and controlled by its own relay. The pieces are conductive as well, so if one is placed on a square where it shouldn’t go a relay will switch on to quickly provide the behavioral modification. The control logic is provided by a Raspberry Pi running the Stockfish chess engine, and it keeps track of the locations of the positions of all the pieces by using MX switches in the base of each square on the board.

This project took [Everything is Hacked] over a year to get into a working condition, including having to rebuild the entire project twice after mishaps with baggage handling at an airline. But he was able to demo the board to the Open Sauce tech festival and even took it to his local park to play chess with the local hustlers. Unfortunately, he reports that he spent more time reworking and rewiring his board over that year than he did improving his chess game, so unfortunately he still hasn’t been able to win any of his money back yet. Perhaps combining this project with a chess-playing robot would help.

Continue reading “Taser Chess Teaches Valuable Lessons The Hard Way” →

Regular (Expression) Chess

[Nicholas Carlini] found some extra time on his hands over the holiday, so he decide to do something with “entirely no purpose.” The result: 84,688 regular expressions that can play chess using a 2-ply minmax strategy. No kidding. We think we can do some heavy-duty regular expressions, but this is a whole other level.

As you might expect, the code to play is extremely simple as it just runs the board through series of regular expressions that implement the game logic. Of course, that doesn’t count the thousands of strings containing the regular expressions.

Continue reading “Regular (Expression) Chess” →

Dog Plays Chess On ESP32

The ESP32 is s remarkably powerful microcontroller, where its dual-core processor and relatively high clock speed can do some impressive work. But getting this microcontroller designed for embedded systems to do tasks that would generally be given to a much more powerful PC-type computer takes a little bit more willpower. Inspired by his dog, [Folkert] decided to program an ESP32 to play chess, a famously challenging task for computer scientists in the past. He calls this ESP32 chess system Dog.

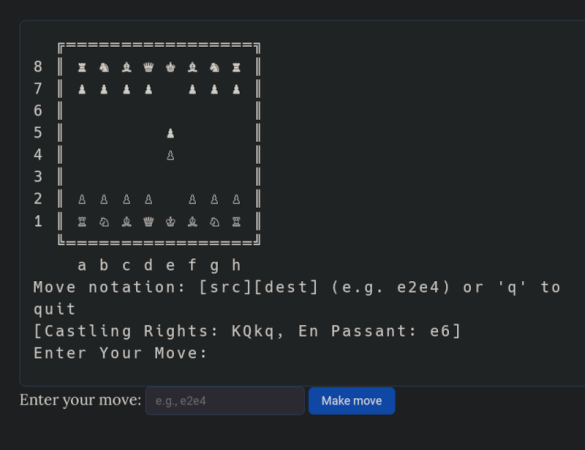
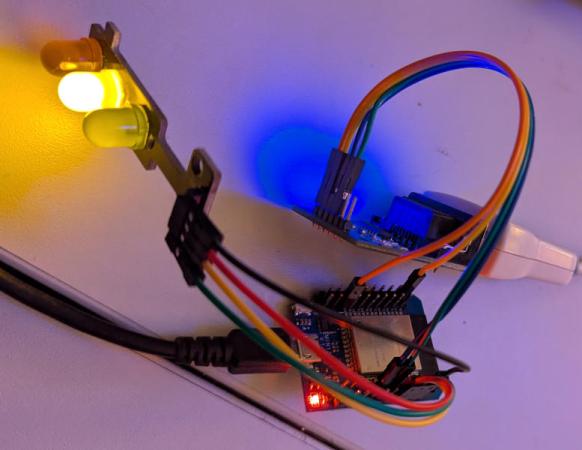
One of the other major limitations of this platform for a task like this is memory. The ESP32 [Folkert] is using only has 320 kB of RAM, so things like the transposition table have to fit in even less space than that. With modern desktop computers often having 32 or 64 GB, this is a fairly significant challenge, especially for a memory-intensive task like a chess engine. But with the engine running on the microcontroller it’s ready to play, either in text mode or with something that can use the Universal Chess Interface (UCI). A set of LEDs on the board lets the user know what’s going on while gameplay is taking place.

Continue reading “Dog Plays Chess On ESP32” →