VR Headset Ditches The Base Stations With DIY Tracking

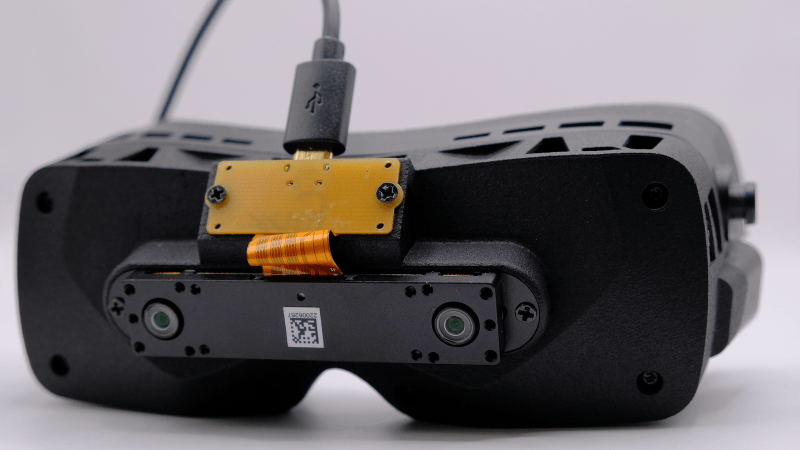
Those in the virtual reality scene might be interested in [Prohurtz]’s add-on for the Bigscreen Beyond VR headset. BSB-SLAM adds SLAM (Simultaneous Localization and Mapping) tracking to the headset by attaching a sensor to the front of the headset, and providing the software to tie the two together. As a result, the headset can be fully tracked in 3D space with no need for external base stations. It essentially adds inside-out tracking as a DIY add-on.
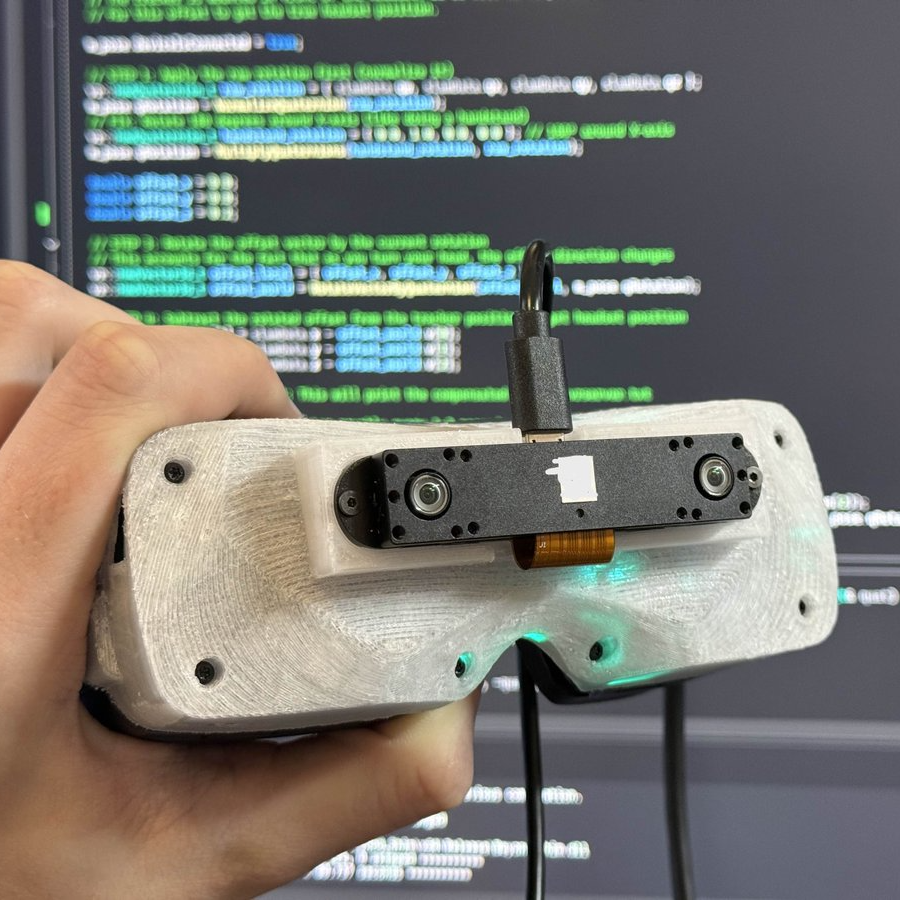
An early version, shared with a brief video demo posted to X.

Just to be clear, that doesn’t mean the headset becomes wireless. The Beyond connects to a PC, essentially acting as a display, and that part is the same. But it does mean the headset is no longer tied to having to work in a room with base stations pre-installed.

[Prohurtz]’s solution does this by adding a small off-the-shelf Xvisio XR50 board, USB cable, and 3D-printed mount to the unit. The headset works as normal, just with some extra software needed to use the sensor data in lieu of the base stations.

As far as sensors go the Xvisio XR50 is a bit spendy, but the fact that a small and lightweight SLAM sensor that’s capable of delivering positioning data suitable for tracking a headset in near real-time can be bought online and so readily adapted is pretty interesting.

[Prohurtz] got the idea working back in 2025 but it’s now at the point where one can order a part, print an adapter, and be off to the races with a software package.

This isn’t [Prohurtz]’s first time with VR hardware, either. The EyeTrackVR eye tracking add-on is also their work, combining largely off-the-shelf hardware into an effective DIY solution for VR use.

Lynx-R1 Headset Makers Release 6DoF SLAM Solution As Open Source

Some readers may recall the Lynx-R1 headset — it was conceived as an Android virtual reality (VR) and mixed reality (MR) headset with built-in hand tracking, designed to be open where others were closed, allowing developers and users access to inner workings in defiance of walled gardens. It looked very promising, with features rivaling (or surpassing) those of its contemporaries.

Founder [Stan Larroque] recently announced that Lynx’s 6DoF SLAM (simultaneous location and mapping) solution has been released as open source. ORB-SLAM3, modified for Android-based hardware (GitHub repository), takes in camera images and outputs a 6DoF pose, and does so effectively in real-time. The repository contains some added details as well as a demo application that can run on the Lynx-R1 headset.

The unusual optics are memorable. (Hands-on Lynx-R1 by Antony Vitillo)

As a headset the Lynx-R1 had a number of intriguing elements. The unusual optics, the flip-up design, and built-in hand tracking were impressive for its time, as was the high-quality mixed reality pass-through. That last feature refers to the headset using its external cameras as inputs to let the user see the real world, but with the ability to have virtual elements displayed and apparently anchored to real-world locations. Doing this depends heavily on the headset being able to track its position in the real world with both high accuracy and low latency, and this is what ORB-SLAM3 provides.

A successful crowdfunding campaign for the Lynx-R1 in 2021 showed that a significant number of people were on board with what Lynx was offering, but developing brand new consumer hardware is a challenging road for many reasons unrelated to developing the actual thing. There was a hands-on at a trade show in 2021 and units were originally intended to ship out in 2022, but sadly that didn’t happen. Units still occasionally trickle out to backers and pre-orders according to the unofficial Discord, but it’s safe to say things didn’t really go as planned for the R1.

It remains a genuinely noteworthy piece of hardware, especially considering it was not a product of one of the tech giants. If we manage to get our hands on one of them, we’ll certainly give you a good look at it.

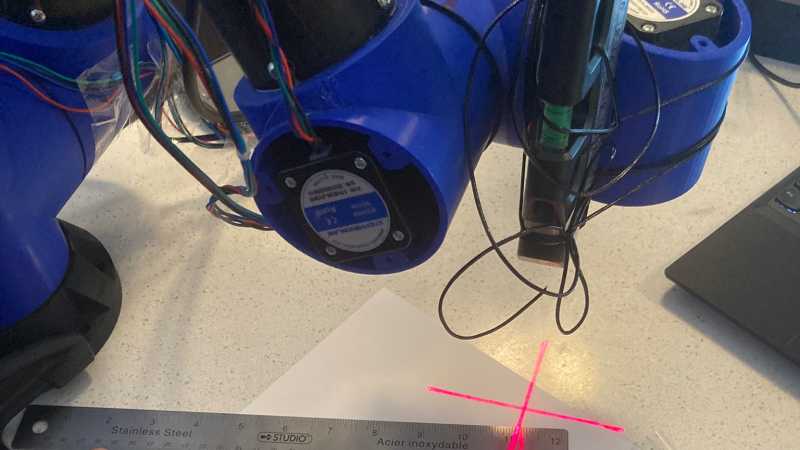
ManiPylator focusing its laser pointer at a page.

Simulation And Motion Planning For 6DOF Robotic Arm

[Leo Goldstien] recently got in touch to let us know about a fascinating update he posted on the Hackaday.io page for ManiPylator — his 3D printed Six degrees of freedom, or 6DOF robotic arm.

This latest installment gives us a glimpse at what’s involved for command and control of such a device, as what goes into simulation and testing. Much of the requisite mathematics is introduced, along with a long list of links to further reading. The whole solution is based entirely on free and open source (FOSS) software, in fact a giant stack of such software including planning and simulation software on top of glue like MQTT message queues.

The practical exercise for this installment was to have the arm trace out the shape of a heart, given as a mathematical equation expressed in Python code, and it fared quite well. Measurements were taken! Science was done!

We last brought you word about this project in October of 2024. Since then, the project name has changed from “ManiPilator” to “ManiPylator”. Originally the name was a reference to the Raspberry Pi, but now the focus is on the Python programming language. But all the bot’s best friends just call him “Manny”.

If you want to get started with your own 6DOF robotic arm, [Leo] has traced out a path for you to follow. We’d love to hear about what you come up with!

Continue reading “Simulation And Motion Planning For 6DOF Robotic Arm” →

Printed Robotic Arm Pumps Up With Brushless Motors

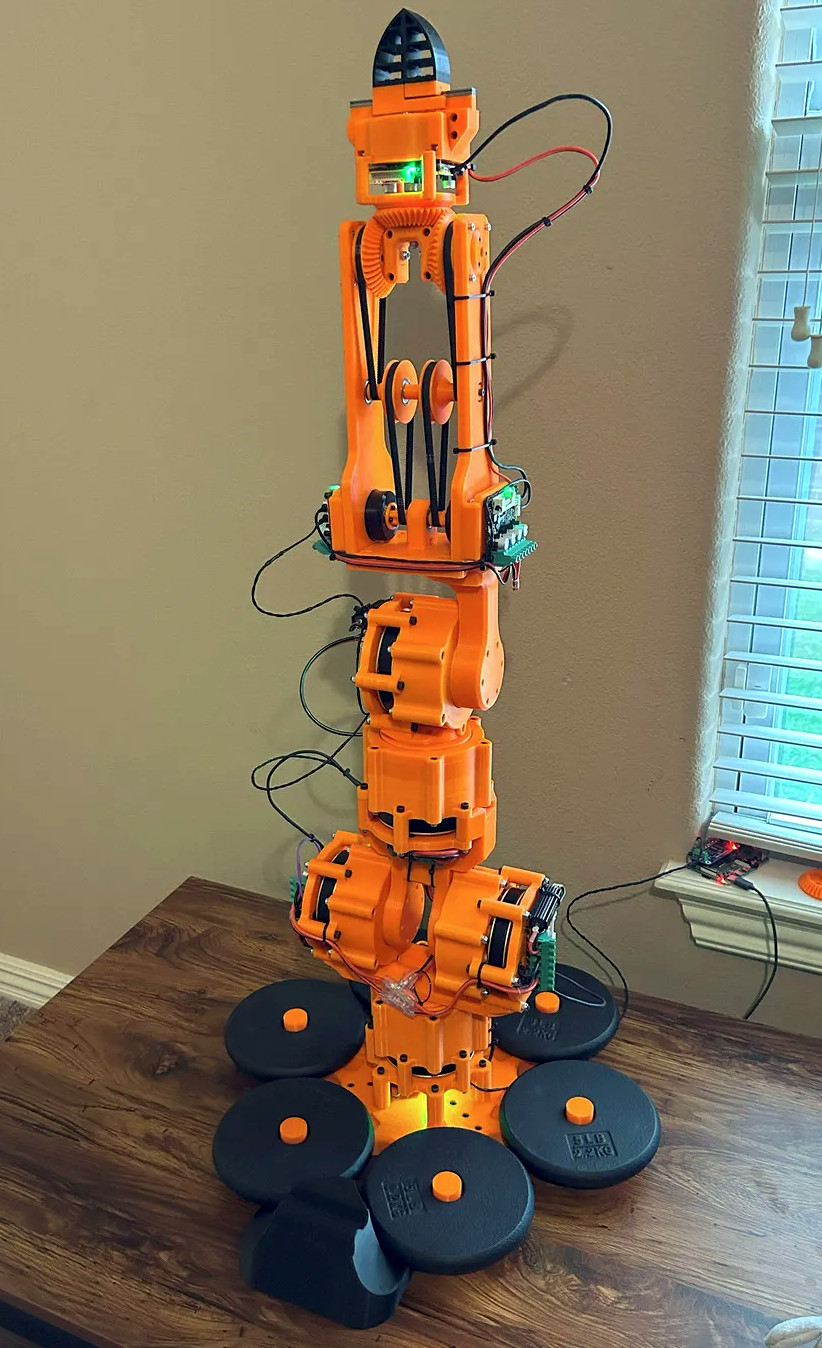
[JesseDarr] recently wrote in to tell us about their dynamic Arm for Robitc Mischief (dARM), a mostly 3D printed six degrees of freedom (6DOF) robotic arm that’s designed to be stronger and more capable than what we’ve seen so far from the DIY community.

The secret? Rather than using servos, dARM uses brushless DC (BLDC) motors paired with ODrive S1 controllers. He credits [James Bruton] and [Skyentific] (two names which regular Hackaday readers are likely familiar with) for introducing him to not only the ODrive controllers, but the robotics applications for BLDCs in the first place.

dARM uses eight ODrive controllers on a CAN bus, which ultimately connect up to a Raspberry Pi 4B with a RS485 CAN Hat. The controllers are connected to each other in a daisy chain using basic twisted pair wire, which simplifies the construction and maintenance of the modular arm.

As for the motors themselves, the arm uses three different types depending on where they are located, with three Eaglepower 8308 units for primary actuators, a pair of GB36-2 motors in the forearm, and finally a GM5208-24 for the gripper. Together, [JesseDarr] says the motors and gearboxes are strong enough to lift a 5 pound (2.2 kilogram) payload when extended in a horizontal position.

The project’s documentation includes assembly instructions for the printed parts, a complete Bill of Materials, and guidance on how to get the software environment setup on the Raspberry Pi. It’s not exactly a step-by-step manual, but it looks like there’s more than enough information here for anyone who’s serious about building a dARM for themselves.

If you’d like to start off by putting together something a bit easier, we’ve seen considerably less intimidating robotic arms that you might be interested in.

Continue reading “Printed Robotic Arm Pumps Up With Brushless Motors” →

Explore Neural Radiance Fields In Real-time, Even On A Phone

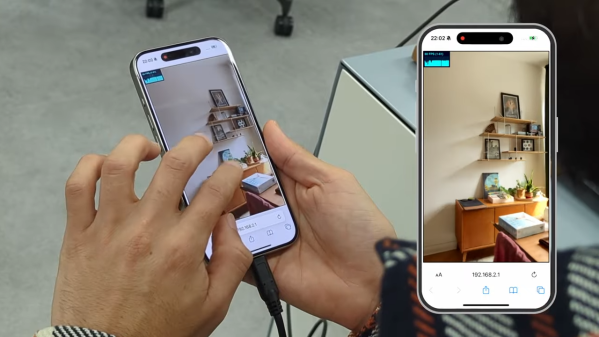
Neural Radiance Fields (NeRF) is a method of reconstructing complex 3D scenes from sparse 2D inputs, and the field has been growing by leaps and bounds. Viewing a reconstructed scene is still nontrivial, but there’s a new innovation on the block: SMERF is a browser-based method of enabling full 3D navigation of even large scenes, efficient enough to render in real time on phones and laptops.

Don’t miss the gallery of demos which will run on anything from powerful desktops to smartphones. Notable is the distinct lack of blurry, cloudy, or distorted areas which tend to appear in under-observed areas of a NeRF scene (such as indoor corners and ceilings). The technical paper explains SMERF’s approach in more detail.

NeRFs as a concept first hit the scene in 2020 and the rate of advancement has been simply astounding, especially compared to demos from just last year. Watch the short video summarizing SMERF below, and marvel at how it compares to other methods, some of which are themselves only months old.

Continue reading “Explore Neural Radiance Fields In Real-time, Even On A Phone” →

Haptick: The Strain Gauge Based 6DoF Controller

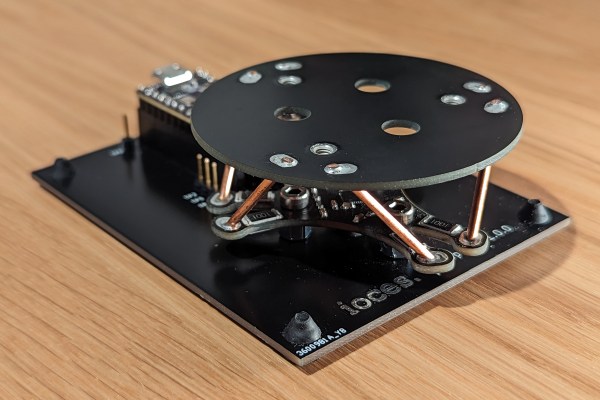
Six degrees of freedom (6DoF) controllers are used for manipulating an object in a CAD or 3d modeling program and are often called spacemice. You can twist it, push it, and even bop it. Most work with optical encoders, shining an LED through a slit to some form of photodetector on the other side. [Matthew Schubert] wanted to make his own spacemouse, but had some new ideas of how to go about it. His two-part project, dubbed haptic, focuses on measuring the forces, not the displacement.

He decided to try thick-film resistors as strain gauges and revisit load cells and proper strain gauges later. The actual structure quickly converged on the Stewart Platform, formed from three custom PCBs. A base to sit on, a knob for the top, and a middle board designed to take the strain with SMD resistors. A Teensy 3.2 talks to the ADS131M06 ADC and streams 4k samples per second to the host computer via serial. For prototyping, the calculations were done on the PC. Continue reading “Haptick: The Strain Gauge Based 6DoF Controller” →

Spaceballs Get Serialized

As much as we’d love a TV show version of the cult classic movie, we’re talking about a different kind of Spaceball. While there have been many iterations, [Evan] had a Spaceball built by a company known as Spacetec in 1991 and rebranded by HP. Being an older peripheral, he used the Orbotron 9001, a converter from RS232 serial to USB, to interface his Spaceball with modern devices.

The spaceball was one of the first 6 degrees of freedom controllers, useful for CAD and some games that supported it. It’s famous for being involved in the NASA Mars Pathfinder mission as it was used to control the Sojourner rover. In addition to the perfect orb, it also features eight handy buttons.

The Orbotron is a USB-capable microcontroller (Atmel SAMD21) designed to support the Spaceball 360, 4000, and 5000 series. Ultimately, after tinkering with the code to support the 2003 and 3003 Spaceballs, he had some reasonably usable with some rough edges. For example, acceleration curves still need tweaking, and going too fast can get you stuck. The downside was the rubber coating on the ball that had degraded over the years, making it horrendously sticky.

All the code changes are on GitHub. We’d love to see more spacemice integrated into things, like this ergonomic keyboard. Or even an open-source version of a spacemouse. After the break, we have a video of [Adafruit] showing a Spaceball 2003 working with a serial adapter.

Continue reading “Spaceballs Get Serialized” →