Hackaday Links Column Banner

Hackaday Links: May 4, 2025

By now, you’ve probably heard about Kosmos 482, a Soviet probe destined for Venus in 1972 that fell a bit short of the mark and stayed in Earth orbit for the last 53 years. Soon enough, though, the lander will make its fiery return; exactly where and when remain a mystery, but it should be sometime in the coming week. We talked about the return of Kosmos briefly on this week’s podcast and even joked a bit about how cool it would be if the parachute that would have been used for the descent to Venus had somehow deployed over its half-century in space. We might have been onto something, as astrophotographer Ralf Vanderburgh has taken some pictures of the spacecraft that seem to show a structure connected to and trailing behind it. The chute is probably in pretty bad shape after 50 years of UV torture, but how cool is that?

Parachute or not, chances are good that the 495-kilogram spacecraft, built to not only land on Venus but to survive the heat, pressure, and corrosive effects of the hellish planet’s atmosphere, will at least partially survive reentry into Earth’s more welcoming environs. That’s a good news, bad news thing: good news that we might be able to recover a priceless artifact of late-Cold War space technology, bad news to anyone on the surface near where this thing lands. If Kosmos 482 does manage to do some damage, it won’t be the first time. Shortly after launch, pieces of titanium rained down on New Zealand after the probe’s booster failed to send it on its way to Venus, damaging crops and starting some fires. The Soviets, ever secretive about their space exploits until they could claim complete success, disavowed the debris and denied responsibility for it. That made the farmers whose fields they fell in the rightful owners, which is also pretty cool. We doubt that the long-lost Kosmos lander will get the same treatment, but it would be nice if it did.
Continue reading “Hackaday Links: May 4, 2025” →

Hackaday Links Column Banner

Hackaday Links: April 27, 2025

Looks like the Simpsons had it right again, now that an Australian radio station has been caught using an AI-generated DJ for their midday slot. Station CADA, a Sydney-based broadcaster that’s part of the Australian Radio Network, revealed that “Workdays with Thy” isn’t actually hosted by a person; rather, “Thy” is a generative AI text-to-speech system that has been on the air since November. An actual employee of the ARN finance department was used for Thy’s voice model and her headshot, which adds a bit to the creepy factor.

Continue reading “Hackaday Links: April 27, 2025” →

China Hosts Robot Marathon

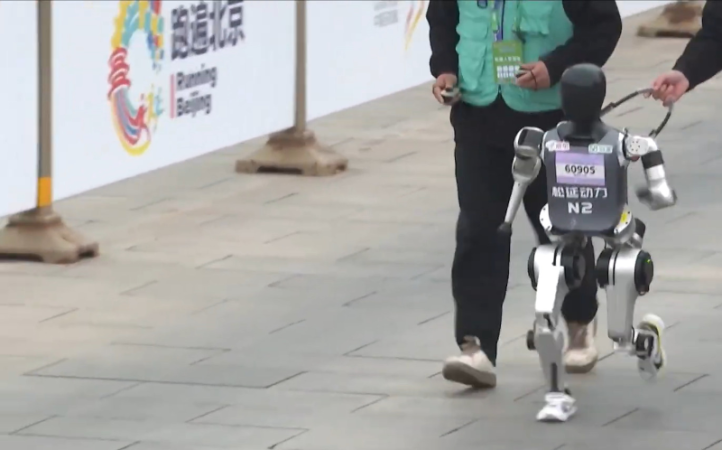
China played host to what, presumably, was the world’s first robot and human half-marathon. You can check out the action and the Tiangong Ultra robot that won in the video below. The event took place in Beijing and spanned 21.1 km. There was, however, a barrier between lanes for humans and machines.

The human rules were the same as you’d expect, but the robots did need a few concessions, such as battery swap stops. The winning ‘bot crossed the finish line in just over 160 minutes. However, there were awards for endurance, gait design, and design innovation.

Continue reading “China Hosts Robot Marathon” →

Forget Propellers, Embrace Tentacle-based Locomotion

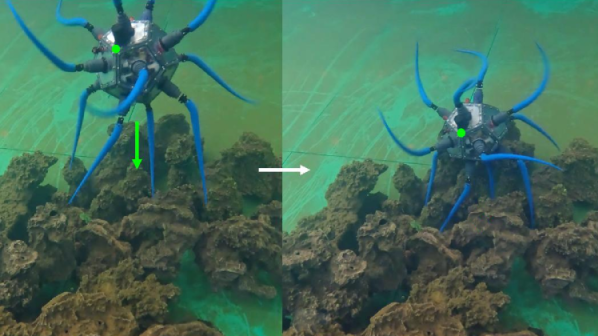
Underwater robots face many challenges, not least of which is how to move around. ZodiAq is a prototype underwater soft robot (link is to research paper) that takes an unusual approach to this problem: multiple flexible appendages. The result is a pretty unconventional-looking device that can not only get around effectively, but can do so without disturbing marine life.

ZodiAq sports a soft flexible appendage from each of its twelve faces, but they aren’t articulated like you might think. Despite this, the device can crawl and swim.

With movement inspired by bacterial flagella, ZodiAq moves in an unusual but highly controllable way.

Each soft appendage is connected to a motor, which rotates the attached appendage. This low-frequency but high-torque rotation, combined with the fact that each appendage has a 45° bend to it, has each acting as a rotor. Rotation of the appendages acts on the surrounding fluid, generating thrust. When used together in the right way, these appendages allow the unit to move in a perfectly controllable manner.

This locomotion method is directly inspired by the swimming gait of bacterial flagella, which the paper mentions are regarded as the only example of a biological “wheel”.

How fast can it go? The prototype covers a distance of two body lengths every fifteen seconds. True, it’s no speed demon compared to a propeller, but it doesn’t disturb marine life or environments as it moves around. This method of movement has a lot going for it. It’s adaptable and doesn’t use all twelve appendages at once; so there’s redundancy built in. If some get damaged or go missing, it can still move, just slower.

ZodiAq‘s design strikes us as a very accessible concept, should any aspiring marine robot hackers wish to give it a shot. We’ve seen other highly innovative and beautiful underwater designs as well, like body-length undulating fins and articulated soft arms.

We do notice that since it lacks a “front” — it might be a challenge to decide how to mount something like a camera. If you have any ideas, share them in the comments.

Disney’s Bipedal, BDX-Series Droid Gets The DIY Treatment

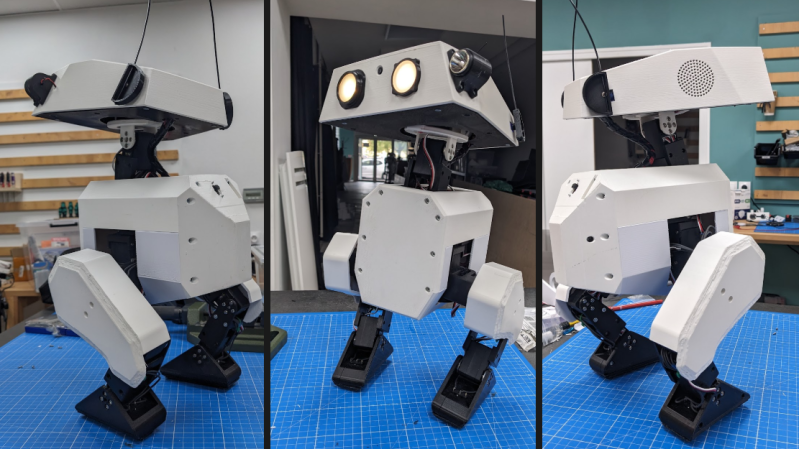
[Antoine Pirrone] and [Grégoire Passault] are making a DIY miniature re-imagining of Disney’s BDX droid design, and while it’s still early, there is definitely a lot of progress to see. Known as the Open Duck Mini v2 and coming in at a little over 40 cm tall, the project is expected to have a total cost of around 400 USD.

The inner workings of Open Duck Mini use a Raspberry Pi Zero 2W, hobby servos, and an absolute-orientation IMU.

Bipedal robots are uncommon, and back in the day they were downright rare. One reason is that the state of controlled falling that makes up a walking gait isn’t exactly a plug-and-play feature.

Walking robots are much more common now, but gait control for legged robots is still a big design hurdle. This goes double for bipeds. That brings us to one of the interesting things about the Open Duck Mini v2: computer simulation of the design is playing a big role in bringing the project into reality.

It’s a work in progress but the repository collects all the design details and resources you could want, including CAD files, code, current bill of materials, and links to a Discord community. Hardware-wise, the main work is being done with very accessible parts: Raspberry Pi Zero 2W, fairly ordinary hobby servos, and an BNO055-based absolute orientation IMU.

So, how far along is the project? Open Duck Mini v2 is already waddling nicely and can remain impressively stable when shoved! (A “testing purposes” shove, anyway. Not a “kid being kinda mean to your robot” shove.)

Check out the videos to see it in action, and if you end up making your own, we want to hear about it, so remember to send us a tip!

Simple Robot Assembled From E-Waste Actually Looks Pretty Cool

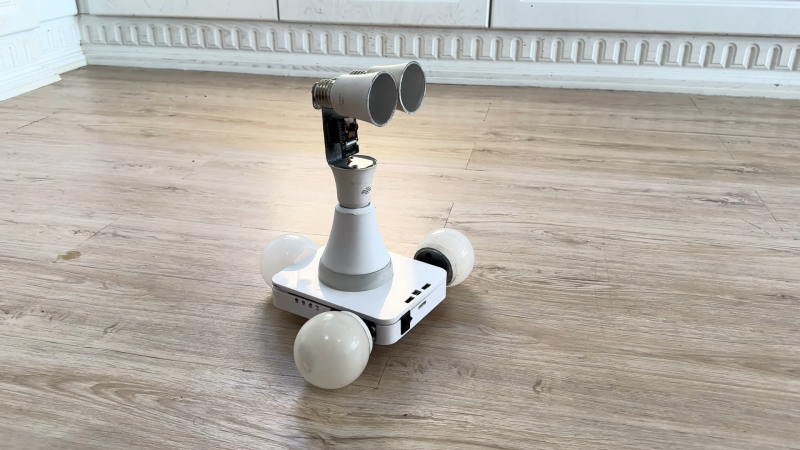
If you’re designing a robot for a specific purpose, you’re probably ordering fresh parts and going with a clean sheet design. If you’re just building for fun though, you can just go with whatever parts you have on hand. That’s how [Sorush Moradisani] approached building Esghati—a “robot made from garbage.”

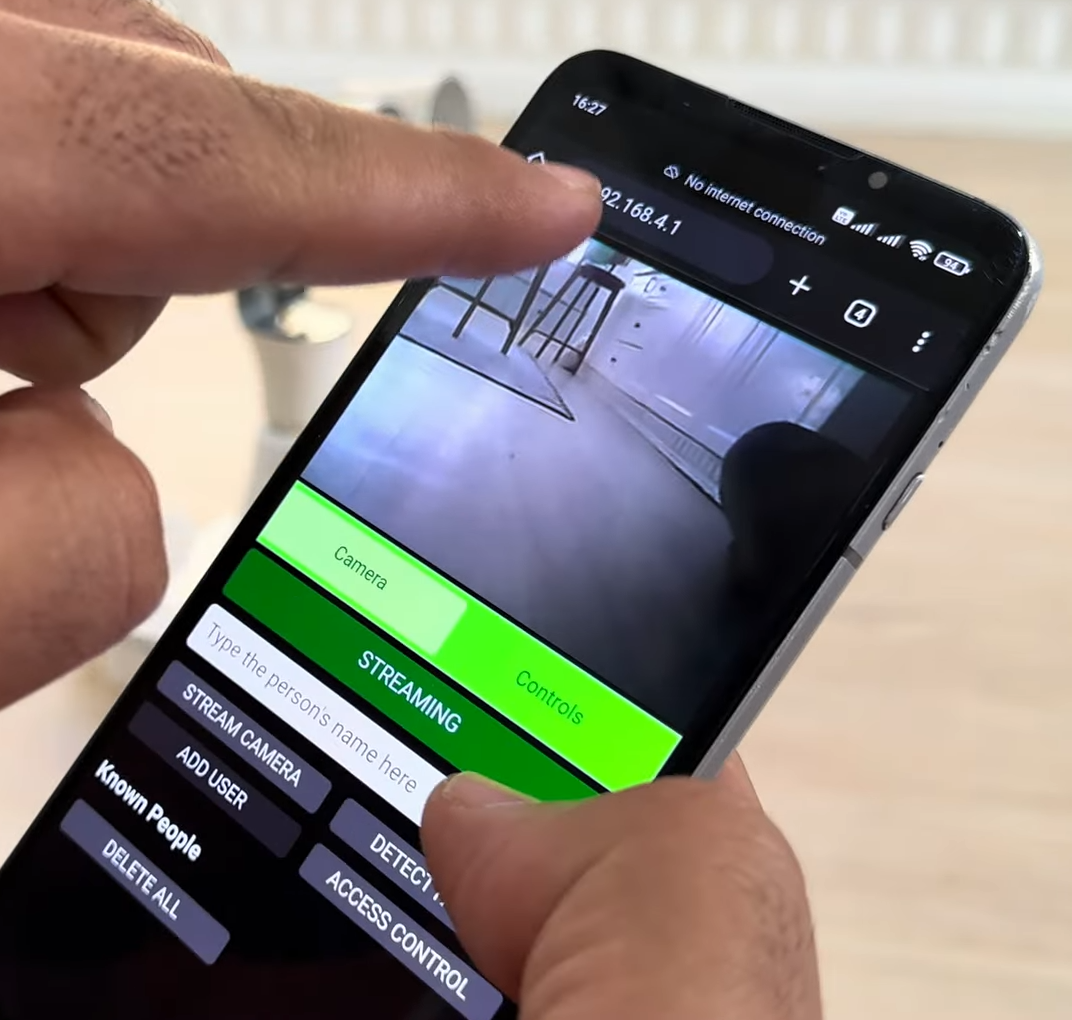
Remote viewing made easy.

The body of the robot is an old Wi-Fi router that was stripped clean, with the antenna left on for a classic “robot” look. The wheels are made out of old diffusers cut off of LED lamps. Two servos are used to drive the wheels independently, allowing the robot to be steered in a rudimentary tank-style fashion. Power is courtesy of a pair of 18650 lithium-ion cells. The brains of the robot is an ESP32-CAM—a microcontroller board which includes a built-in camera. Thanks to its onboard Wi-Fi, it’s able to host its own website that allows control of the robot and transmits back pictures from the camera. The ESP32 cam itself is mounted on the “head” on the robot for a good field of view. Meanwhile, it communicates with a separate Arduino Nano which is charged with generating pulses to run the drive servos. Code is on Github for the curious.

It’s not a complicated robot by any means—it’s pretty much just something you can drive around and look through the camera, at this stage. Still, it’s got plenty of onboard processing power and you could do a lot more with it. Plus, the wireless control opens up a lot of options. With that said, you’d probably get sick of the LED bulb wheels in short order—they offer precious little grip on just about any surface. Really, though, it just goes to show you how a bit of junk e-waste can make a cute robot—it almost has Wall-E vibes. Video after the break.

Continue reading “Simple Robot Assembled From E-Waste Actually Looks Pretty Cool” →

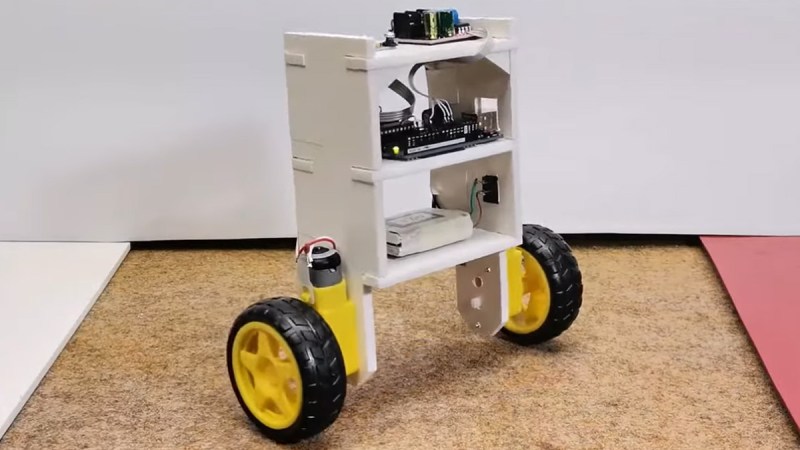
self-stabilizing robot on tabletop

Taming The Wobble: An Arduino Self-Balancing Bot

Getting a robot to stand on two wheels without tipping over involves a challenging dance with the laws of physics. Self-balancing robots are a great way to get into control systems, sensor fusion, and embedded programming. This build by [mircemk] shows how to make one with just a few common components, an Arduino, and a bit of patience fine-tuning the PID controller.

At the heart of the bot is the MPU6050 – a combo accelerometer/gyroscope sensor that keeps track of tilt and movement. An Arduino Uno takes this data, runs it through a PID loop, and commands an L298N motor driver to adjust the speed and direction of two DC motors. The power comes from two Li-ion batteries feeding everything with enough juice to keep it upright. The rest of the magic lies in the tuning.

PID (Proportional-Integral-Derivative) control is what makes the robot stay balanced. Kp (proportional gain) determines how aggressively the motors respond to tilting. Kd (derivative gain) dampens oscillations, and Ki (integral gain) helps correct slow drifts. Set them wrong, and your bot either wobbles like a confused penguin or falls flat on its face. A good trick is to start with only Kp, then slowly add Kd and Ki until it stabilizes. Then don’t forget to calibrate your MPU6050; each sensor has unique offsets that need to be compensated in the code.

Once dialed in, the result is a robot that looks like it defies gravity. Whether you’re hacking it for fun, turning it into a segway-like ride, or using it as a learning tool, a balancing bot is a great way to sharpen your control system skills. For more inspiration, check out this earlier attempt from 2022, or these self-balancing robots (one with a little work) from a year before that. You can read up on [mircemk]’s project details here.