Lillith Tells Your Future

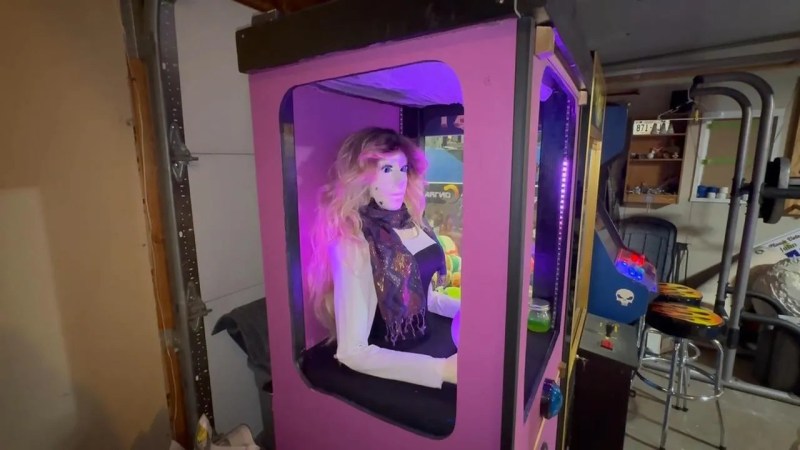
Maybe you are old enough to remember Zoltar in an arcade, or perhaps you’re just a fan of the movie Big. Either way, maybe you’d like to build an animated fortune teller. [Oh Well Why Not] did just that and gives you a roadmap for you to make your own. It took four months to build, but with the road already mapped, you can probably do it in less. Then again, who can predict the future?

The fortune teller, Lillith, uses servos and some voice generation to provide the same experience. If you dare to hit the button, you’ll get a glimpse into your future that’s at least as good as a fortune cookie from your local takeaway place.

Lillith doesn’t hide behind windows since it isn’t in a public venue, but if you were going to put it out in the wild, you’d probably want to encase it a little better. While waiting, the servos provide some small animations to attract the next user.

If you remember Bullwinkle more fondly than Zoltan, you might prefer this project.

Continue reading “Lillith Tells Your Future” →

Hackaday Europe 2026: Outdoors With Robots

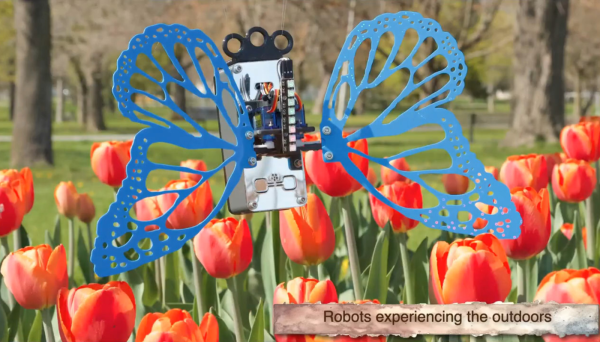
Erin Kennedy has been building robots for over a decade now, with a focus on smaller bots that interact with, or maybe even clean up, the outdoor environment. Still other bots are made to interact with people, and when the people are outside in the park, that’s where your robot needs to go.

Whatever the reason, Erin’s talk at Hackaday Europe 2026 is an invitation to take your projects out into the outdoors. But the great wide world outside of your lab is not necessarily the most friendly place for a little bot, and the other half of this talk is about practical design tips and lessons learned to help it survive. Continue reading “Hackaday Europe 2026: Outdoors With Robots” →

Robotic Screw And Bolt Sorter Seeks A New Challenge

As someone who disassembles and repairs hardware, [Aad] eventually ended up with a huge collection of mixed bolts and screws. This led to creating the automatic bolt and screw sorting system you see here, although in a way it is just a proof of concept. Bolts and screws happen to be a useful application for now, but the system is capable of sorting just about any small objects.

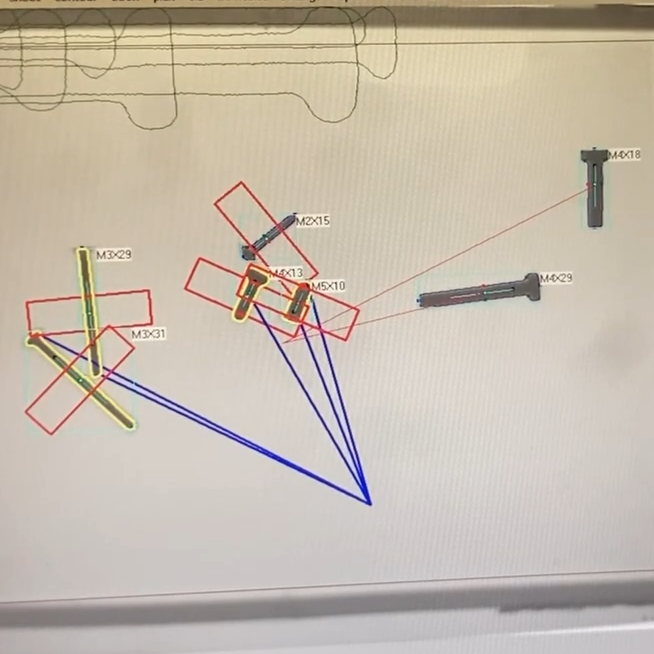
A bit of machine vision detects the size and shape of each object. Weight can also be measured.

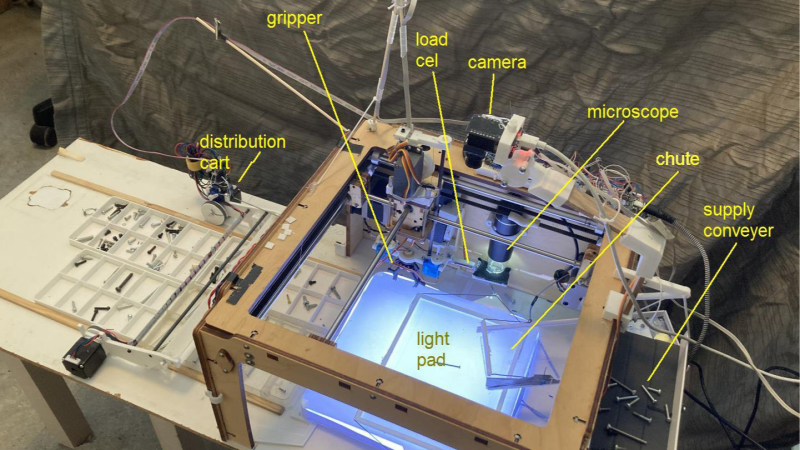
Mixed pieces go onto a large conveyor belt, shown on the right. This feeds a few screws at a time down a chute, where they roll onto an illuminated platform.

Above the lit platform is a camera, and machine vision is used to detect the size and shape and orientation of each screw. A robotic gripper on a gantry picks the screws up one by one — separating them first if they happened to clump together — and places each in a drop-off cart. The cart drops the object into a receptacle with its brethren, making sure similar ones are grouped together. Watch it in action in the video, embedded below the page break.

It’s a great build that shows fancy components aren’t necessary for good results. Servos and steppers are controlled with an ESP32-WROOM board, and a piezo sensor detects screws falling off the conveyor. Some of you may have noticed a repurposed Ultimaker 3D printer serving as the bulk of the system, its hot end having been replaced with a gripper that can raise and lower. The overhead camera is an ESP32-CAM adapted to accept M12 lenses so it can focus on the platform.

There’s one more feature worth mentioning — the system also has the ability to measure the weight of a picked object by placing it onto a moveable inspection platform, which can optionally put it under a USB microscope for a closer look. Everything is controlled by a nearby PC, so there’s a lot of flexibility built into the system.

We suppose that once all the screws and bolts in a shop are sorted, it only makes sense to sort all the nuts. Are there other objects besides screws and bolts that would be useful to sort with a system like this? If you have any ideas, don’t keep them to yourself! [Aad] would love to hear your comments and ideas, so share them below.

Continue reading “Robotic Screw And Bolt Sorter Seeks A New Challenge” →

To Build More Believable Bots, Simulate The Neurochemistry

Giving machines the ability to communicate nonverbally has real value, and [Drew Smith] clearly thinks your robot deserves better than an emoji. He shared a very interesting approach with his project Kindalive.

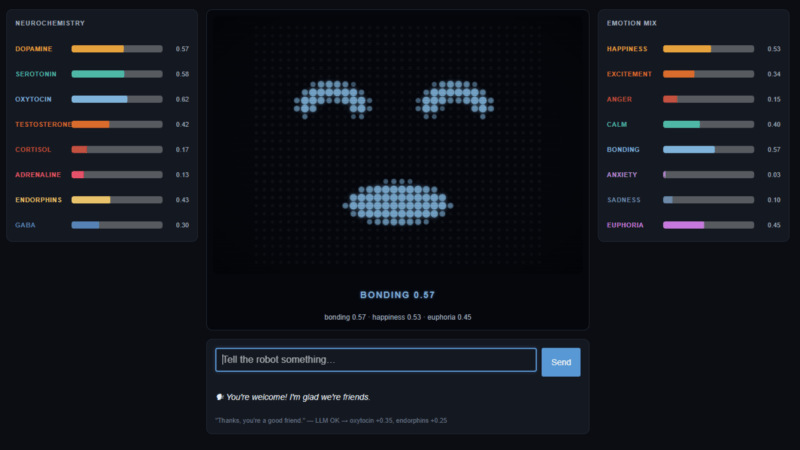
Kindalive is a simulated dot-matrix robot face that responds believably to input text, modeling and expressing both short-term and long-term moods. It’s pure Python and modular enough to invite using it elsewhere, but that’s not the really interesting part.
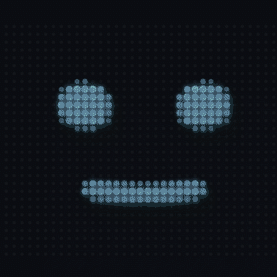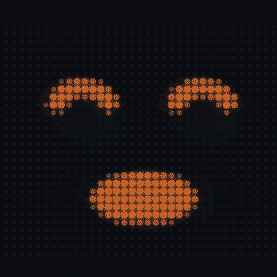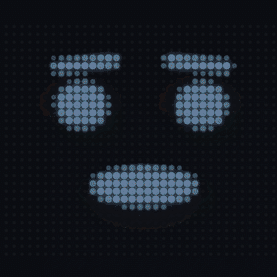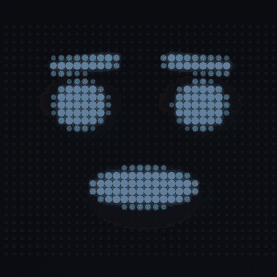
What sets [Drew]’s project apart is the way he models eight key neurochemicals (including dopamine and cortisol) as the foundation from which to derive emotional states. That’s an approach we certainly haven’t seen before.

Conventional sentiment analysis uses a large language model (LLM) to apply discrete labels to communication, but Kindalive doesn’t do that. It even goes so far as to model the decay and interplay between its simulated neurochemicals to derive emotional states on the fly. It’s more fluid and organic, and reflects both short-term and long-term mood changes.

Physical representation of the emotional mix is done by altering twelve key facial movements (brow raise, lip corner pull, mouth open, and others of that nature) known as the Facial Action Coding System (FACS). These twelve elements combine to express emotion nonverbally with facial expressions. It’s what drives the simulated dot-matrix robot face seen in the image above, and could easily be used to drive a real LED matrix, or servos on an animatronic face.

Much of communication is nonverbal. Humans even weigh nonverbal higher when there’s a mismatch between the content of verbal and nonverbal communication. So, there’s clear value in having robots able to express themselves as such.

Importantly, a realistic and human-like face is entirely unnecessary — something every Star Wars fan already knows. Cartoon eyes and basic sounds are enough to make robots easier to relate to and work with, even if blinking is also important but hard to get just right.

Reachy Mini Desktop Robot Gets All-local, Conversational AI

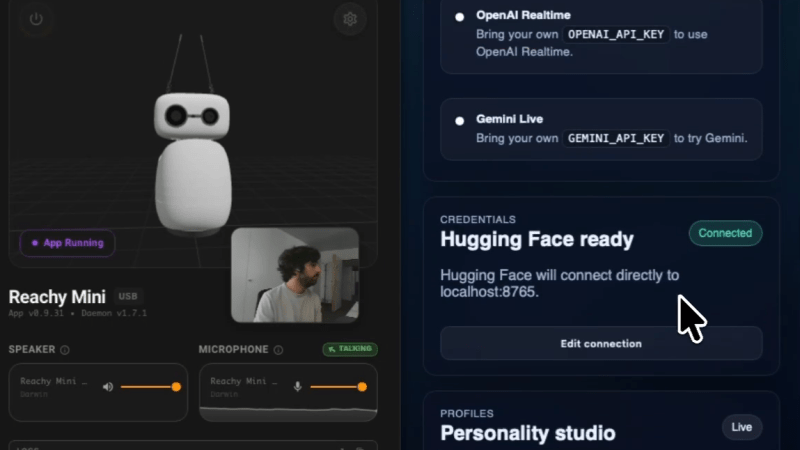
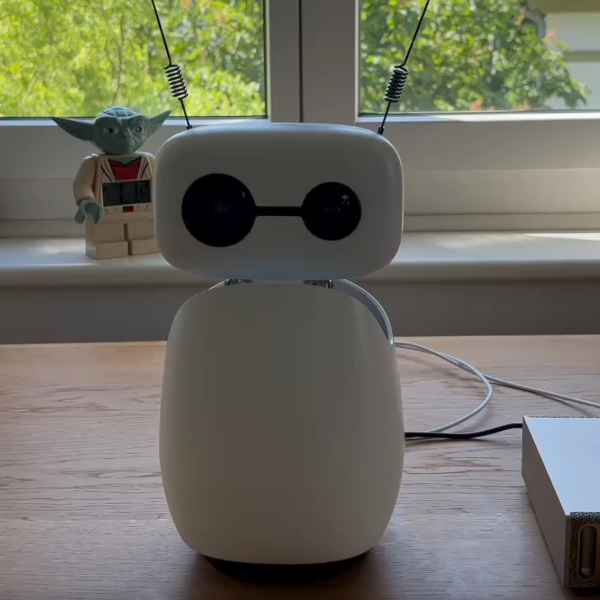
Reachy Mini is a limbless desktop robot from Hugging Face made for human interaction experiments, and to give you an idea of what it’s like is a guide on how to implement expressive, local conversational AI complete with head movements and antenna wiggles. It’s conversational in the sense that it aims to feel natural, with low-latency responses and the ability to interrupt, with everything running on local hardware if one so wishes.

Reachy Mini can use remote services, or work in tandem with a desktop machine or laptop.

The software stack is essentially VAD (voice activity detection) → STT (speech-to-text) → LLM (large language model) → TTS (text-to-speech) which allows users to tweak things to their liking, or independently swap or modify pieces as things evolve.

This also allows users to tailor the services to match whatever their hardware is capable of. For example, one could easily use a frontier AI model via remote API for the LLM while keeping everything else local.

The local models in the example configuration are effective and relatively modest (Qwen3-4B-Instruct for the LLM, and even smaller models for the rest) but it’s nice to have the option to offload parts to remote providers if necessary.

Reachy Mini looked very interesting when it was launched as a kit last year, and since then Hugging Face has built up an impressive software suite and infrastructure through which users can easily share their applications. If you’re curious, there’s a simulator for Reachy Mini which should give you an idea of what it can do.

3D Printed Robot Arm Built For Learning Purposes

If you want to work with robots you can do all sorts of learning with software and simulation, but nothing quite beats getting to grips with real machinery. That was the motivation for [James Gullberg] to build this impressive robot arm. 

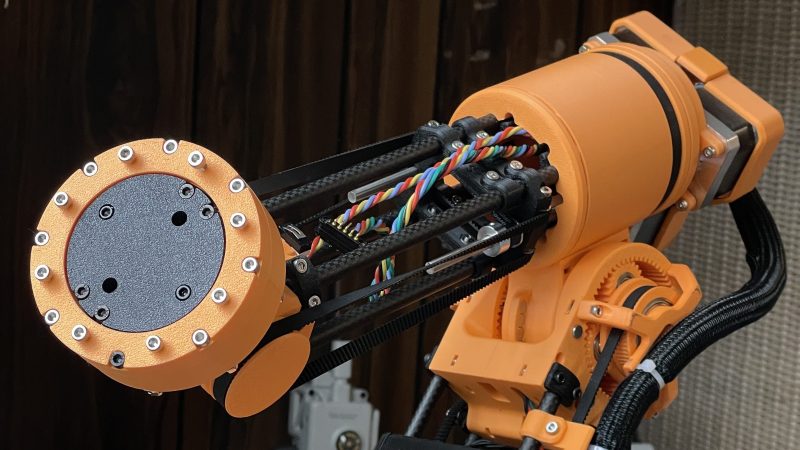
Featuring six degrees of freedom, the robot arm is mostly constructed of 3D printed components. This let [James] experiment with a wide variety of joint and reducer designs for the sake of learning and investigation. The base of the robot uses a fairly conventional planetary gear drive, while shoulder and elbow joints rely on split-ring planetary gearboxes to allow for high torque density with regards to size. [James] implemented a neat sensing technique here, integrating alternating magnets into the output ring gear which are monitored via a magnetic encoder. The wrist joint switches things up again, running via an inverted belt differential.

Running the show is an STM32 microcontroller, which talks to all the encoders, communicates with a Raspberry Pi over CAN bus, and handles all the necessary PID control loops and step generation for the drive motors. The plan is to run higher-level control on the Raspberry Pi which will run a ROS 2-based software stack. Already, the various joints look smooth and impressive in motion.

If you’re looking to learn about robot arms, you really can’t beat building one. We’ve featured a few projects along these lines before. Most of them aren’t exactly production-line ready, but they will teach you a ton about control, motion planning, and all sorts of associated skills. That experience can be invaluable if you intend to work with robots in industry.

Continue reading “3D Printed Robot Arm Built For Learning Purposes” →

Let Hauntimator Steer Your Next Animatronic Display

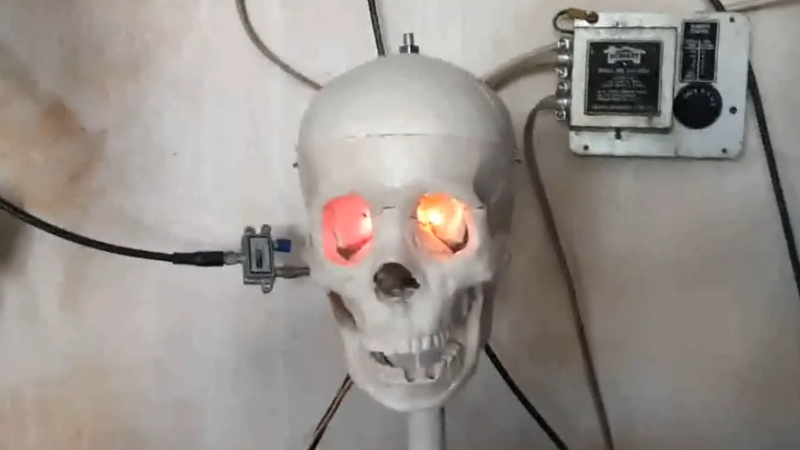
Animatronic displays aren’t just for Halloween, and hackers today have incredible access to effective, affordable parts with which to make spectacles of light, sound, and movement. But the hardware is only half the battle. Getting everything synchronized properly can be a daunting task, so get a head start on your next holiday display with the Hauntimator by [1031-Systems].

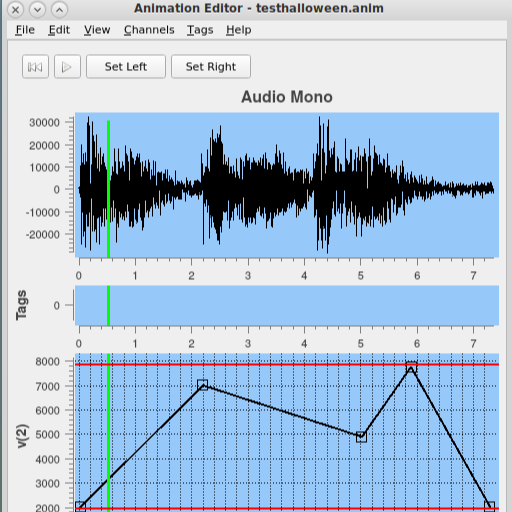
Synchronizing control channels to audio is at the heart of solid animations.

After all, synchronizing movements, sound, and light by trial and error can get tiresome even in small setups. Anyone who makes such a display — and contemplates doing it twice — tends to quickly look into making things modular.

At its heart, Hauntimator works with a Raspberry Pi Pico-based controller board. The GUI makes it easy to create control channels for different hardware (for example, doing things like moving servos) and synchronize them to audio. Once an animation is validated, it gets uploaded to the control board where it runs itself. It’s open-source and designed to make plugins easy, so give it a look. There’s a video channel with some demonstrations of the tools that should fill in any blanks.

Intrigued by animatronics, but not sure where to begin? Get inspired by checking out this DIY set of servo-driven eyes, and see for yourself the benefits of smooth motor control for generating lifelike motion.