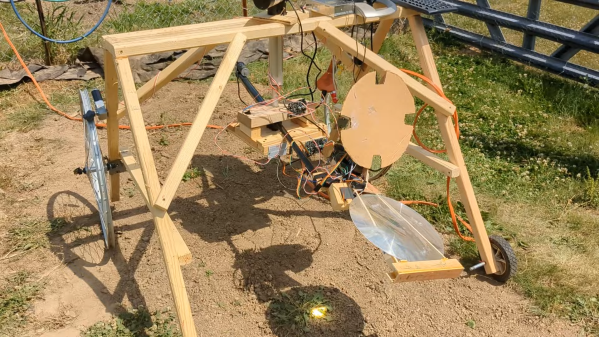
A wooden robot with a large fresnel lens in a sunny garden

Gardening Robot Uses Sunlight To Incinerate Weeds

Removing weeds is a chore few gardeners enjoy, as it typically involves long sessions of kneeling in the dirt and digging around for anything you don’t remember planting. Herbicides also work, but spraying poison all over your garden comes with its own problems. Luckily, there’s now a third option: [NathanBuildsDIY] designed and built a robot to help him get rid of unwanted plants without getting his hands dirty.

Constructed mostly from scrap pieces of wood and riding on a pair of old bicycle wheels, the robot has a pretty low-tech look to it. But it is in fact a very advanced piece of engineering that uses multiple sensors and actuators while running on a sophisticated software platform. The heart of the system is a Raspberry Pi, which drives a pair of DC motors to move the whole system along [Nathan]’s garden while scanning the ground below through a camera.
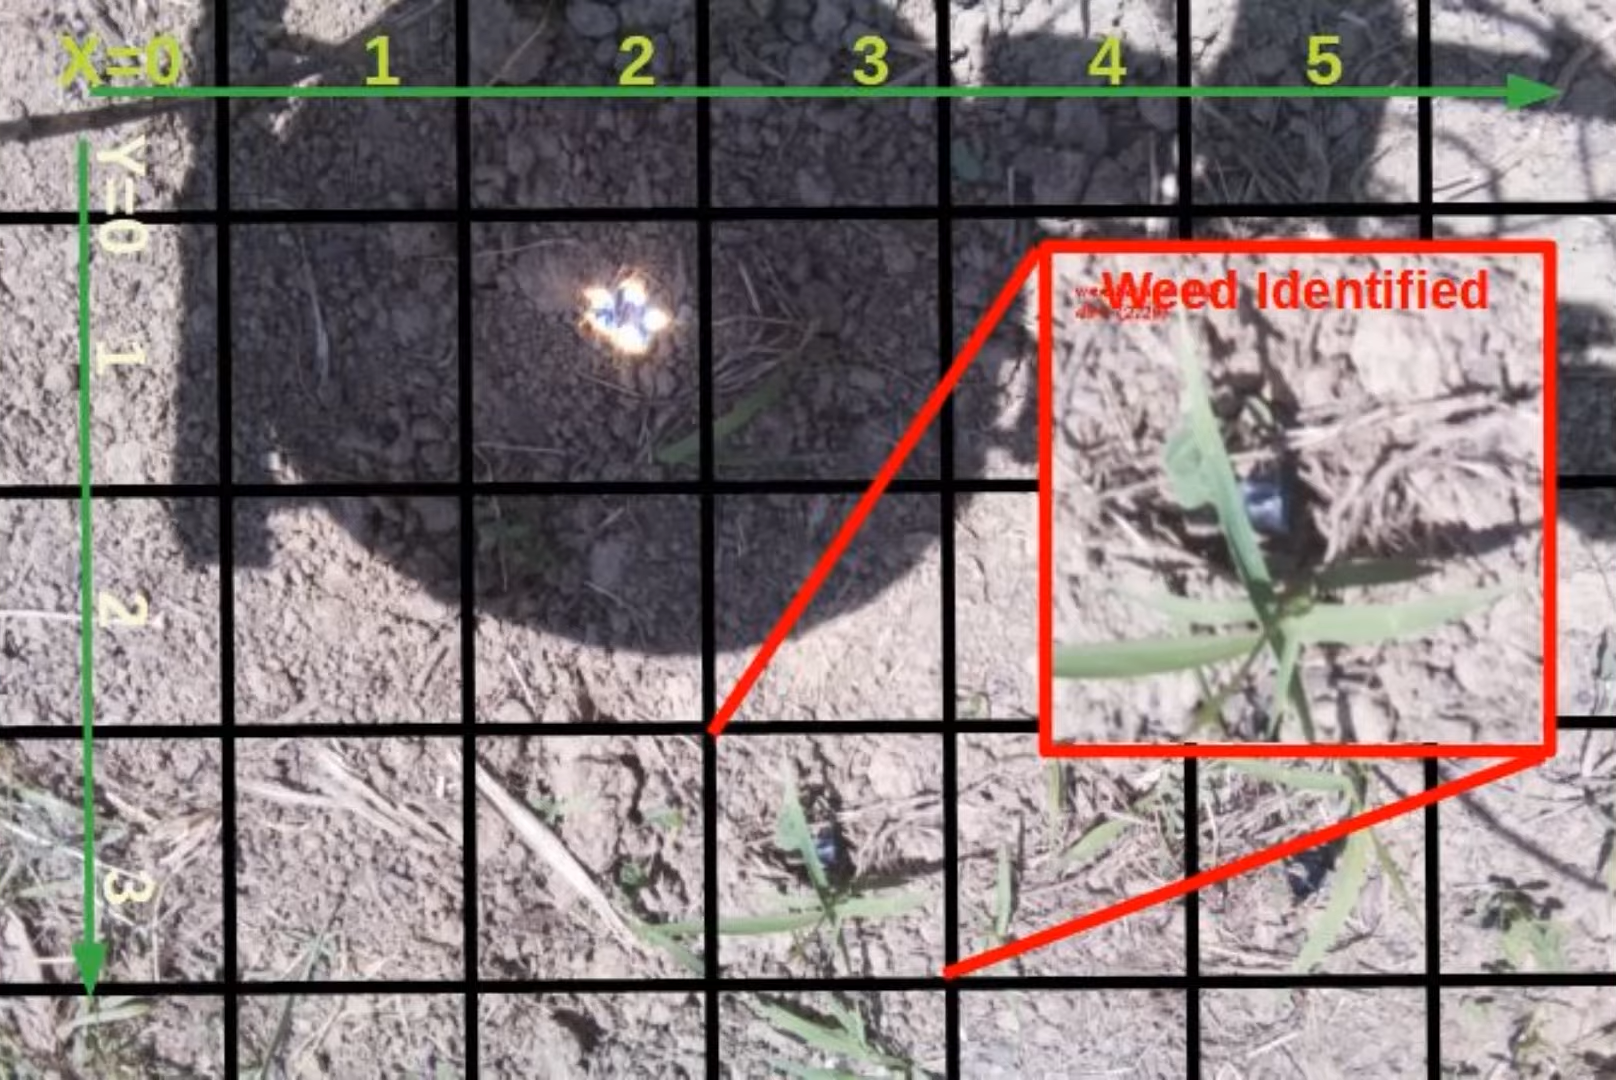
Machine vision software identifying a weed in a picture of garden soilThe Pi runs the camera’s pictures through a TensorFlow Lite model that can identify weeds. [Nathan] built this model himself by taking hundreds of pictures of his garden and manually sorting them into categories like “soil”, “plant” and “weed”. Once a weed has been detected, the robot proceeds to destroy it by concentrating sunlight onto it through a large Fresnel lens. The lens is mounted in a frame that can be moved in three dimensions through a set of servos. A movable lens cover turns the incinerator beam on or off.

Sunlight is focused onto the weed through a simple but clever two-step procedure. First, the rough position of the lens relative to the sun is adjusted with the help of a sun tracker made from four light sensors arranged around a cross-shaped cardboard structure. Then, the shadow cast by the lens cover onto the ground is observed by the Pi’s camera and the lens is focused by adjusting its position in such a way that the image formed by four holes in the lens cover ends up right on top of the target.

Once the focus is correct, the lens cover is removed and the weed is burned to a crisp by the concentrated sunlight. It’s pretty neat to see how well this works, although [Nathan] recommends you keep an eye on the robot while it’s working and don’t let it near any flammable materials. He describes the build process in full detail in his video (embedded below), hopefully enabling other gardeners to make their own, improved weed burner robots. Agricultural engineers have long been working on automatic weed removal, often using similar machine vision systems with various extermination methods like lasers or flamethrowers.

Continue reading “Gardening Robot Uses Sunlight To Incinerate Weeds”
Machine Vision Automates Trainspotting With Unique Full-Length Portraits

As hobbies go, trainspotting is just as valid a choice as any — we don’t judge. But it does present certain logistical challenges, such as having to be in visual range of a train to be able to spot it. There’s also the fact that trains are very large objects, and they tend to move very fast. What’s a railfan to do?

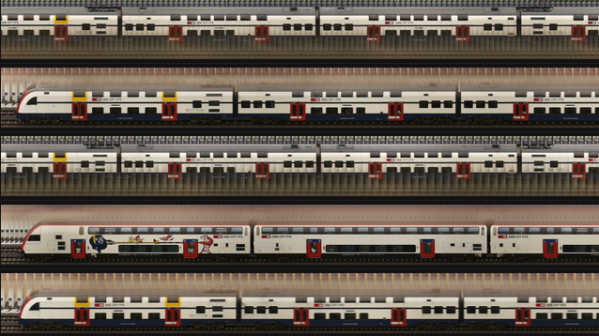
If you’re also technically minded, you might try building an automatic trainspotting bot like [jo-m] has. It looks like the hardware end of “Trainbot” is pretty simple since it has been tested on both x86 and Raspberry Pi, and supports both video4linux and Pi cam. The magic is in the software, which is able to detect a train entering the frame, record images, and then stitch them together into one long image. The whole thing is coded in Go and has some interesting bits, like a custom image patch mapping package.

Trainbot gives an unusual view of a train, one that most of us accustomed to watching a train pass at a crossing have never seen. By stitching small chunks of the train as it passes, Trainbot is able to show the entire train in a single image, which would be impossible to do except for being very, very far away from the track. [jo-m] also built a web interface for Trainbot where you can check out the comings and goings yourself. Each passing train’s image is accompanied by data like its velocity and acceleration, length of the train, and time of passage. There’s also a GIF of the original source video, which is pretty cool.

Here in the States, we don’t have a lot of passenger trains to spot, but we do have some really long freight trains. It’d be interesting to see how this works with a train that’s over a mile long; that would be quite an image. Looks like someone at least has the hardware in place to give it a try.

Air Hockey Solitaire

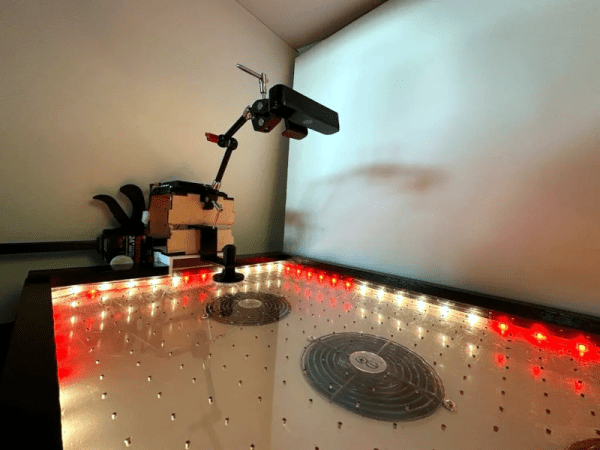
While air hockey is a fine amusement, it isn’t much fun if you can’t find someone to play against. Unless that is, you build a mini table with a robotic defender. [Vaib], [Nathan], and [Navish] can show you how. There is a video you can see below that shows two players using the table without the robot.

The project takes a bit of woodworking, as you might expect. You also have to drill 576 holes for the air to lift the puck. Some of the components are 3D printed in PETG, too. The automated defense uses a camera and relies on the fact that the puck is the only red thing on the table. A servo moves to intercept the incoming puck and return the shot. We were disappointed the video didn’t show the automated play.

We wondered if they had considered making a pair of the detachable robots and letting them play with each other. If you prefer football, the robot could probably adapt. We’ve seen other robot air hockey contenders, so maybe a better idea would be to build different robots and let them compete for a gold medal.

Continue reading “Air Hockey Solitaire”

Need To Pick Objects Out Of Images? Segment Anything Does Exactly That

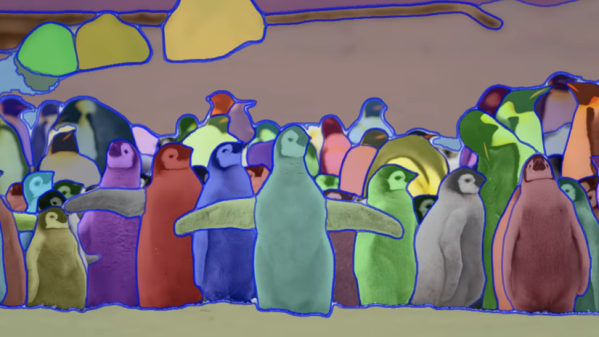
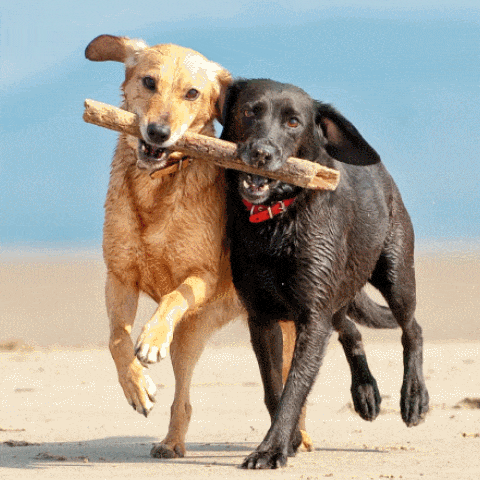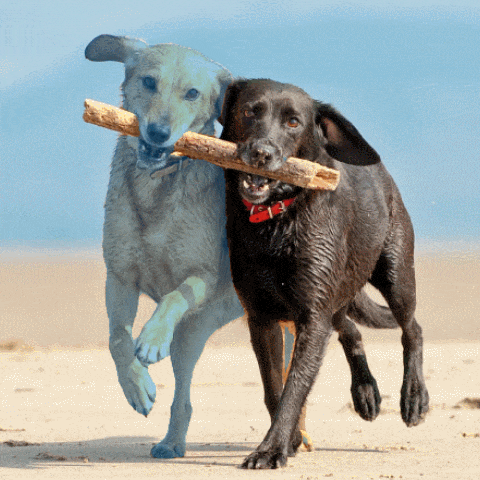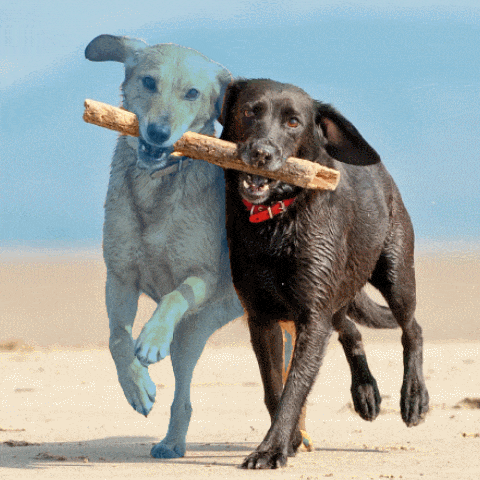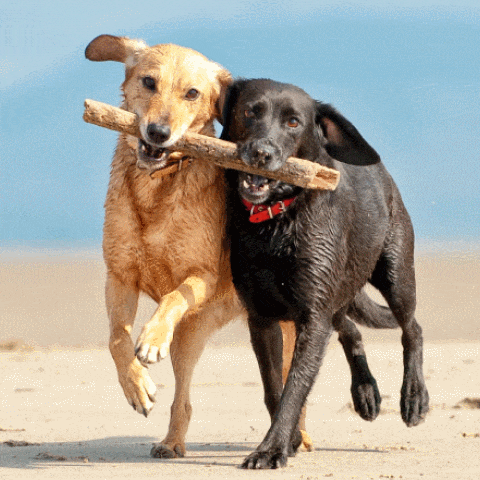
Segment Anything, recently released by Facebook Research, does something that most people who have dabbled in computer vision have found daunting: reliably figure out which pixels in an image belong to an object. Making that easier is the goal of the Segment Anything Model (SAM), just released under the Apache 2.0 license.

The online demo has a bank of examples, but also works with uploaded images.

The results look fantastic, and there’s an interactive demo available where you can play with the different ways SAM works. One can pick out objects by pointing and clicking on an image, or images can be automatically segmented. It’s frankly very impressive to see SAM make masking out the different objects in an image look so effortless. What makes this possible is machine learning, and part of that is the fact that the model behind the system has been trained on a huge dataset of high-quality images and masks, making it very effective at what it does.

Continue reading “Need To Pick Objects Out Of Images? Segment Anything Does Exactly That”

My Glasses Hear Everything I’m Not Saying!

There was a time when you saw someone walking down the street talking to no one, they were probably crazy. Now you have to look for a Bluetooth headset. But soon they may just be quietly talking to their glasses. Cornell University researchers have EchoSpeech which use sonar-like sensors in a pair of glasses to watch your lips and mouth move. From that data, they can figure out what you are saying, even if you don’t really say it out loud. You can see a video of the glasses below.

There are a few advantages to a method like this. For one thing, you can speak commands even in places where you can’t talk out loud to a microphone. There have been HAL 9000-like attempts to read lips with cameras, but this is power-hungry and video tends to be data intensive.

Continue reading “My Glasses Hear Everything I’m Not Saying!”

New Raspberry Pi Camera With Global Shutter

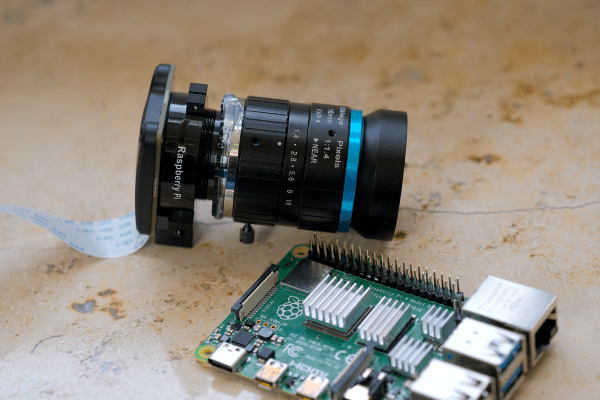
Raspberry Pi has just introduced a new camera module in the high-quality camera format. For the same $50 price you would shell out for the HQ camera, you get roughly eight times fewer pixels. But this is a global shutter camera, and if you need a global shutter, there’s just no substitute. That’s a big deal for the Raspberry Pi ecosystem.

Global vs Rolling

Most cameras out there today use CMOS sensors in rolling shutter mode. That means that the sensor starts in the upper left corner and rasters along, reading out exposure values from each row before moving down to the next row, and then starting up at the top again. The benefit is simpler CMOS design, but the downside is that none of the pixels are exposed or read at the same instant.

Continue reading “New Raspberry Pi Camera With Global Shutter”

Hackaday Links Column Banner

Hackaday Links: January 29, 2023

We’ve been told for ages that “the robots are coming for our jobs!” It’s true that we’ve seen robots capable of everything from burger flipping to bricklaying being demonstrated, and that’s certainly alarming for anyone employed in such trades. But now it looks like AI has set its sights set on the white-collar world, with the announcement that ChatGPT has managed a passing grade on a Wharton MBA exam.

For those not in the know, the University of Pennsylvania’s Wharton School of Business is in the major league of business schools; earning a Master’s in Business Administration from that august institution is no mean feat, and is likely to put the budding executive on a ballistic career trajectory. So the fact that ChatGPT could pass the exam is significant. But before you worry about a world in which our best and brightest business leaders are replaced with soulless automatons, relax. The exam presented to ChatGPT was just a final exam for one course, Operations Management, so it’s not like it aced everything an MBA is expected to know, and it took a lot of hints from a human helper to get it that far. It’s also reported that it made a lot of simple math mistakes, too, so maybe a Wharton MBA isn’t that much of a big deal after all.

Continue reading “Hackaday Links: January 29, 2023”