Drone Rescue Uses VHS Tape And Careful Planning

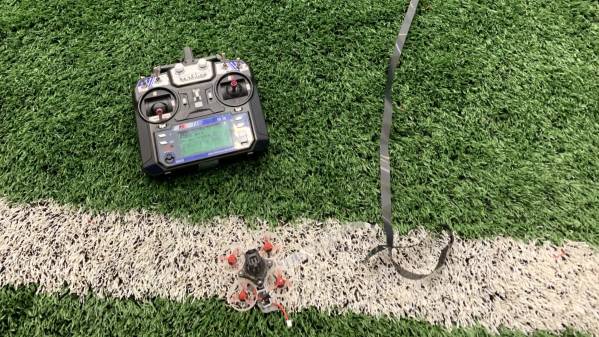
If you regularly fly your drones outdoors, you’ve probably worried about getting your pride and joy stuck in a big tree at some point. But flying indoors doesn’t guarantee you’ll be safe either, as [Scott Williamson] found out. He once got his tiny 65 mm Mobula 6HD quadcopter stuck in a roof beam at an indoor sports complex, and had to set about a daring rescue.

The first job was recon, with [Scott] sending up another drone to survey the situation. From there, he set about trying to prod the stuck quadcopter free with a improvised lance fitted to the front of a larger drone. But this ended up simply getting the larger bird stuck as well. It eventually managed to free itself, though it was damaged severely when [Scott] caught it as it fell. As told to Hackaday, [Scott] thus decided he needed to build a mock-up of the situation at home, to help him devise a rescue technique.

In the end, [Scott] settled on a grappling hook made of paperclips. A drone lofted a long length of VHS tape over the roof beam, and he then attached the grappling hook from ground level. The VHS tape was then used to reel the hook up to the rafters, and snare the drone, bringing it back down to Earth.

It took some perseverance, but [Scott] ended up rescuing his tiny drone from its lofty prison. The part we love most about this story, though, is that [Scott] planned the recovery like a heist or a cave rescue operation.

Continue reading “Drone Rescue Uses VHS Tape And Careful Planning” →
Blinky Project Is 6502s All The Way Down

Virtually any platform you might find yourself programming on has some simple method of running a delay. [Joey Shepard] got rather creative on a recent project, though, relying on a rather silly nesting method that we’re calling 6502s All The Way Down.

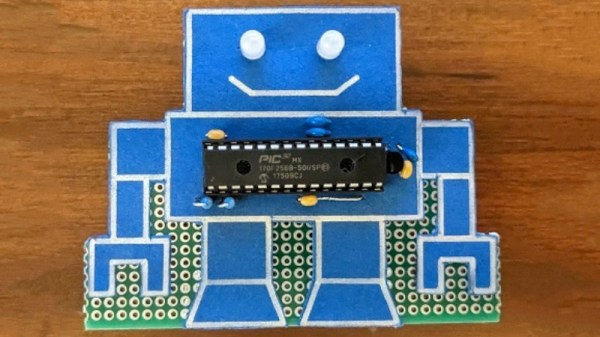
The project in question was a simple PCB that was shaped like a robot, with blinking LED eyes. Typically, you’d simply reach for the usual sleep() or delay() function to control the blink rate, but [Joey] went off-piste for this one. Instead, the PIC32 on the board runs a 6502 emulator written in MIPS assembly. This emulated 6502 is then charged with running a further 6502 emulator coded in 6502 assembly, and so on, until there’s 6502 emulators running six-deep on the humble microcontroller. The innermost emulator runs a simple program that blinks the LED eyes in a simple loop. With the overhead of running six emulators, though, the eyes only blink at a rate of roughly once every two seconds.

It’s an amusing and complicated way to write a blink program, and we applaud [Joey] for going to all that trouble. We imagine it was a great way to learn about programming the PIC32 as well as emulation in general. Meanwhile, if you’re working on your own emulator feats, be sure to let us know!

CoreFreq Gives Peek At CPU Performance Info On Linux

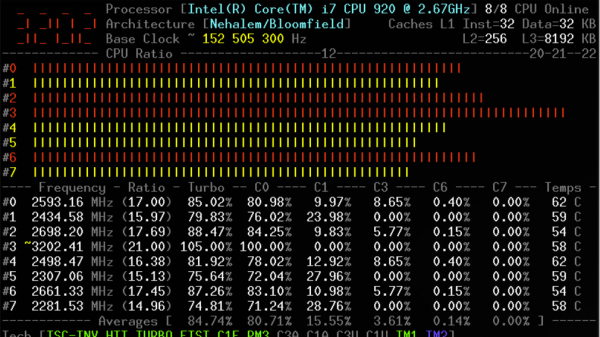
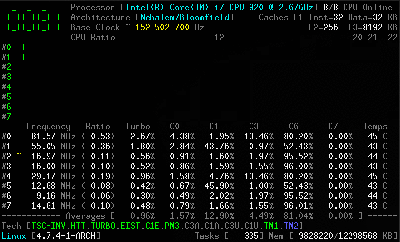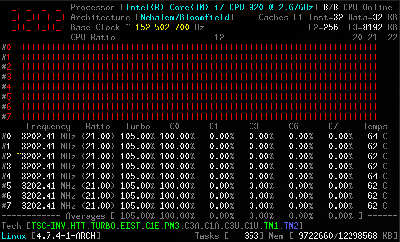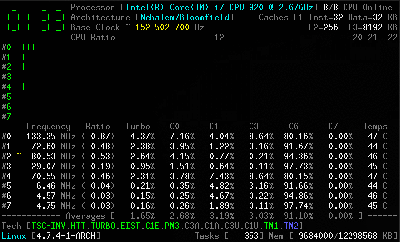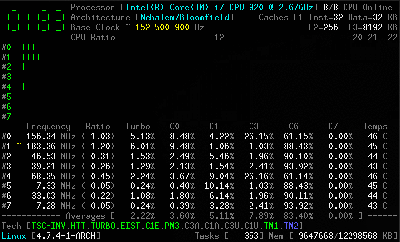
The CPU is the part of the computer that makes everything else tick. While GPUs have increasingly become a key part of overall system performance, we still find ourselves wanting to know how our CPU is doing. CoreFreq is a Linux tool that aims to tell you everything you want to know about your modern 64-bit CPU.

The tool relies on a kernel module, and is coded primarily in C, with some assembly code used to measure performance as accurately as possible. It’s capable of reporting everything from core frequencies to details on hyper-threading and turbo boost operation. Other performance reports include information on instructions per cycle or instructions per second, and of course, all the thermal monitoring data you could ask for. It all runs in the terminal, which helps keep overheads low.
The hardcore among us can build it from source, available on GitHub, though it’s reportedly available in package form, and as a live CD, too. We could imagine data captured from CoreFreq could be used for some fun performance visualizations, too. If you’ve been whipping up your own nifty command-line tools, be sure to drop us a line!

Chainless “Digital Drive” Bikes Use Electric Power Transmission Instead

We’re all familiar with how regular bikes work, with the pedals connected to the rear wheel via a simple chain drive. This setup is lightweight, cheap, and highly efficient. It’s not the only way to drive a bike though, and there’s plenty of buzz around the concept of “digital drive” bikes.

Look, ma – no chains!

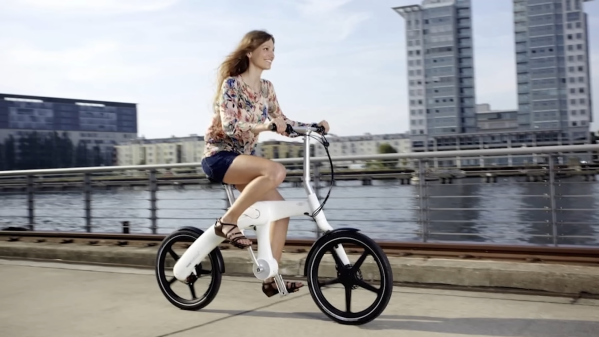
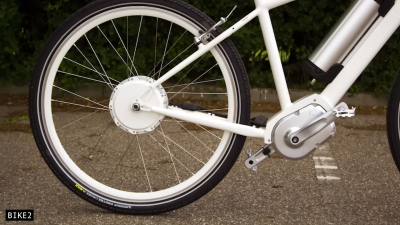
These drivetrains rely on electrical methods to transfer power in place of mechanical. The pedals are used to turn an electric generator, with power then sent to an electric motor which drives the rear wheel. The concept may sound overly complicated, but it does offer some benefits. The generator can change its operation to keep the rider pedalling at their most efficient, consistent rate. There would also be no chain to fall off, get snagged on clothing, or require regular maintenance.

It would make integrating regenerative braking possible, too, allowing the bike to harvest energy when going downhill too. This could be achieved with a storage battery or supercapacitor. As a bonus, it would be very easy to integrate power assist for the rider when tackling tough hills, for example. The lack of requirement for direct mechanical power transfer also means that there’s far more flexibility to design a bike with interesting geometry.

Such drive systems do give up some efficiency, however. All the power conversions between mechanical and electrical energy mean that a “digital drive” would likely only be 58% efficient. This compares poorly to the roughly 95% efficiency of power transfer in regular mechanically-driven bikes. There’s also a weight penalty, too.

Presnetly, there’s only one “digital drive” bike on the market – known as the Mando Footloose. It’s a swooping, folding, futuristic design, that has some feel issues when it comes to pedalling. And, given the added complexity and expense of these systems, it’s unlikely regular bikes or e-bikes are going away any time soon. Regardless, it’s fun to think about the potential for other drivetrain concepts to change the way we cycle. Video after the break.

Continue reading “Chainless “Digital Drive” Bikes Use Electric Power Transmission Instead” →

Laser Scanning Microscope Built With Blu-ray Parts

Laser scanning microscopes are useful for all kinds of tiny investigations. As it turns out, you can build one using parts salvaged from a Blu-ray player, as demonstrated by [Doctor Volt].

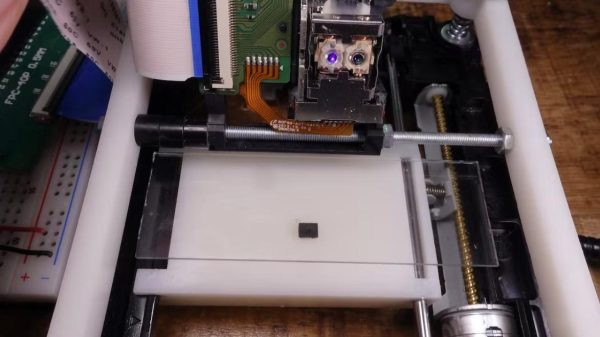
The trick is repurposing the optical pickup unit that is typically used to read optical discs. In particular, the build relies on the photodiodes that are usually used to compute focus error when tracking a disc. To turn this into a laser scanning microscope, the optical pickup is fitted to a 3D printed assembly that can slew it linearly for imaging purposes.
Meanwhile, the Blu-ray player’s hardware is repurposed to create a sample tray that slews on the orthogonal axis for full X-Y control. An ESP32 is then charged with running motion control and the laser. It also captures signals from the photodiodes and sends them to a computer for collation and display.

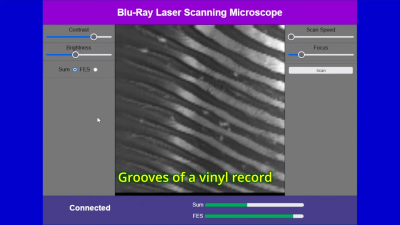
[Doctor Volt] demonstrates the microscope by imaging a small fabric fragment. The scanned area covers less than 1 mm x 1 mm, with a resolution of 127 x 127, though this could be improved with finer pitch on the slew mechanisms.

While it’s hardly what we’d call a beginner’s project, this technique still looks a lot more approachable than building your own scanning electron microscope.

Continue reading “Laser Scanning Microscope Built With Blu-ray Parts” →

Your Next Airport Meal May Be Delivered By Robot

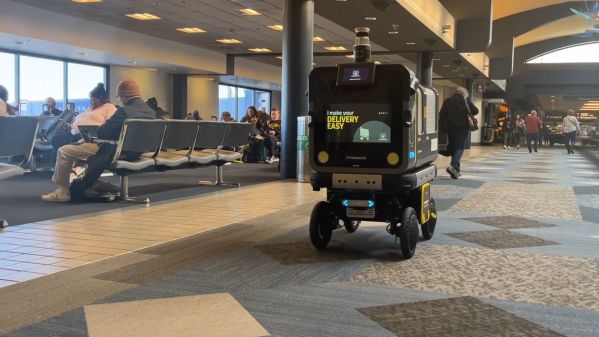
Robot delivery has long been touted as a game-changing technology of the future. However, it still hasn’t cracked the big time. Drones still aren’t airdropping packages into our gutters by accident, nor are our pizzas brought to us via self-driving cars.

That’s not to say that able minds aren’t working on the problem. In one case, a group of engineers are working ton a robot that will handle the crucial duty of delivering food to hungry flyers at the airport.

Continue reading “Your Next Airport Meal May Be Delivered By Robot” →

Working With I2S-Compatible FM Tuners

While the Internet is a great place to get access to any music or audio you can dream of, there’s still a place for broadcast radio. [mit41301] has recently been exploring implementing a simple FM tuner chip in various projects.

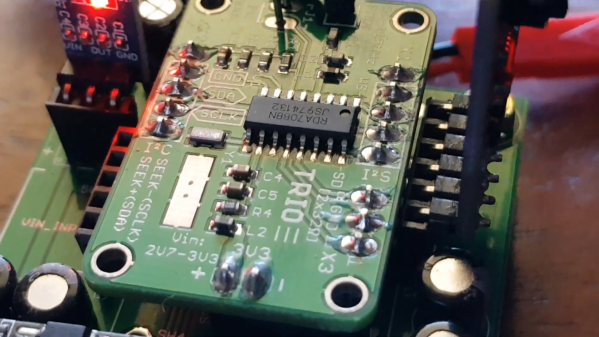
The chip in question is the RDA7088, which is designed to require the bare minimum in external components, and is available in a compact SOP16 package. As per the datasheet, it was intended for use in applications like portable radios, PDAs, cell phones, and MP3 players.

[mit41301]’s first attempt involved using the chip as a simple tuner, hooked up to a PIC10F200 for control. Investigation revealed it was capable of outputting digital audio via I2S, while being commanded via I2C. By default, it spits out audio at a low sample rate of 8 kHz, but reconfiguration will jump that up to 44.1 or 48 kHz. Piping that digital I2S stream out to a DAC then delivers analog output that can be fed to an amplifier. The build also got remote control, with the PIC handling decoding IR signals and outputting commands to the radio chip.

Following this success, [mit41301] then went further, hooking up an ESP-01 to the chip to try and get RDS going. If you’re unfamiliar with the Radio Data System, it’s a way for short textual messages to be sent out by FM broadcasters. In addition to the duties carried out by the PIC module, the ESP-01 is also charged with receiving RDS data from the RDA7088, and outputting it to a display.

While using such chips is routine in industry, it’s always great to see a DIY guide to interfacing with specific hardware. If you want to integrate FM radio into your own projects, the RDA7088 is a simple and easy way to do so. We’ve seen similar work before, adding FM radio to the Raspberry Pi.

Continue reading “Working With I2S-Compatible FM Tuners” →