Center-Pivot System Modified To Mow Lawn

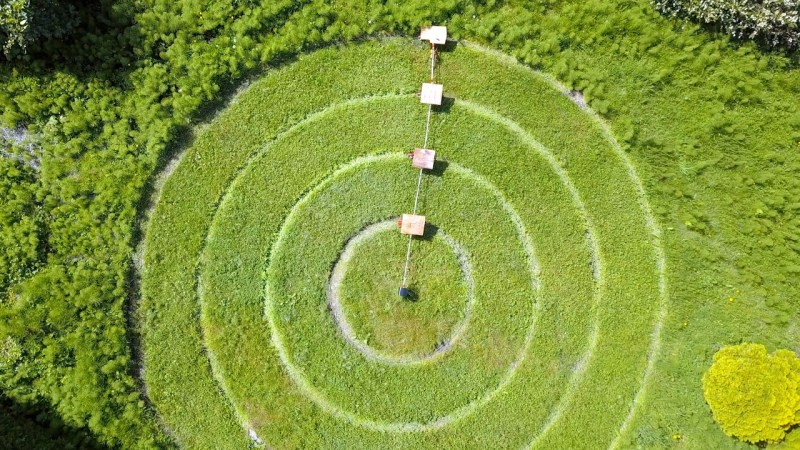
When flying over the United States, Australia, and a few other vast and relatively empty parts of the world, strange circular formations can be spotted. These are typically center-pivot irrigation systems, an effective way to irrigate crops if efficient use of space is not too big of a priority. Keeping these massive machines in a straight line is an interesting engineering problem, though, and [rctestflight] built a miniature version of his that works on the same principle but mows his lawn instead.

These systems work as semi-independent sections that are flexibly coupled at either end. The control scheme initially used here was to drive the outermost set of wheels at a constant speed, and then use limit switches at each coupling inside of that to drive inner sets of wheels once the outer set passes a setpoint. Eventually a potentiometer-based proportional controller was installed in place of the limit switches. With some other drivetrain issues sorted out it was on to building the mower attachment. This uses a pair of pivoting precision knives mounted to motors that ride along a carriage attached to any one of the linkages of the center-pivot system. Limit switches keep the carriage riding back and forth cutting the lawn as it traverses the grass.

With the system in place, [rctestflight] set out to optimize it mostly out of a desire to tinker with a thing that he had built. The challenge for him is that his location in the Pacific Northwest is generally very damp, so in addition to corrosion and other water damage on various parts, there were also issues of mud complicating the way the wheels navigated the terrain, as well as the plant growth being fairly rapid and often impeding the process of the robot as well. One of the perks, though, was that the circular area was already largely carved out thanks to some of his earlier projects testing the durability of RC cars.
Continue reading “Center-Pivot System Modified To Mow Lawn” →

Robot Makes Literal Daisy Chains

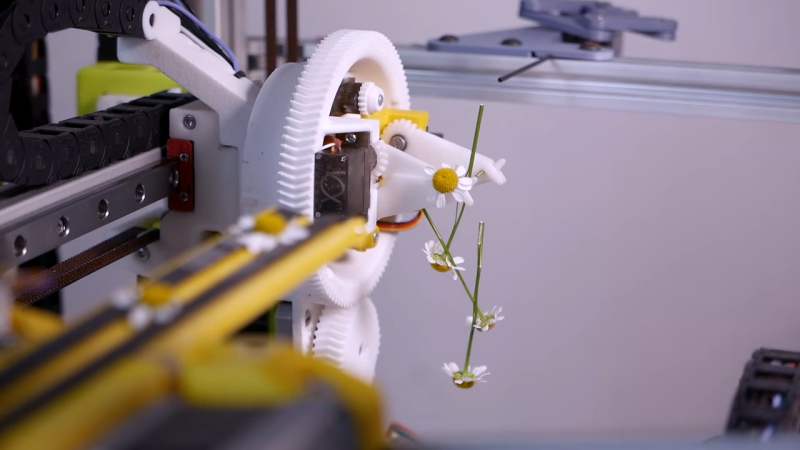
[Jude Robinson]’s robot Daisy has an unusual function: making a literal chain of daisies. The device is his student final project and demonstrates how a system can replace sensing with clever mechanical constraints. Instead of bringing tools to bear on each daisy, the daisies are brought to the tools in a repeatable, deterministic way.

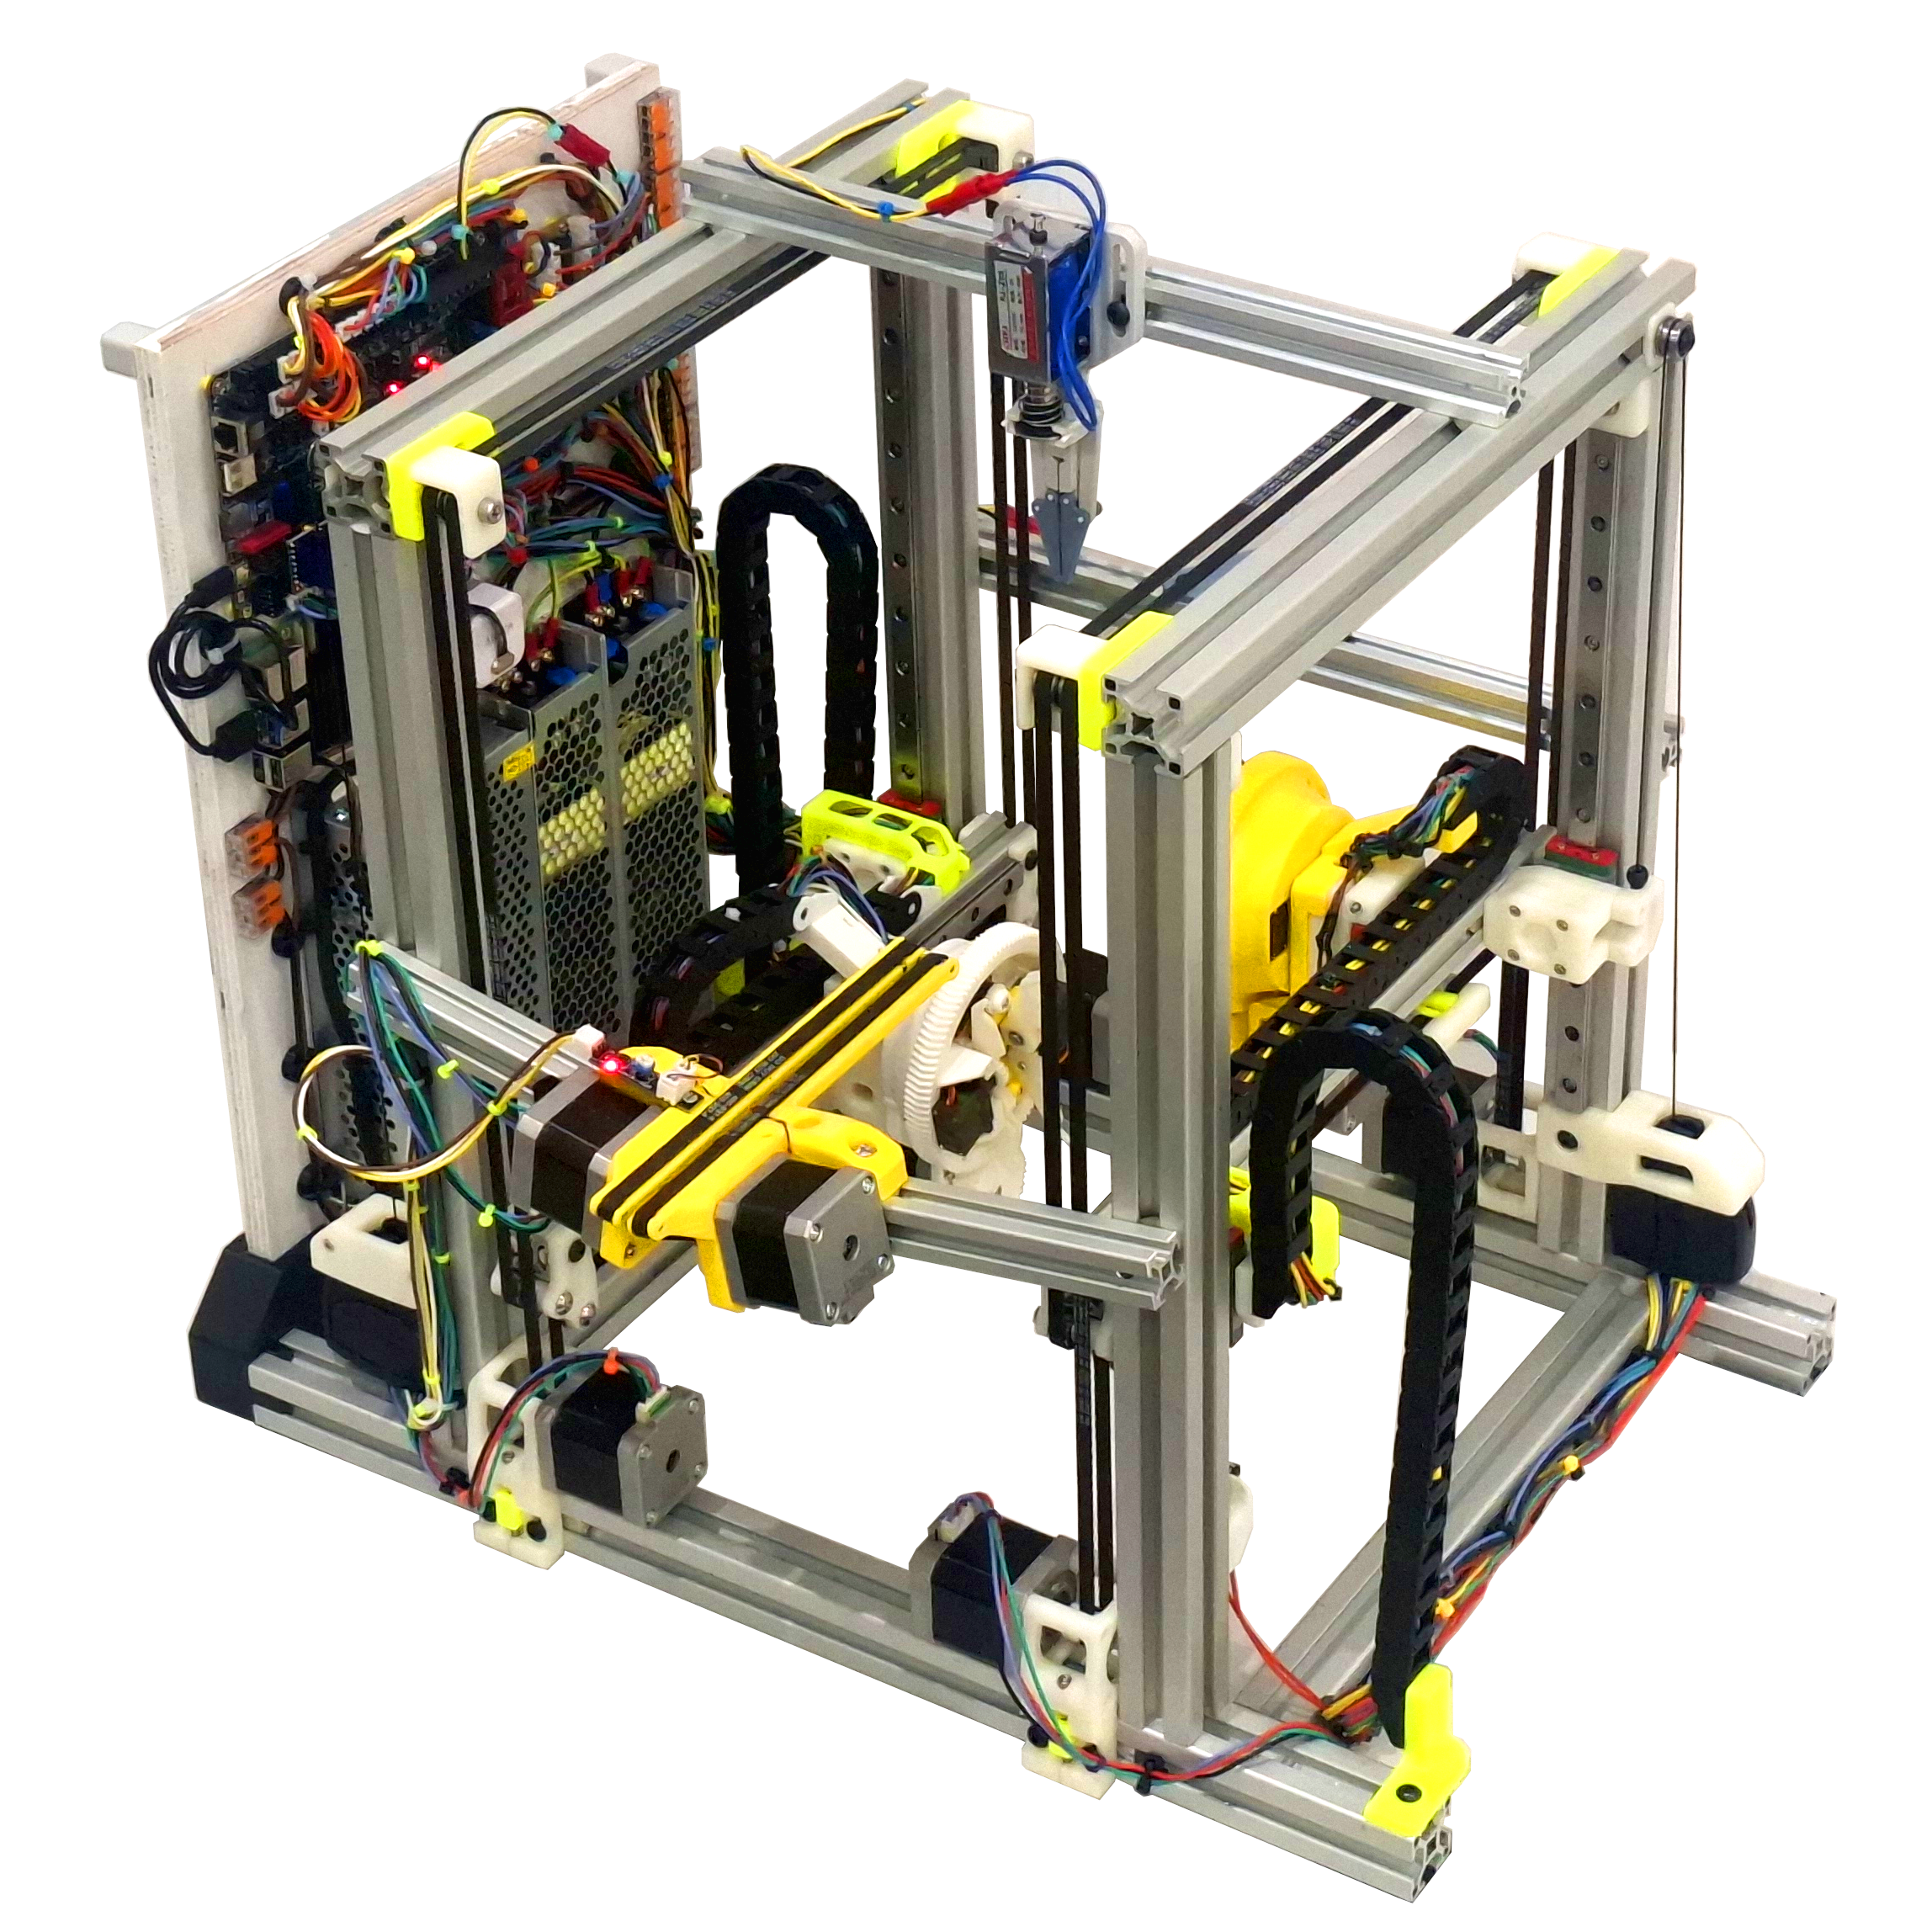
Daisy is essentially two X-Y gantries with grippers facing one another. Between them is a conveyor upon which daisies are fed, plus a blade at the top with a threading post nearby. A gripper takes a daisy, feeds the stem through the hole in the previous one, then lifts the new addition up to a scalpel blade which cuts a short incision. The thin threading post goes through the new hole in the new stem, ready for the next daisy to be inserted. The two gantries alternate roles, building the chain one daisy link at a time.

[Jude] says that daisy stem shape and diameter have the most impact on reliability, so it’s very important to constrain the daisies such that the scalpel and threading operations work reliably. This is primarily done with v-shaped profiles in the grippers which automatically center stems of different sizes. The sheath around the scalpel blade also plays a role in constraining and supporting the stems as they are gently pierced and sliced. Tuning these elements was a big part of making the system work.

Watch it in action in the video (embedded below) which shows how clever mechanical design can turn an uncertain problem — like how to handle daisies of different sizes — into a deterministic one with the help of clever mechanical design. That same concept is at work in everything from simple nut sorters to highly complex paper airplane machines.

Continue reading “Robot Makes Literal Daisy Chains” →

This Library Needs To Be At Least… Three Times Bigger

Many of us have noted a tremendous price increase in many computer components for some mysterious reason. Whatever this cause is will be debated among the various modern philosophers and Diogeneses, but regardless of cause we all still have to live in this world and make do. That turns us towards getting maximum value from the things we already have rather than trying to go out and buy more computer components right now, like [svofski] using his vast swath of existing microSD cards to build an SD card library.

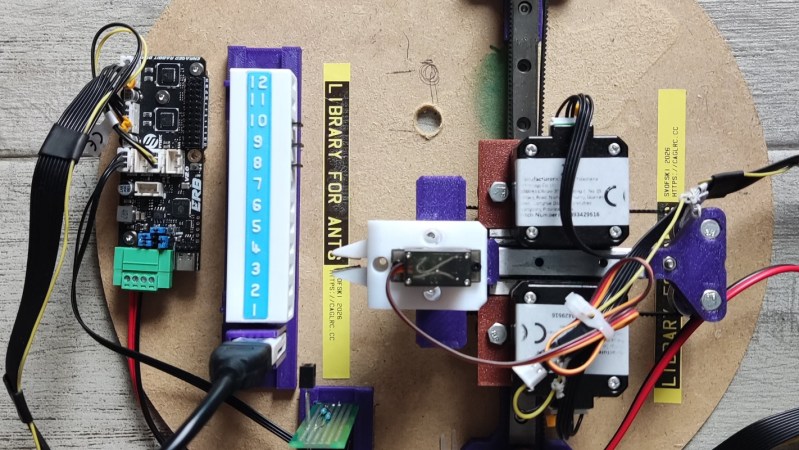
The library is based around a tiny robotic arm that can physically grip the cards and move them in and out of a reader. The first iteration of the arm involved rotating the two pincers, but this turned out to be overly complicated and [svofski] eventually settled on a design resembling a rack and pinion that slides the two pincers together instead. With the gripper sorted out, it’s placed in system called T-bot arrangement, similar to coreXY kinematics, that lets it pick and place among 12 microSD card slots.

Many of the parts in this build were directly from or inspired by 3D printers, making it relatively simple with so many parts available. [svofski] didn’t build it for a specific use case, though; mostly it was constructed out of fascination for robotic tape changers which perform a similar function. But for anyone who actually needs to duplicate a large number of SD cards, or other types of removable media, this could prove to be a fairly handy robot.

Custom Beach Robot Handles The Hard Work

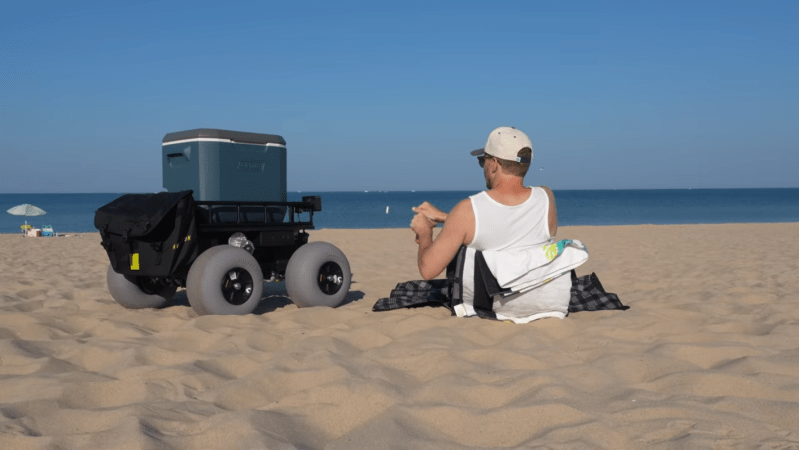
A day at the beach can involve hauling a surprising amount of gear, from coolers, towels, blankets, chairs, and umbrellas, and if children are involved the amount of beach stuff needed seems to go nonlinear very quickly. Some turn to beach carts with large, low-pressure pneumatic tires, but even that seemed like too much work for [John] who built this remote controlled cart for his summertime needs.

The cart is based around an old cargo rack from an e-bike. To mount all of the robotic components, a sheet of plywood was cut and attached to the underside. Two motors are used to drive the rear wheels independently, allowing for differential steering rather than adding the complexity of a steering system. Some safety features are built in to this design as well, including lights for night driving, a start button controlling a relay for the motors and electronics, and a time-of-flight sensor to stop the robot if it encounters an obstacle.

The ESP32 at the center of the build ties all of the electronics together, and a smartphone app lets the user remotely pilot the rover. It’s not autonomous (yet) but a fair alternative to dragging all of one’s beach gear through the sand without any assistance. You could also minimize your excursions through the sand by timing your visits at high tide, but [John] is out on the Great Lakes so this may be of marginal utility here.

Continue reading “Custom Beach Robot Handles The Hard Work” →

Open Source Vacuum Avoids Cloud

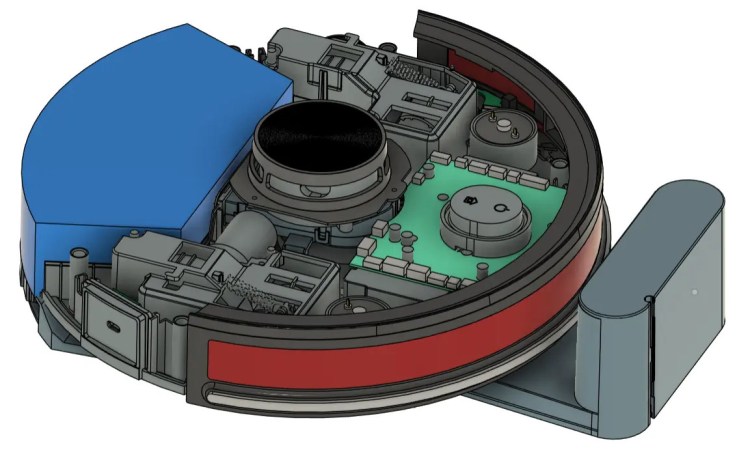
As more and more of the technology that we paid for turns becomes a subscription, there’s slowly been a momentum shift in the open source world of building replacements for these intrusive rent-seekers. We see this all of the time for self-hosted media and communications servers, but now we’re starting to see it in hardware as well. The OOMWOO robotic vacuum cleaner is completely open source, from hardware to software, and requires no cloud services whatsoever.

Although it’s open source, not every component is something one could buy off the shelf. It does require a 3D printer for most of the parts, but assuming that requirement is met most of the rest of the build comes together easily enough. For compute it relies on a Raspberry Pi running ROS 2 software and is set up to integrate easily with other existing open tools and projects such as Home Assistant. Like its proprietary cousins it can sense and map the rooms its placed in, but this platform uses an inexpensive 2D lidar system to keep costs down.

Right now the project is not quite complete, so we’ll all have to keep our eyes on this one as the team building it progresses. But they do have most of the software development done and the bill-of-materials is in progress. As an open project it’s being developed by many volunteers and there are a lot of areas available to contribute to as well, all currently set up on the project’s GitHub page. Right now many of those areas of effort are adapting the 3D printer files to off-the-shelf parts.

With the rocky status of the Roomba ecosystem, projects like this are more important than ever.

Web Tool Lets You Take Steam Controller For A Drive

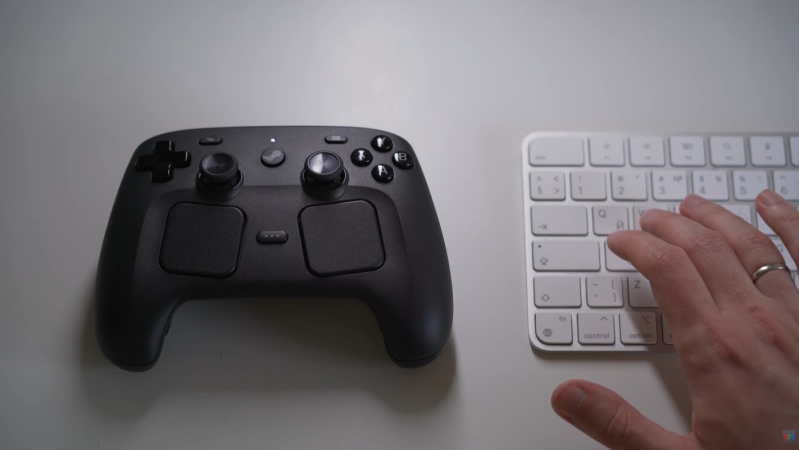
One of the simplest robots to make is a bristlebot — a motor with an offset weight is attached to the head of a toothbrush, and the resulting vibrations will move the contraption across a flat surface. [Very Lazy Pixels] recently took this idea a bit further by turning the Steam Controller into a steerable, bristlebot-like robot.

To drive one’s Steam Controller across a desk, all that is needed is for a computer with a paired controller and a Chromium-based browser. From there, using the WASD buttons, the web interface converts traditional video game inputs into controller motion by spinning the controller’s rumble motors at a specific frequency. With precise control of these motors, the controller can move forwards and backwards and even turn, which is a great deal more advanced than the traditional bristlebots generally manage.

Part of what makes this possible is Valve’s willingness to release information about many of their products to the general public, enabling anyone to modify or upgrade those products to their liking. While not completely open source, it’s a step in the right direction and enables fun projects like these. We’ve seen other Valve products turned into surprisingly barebones single-board computers as well as custom portable workstations thanks to this philosophy.

Continue reading “Web Tool Lets You Take Steam Controller For A Drive” →

Increasing Local GPS Accuracy For A Small Robot

Even though GPS makes it possible for us to easily navigate around the planet in almost any vehicle we’d like, whether that’s a passenger vehicle, airplane, or cargo ship, it’s not really suitable for applications that require sub-meter accuracy. For that, some specialized hardware is needed, and [GreatScott!] shows us how to do it using a small robot as a platform.

The key to extremely accurate GPS signals in this case is using a receiver that supports real-time kinematic positioning (RTK). This type of system relies on a base station with a known position communicating with local mobile receivers to increase the precision of those mobile receivers by comparing the phase angle of the received signals. Of course these modules are much more expensive than the average standard GPS receiver, but for this kind of accuracy there is always a cost.

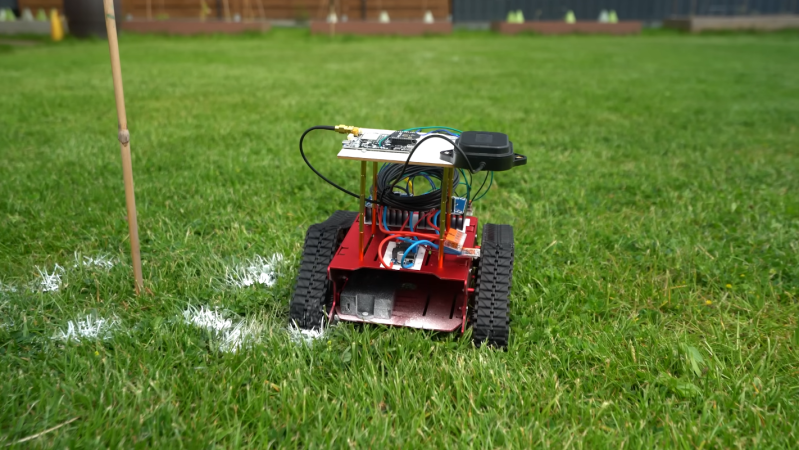
After getting a baseline accuracy of around two meters with a standard GPS receiver, [GreatScott!] installs the RTK GPS mobile receiver on a tracked robotic platform and a base station on a fence post. With the RTK system running, the limiting factor in accuracy became the robot’s steering system, as its turning radius and steering algorithms weren’t up to the task of hitting centimeter-sized targets out of the box.

But, as a proof-of-concept, it goes to show how accurate GPS can be as long as the right hardware is used, and for practical applications is good enough to mow a lawn with a robot or even do some amateur land surveying.

Continue reading “Increasing Local GPS Accuracy For A Small Robot” →