Miles The Spider Robot

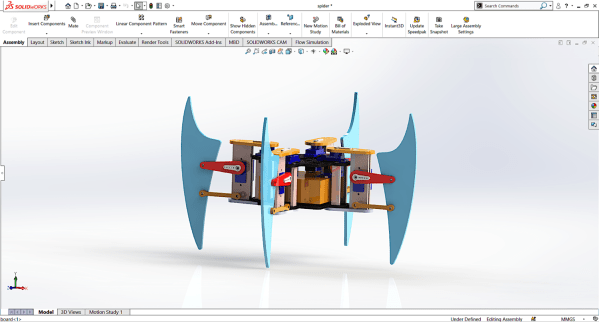
Who doesn’t love robotic spiders? Today’s biomimetic robot comes in the form of Miles, the quadruped spider robot from [_Robox].

Miles uses twelve servos to control its motion, three on each of its legs, and also includes a standard HC-SR04 ultrasonic distance sensor for some obstacle avoidance capabilities. Twelve servos can use quite a bit of power, so [_Robox_] had to power Miles with six LM7805 ICs to get sufficient current. [_Robox_] laser cut acrylic sheets for Miles’s body but mentions that 3D printing would work as well.

Miles uses inverse kinematics to get around, which we’ve seen in a previous project and is a pretty popular technique for controlling robotic motion. The Instructable is a little light on the details, but the source code is something to take a look at. In addition to simply moving around [_Robox_] developed code to make Miles dance, wave, and take a bow. That’s sure to be a hit at your next virtual show-and-tell.

By now you’re saying “wait, spiders have eight legs”, and of course you’re right. But that’s an awful lot of servos. Anyway, if you’d rather 3D print your four-legged spider, we have a suggestion.
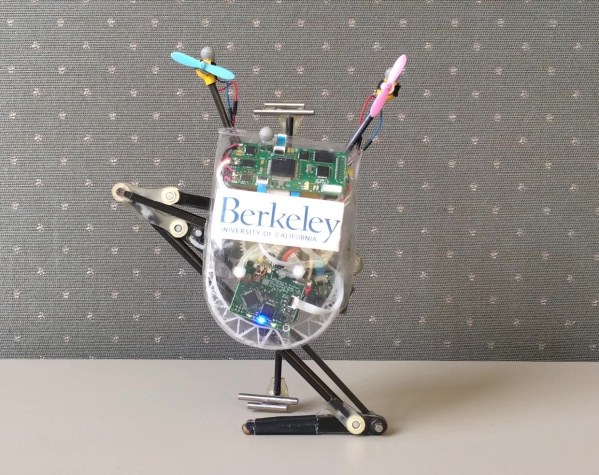
Little Jumping Bot Can Now Stick The Perfect Landing

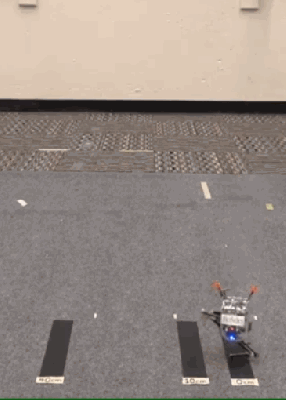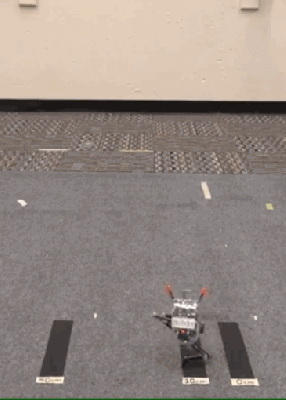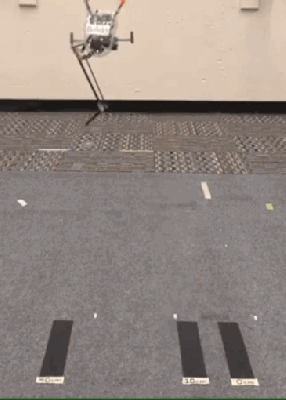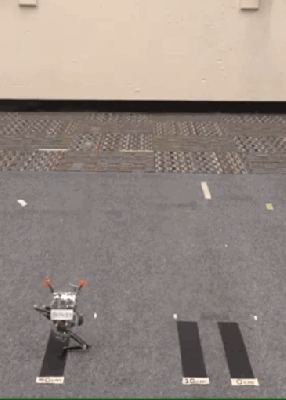
Sticking the perfect landing can take years of practice for a human gymnast, and it seems the same is true for little monopedal jumping robots. Salto-1P, an old acquaintance here on Hackaday, always needed to keep jumping to stay upright. With some clever control software improvements, it can now land reliably on an area the size of a coin, and then stay there. (Video after the break)

[Justin Yim] from the UC Berkeley’s Biomimetics Lab has been working on Salto for the past four years, and we’ve covered it twice before. Attitude control is handles by a combination of propeller thrusters for roll and yaw, and a reaction wheel for pitch.While it was already impressive before, it had a predictable landing area about the size of a dinner plate.

The trick to the perfect landing is a combination of landing angle, angular velocity and angular momentum. Salto can only correct for ±2.3° of landing angle error, because it doesn’t have a second foot to catch itself when something goes wrong. Ideally the robot’s angular velocity and momentum should be as close as possible to 0 at takeoff, which gives the reaction wheel maximum control authority in flight, as well as on landing.  Basically a well executed takeoff directly influences the chances of a good landing.  [Justin] does an excellent job explaining all this and more on the project’s presentation video. Continue reading “Little Jumping Bot Can Now Stick The Perfect Landing” →

Slipping Sheets Map Multiple Bends In This Ingenious Flex Sensor

When thoughts turn to measuring the degree to which something bends, it’s pretty likely that strain gauges or some kind of encoders on a linkage come to mind. Things could be much simpler in the world of flex measurement, though, if [Fereshteh Shahmiri] and [Paul H. Dietz]’s capacitive multi-bend flex sensor catches on.

This is one of those ideas that seems so obvious that you don’t know why it hasn’t been tried before. The basic idea is to leverage the geometry of layered materials that slip past each other when bent. Think of the way the pages of a hardbound book feather out when you open it, and you’ll get the idea. In the case of the ShArc (“Shift Arc”) sensor, the front and back covers of the book are flexible PCBs with a series of overlapping pads. Between these PCBs are a number of plain polyimide spacer strips. All the strips of the sensor are anchored at one end, and everything is held together with an elastic sleeve. As the ShArc is bent, the positions of the electrodes on the top and bottom layers shift relative to each other, changing the capacitance across them. From the capacitance measurements and the known position of each pad, a microcontroller can easily calculate the bend radius at each point and infer the curvature of the whole strip.

The video below shows how the ShArc works, as well as several applications for the technology. The obvious use as a flex sensor for the human hand is most impressive — it could vastly simplify [Will Cogley]’s biomimetic hand controller — but such sensors could be put to work in any system that bends. And as a bonus, it looks pretty simple to build one at home.

Continue reading “Slipping Sheets Map Multiple Bends In This Ingenious Flex Sensor” →

A Better Motor For Chickenwalkers

The last decade or so has seen remarkable advances in motor technology for robotics and hobby applications. We’re no longer stuck with crappy brushed motors, and now we have fancy (and cheap!) stepper motors, brushless motors for drones, and servo motors. This has led to some incredible achievements; drones are only barely possible with brushed motors, and you can’t build a robot without encoders.

For his entry into the Hackaday Prize, [Gabrael Levine] is taking on one of the hardest robotics challenges around: the bipedal robot. It’s a chickenwalker, or an AT-ST; either way, you need a lot of power in a very small space, and that’s where the OpenTorque Actuator comes in. It’s a quasi-direct-drive motor that was originally pioneered by the MIT Biomimetics Lab.

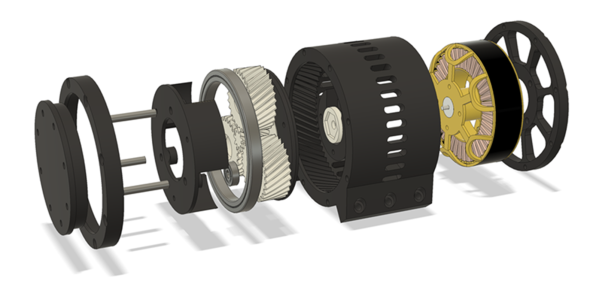
The key feature of the OpenTorque Actuator is using a big brushless motor, a rotation encoder, and a small, 8:1 planetary gear set. This allows the motor to be backdrivable, capable of force-sensing and open-loop control, and because this actuator is 3D printed, it’s really cheap to produce.

But a motor without a chassis is nothing, and that’s where the Blackbird Bipedal Robot comes in. In keeping with best practices of robotic design, the kinematics are first being tested in simulation, with the mechanical build happening in parallel. That means there’s some great videos of this chickenwalker strutting around (available below), and so far, everything looks great. This bipedal robot can turn, walk, yaw, and work is continuing on the efforts to get this bird-legged bot to stand still.

Interstellar 8-Track: The Not-So-Low-Tech Data Recorders Of Voyager

On the outside chance that we ever encounter a space probe from an alien civilization, the degree to which the world will change cannot be overestimated. Not only will it prove that we’re not alone, or more likely weren’t, depending on how long said probe has been traveling through space, but we’ll have a bonanza of super-cool new technology to analyze. Just think of the fancy alloys, the advanced biomimetic thingamajigs, the poly-godknowswhat composites. We’ll take a huge leap forward by mimicking the alien technology; the mind boggles.

Sadly, we won’t be returning the favor. If aliens ever snag one of our interstellar envoys, like one of the Voyager spacecraft, they’ll see that we sent them some really old school stuff. While one team of alien researchers will be puzzling over why we’d encode images on a phonograph record, another team will be tearing apart – an 8-track tape recorder?

Continue reading “Interstellar 8-Track: The Not-So-Low-Tech Data Recorders Of Voyager” →

Mechatronic Hand Mimics Human Anatomy To Achieve Dexterity

Behold the wondrous complexity of the human hand. Twenty-seven bones working in concert with muscles, tendons, and ligaments extending up the forearm to produce a range of motions that gave us everything from stone tools to symphonies. Our hands are what we use to interface with the physical world on a fine level, and it’s understandable that we’d want mechanical versions of ourselves to include hands that were similarly dexterous.

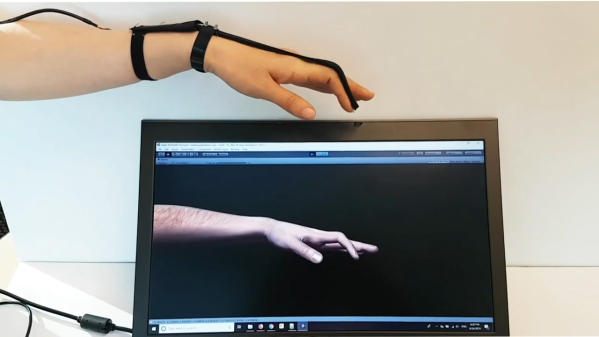
That’s a tall order to fill, but this biomimetic mechatronic hand is a pretty impressive step in that direction. It’s [Will Cogley]’s third-year university design project, which he summarizes in the first video below. There are two parts to this project; the mechanical hand itself and the motion-capture glove to control it, both of which we find equally fascinating. The control glove is covered with 3D-printed sensors for each joint in the hand. He uses SMD potentiometers to measure joint angles, with some difficulty due to breakage of the solder joints; perhaps he could solve that with finer wires and better strain relief.

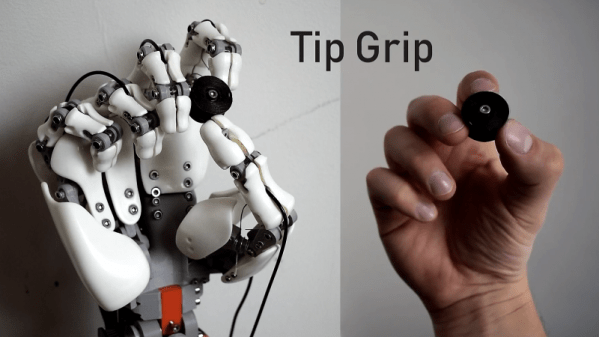
The hand that the glove controls is a marvel of design, like something on the end of a Hollywood android’s arm. Each finger joint is operated by a servo in the forearm pulling on cables; the joints are returned to the neutral position by springs. The hand is capable of multiple grip styles and responds fairly well to the control glove inputs, although there is some jitter in the sensors for some joints.

The second video below gives a much more detailed overview of the project and shows how [Will]’s design has evolved and where it’s going. Anthropomorphic hands are far from rare projects hereabouts, but we’d say this one has a lot going for it.

Continue reading “Mechatronic Hand Mimics Human Anatomy To Achieve Dexterity” →

Soft Robotic Jellyfish Get Pumped In The Atlantic

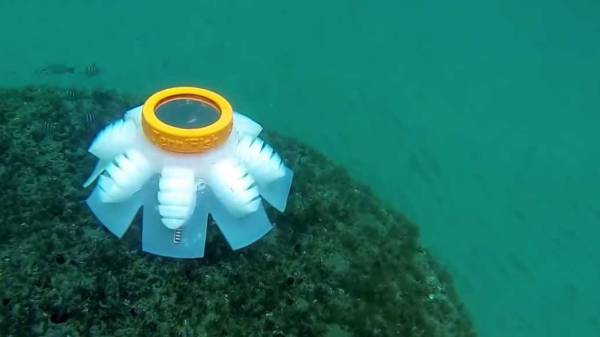
In a recent paper in Bioinspiration & Biomimetics, researchers at Florida Atlantic University describe the process of building and testing five free-swimming soft robotic jellyfish. The paper contains build details and data on how three different variables – tentacle stiffness, stroke frequency, and stroke amplitude – affect the swimming characteristics of each bot. For a more in-depth build log, we found the original masters thesis by Jennifer Frame to be very thorough, including processes, schematics, parts lists, and even some Arduino code.

Though a landlubber may say the robots look more like a stumpy octopus than a jellyfish, according to the paper the shape is actually most similar to a juvenile “ephyra stage” moon jellyfish, with 8 short tentacles radiating from a central body. The flexible tentacles are made of a silicon rubber material from Smooth-On, and were cast in 3D printed molds. Inside the waterproof main body is a Teensy 3.2 microcontroller, some flash memory, a nine-axis IMU, a temperature sensor, and a 9 V battery.

There are two flexible resistors embedded in the body to measure tentacle flex, and the actual flexing is done by pumping seawater through open circuit hydraulic channels cast into the tentacles. Two 3 V mini pumps are sufficient for pumping, and the open circuit means that when the pumps turn off, the tentacles bleed off any remaining pressure and quickly snap back to their “neutral” position without the use of complicated valves.

Another simple feature is two hall effect sensors that were mounted in the body to enable waterproof “wireless communication” with the microcontroller. The wireless protocol of choice: manually waving magnets over the sensors to switch the robot between a few predefined operating modes.

There’s a soothing, atmospheric video after the break, where you can see the robots in action off the coast of Florida.

Continue reading “Soft Robotic Jellyfish Get Pumped In The Atlantic” →