Robots Collaborate To Localize Themselves Precisely

Here’s the thing about robots. It’s hard for them to figure out where to go or what they should be doing if they don’t know where they are. Giving them some method of localization is key to their usefulness in almost any task you can imagine. To that end, [Guy Elmakis], [Matan Coronel] and [David Zarrouk] have been working on methods for pairs of robots to help each other in this regard.

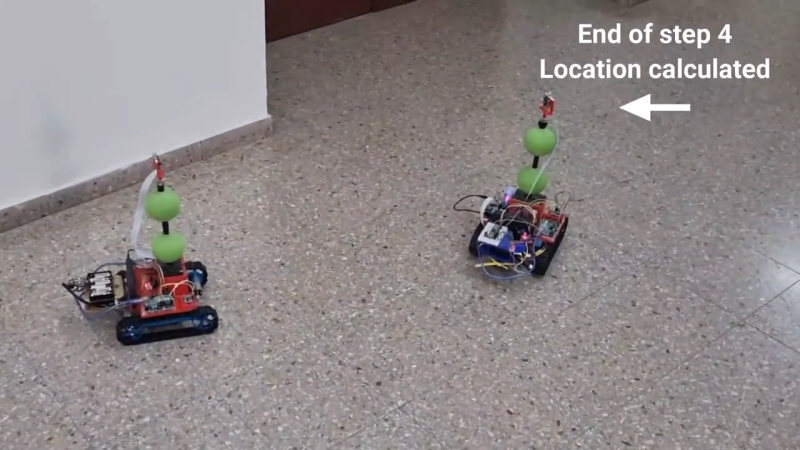
As per the research paper, the idea is to perform real-time 3D localization between two robots in a given location. The basic idea is that the robots take turns moving. While one robot moves, the other effectively acts as a landmark. The robots are equipped with inertial measurement units and cameras in a turret, which they use to track each other and their own movements. Each robot is equipped with a Raspberry Pi 4 for processing image data and computing positions, and the two robots communicate via Bluetooth to coordinate their efforts.

It’s an interesting technique that could have some real applications in swarm robotics, and in operations in areas where satellite navigation and other typical localization techniques are not practical. If you’re looking for more information, you can find the paper here. We’ve seen some other neat localization techniques for small robots before, too. Video after the break.

Continue reading “Robots Collaborate To Localize Themselves Precisely” →
Achieving Human Level Competitive Robot Table Tennis

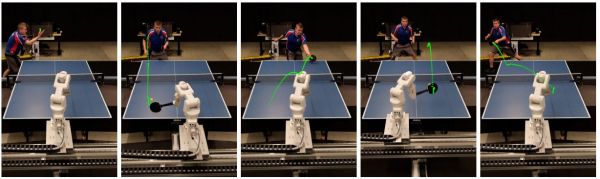
A team at Google has spent a lot of time recently playing table tennis, purportedly only for science. Their goal was to see whether they could construct a robot which would not only play table tennis, but even keep up with practiced human players. In the paper available on ArXiv, they detail what it took to make it happen. The team also set up a site with a simplified explanation and some videos of the robot in action.

Table tennis robot vs human match outcomes. B is beginner, I is intermediate, A is advanced. (Credit: Google)

In the end, it took twenty motion-capture cameras, a pair of 125 FPS cameras, a 6 DOF robot on two linear rails, a special table tennis paddle, and a very large annotated dataset to train multiple convolutional neural networks (CNN) on to analyze the incoming visual data. This visual data was then combined with details like knowledge of the paddle’s position to churn out a value for use in the look-up table that forms the core of the high-level controller (HLC). This look-up table then decides which low-level controller (LLC) is picked to perform a certain action. In order to prevent the CNNs of the LLCs from ‘forgetting’ the training data, a total of 17 different CNNs were used, one per LLC.

The robot was tested with a range of players from a local table tennis club which made clear that while it could easily defeat beginners, intermediate players pose a serious threat. Advanced players completely demolished the table tennis robot. Clearly we do not have to fear our robotic table tennis playing overlords just yet, but the robot did receive praise for being an interesting practice partner. Continue reading “Achieving Human Level Competitive Robot Table Tennis” →

Hackaday Links Column Banner

Hackaday Links: July 28, 2024

What is this dystopia coming to when one of the world’s largest tech companies can’t find a way to sufficiently monetize a nearly endless stream of personal data coming from its army of high-tech privacy-invading robots? To the surprise of almost nobody, Amazon is rolling out a paid tier to their Alexa service in an attempt to backfill the $25 billion hole the smart devices helped dig over the last few years. The business model was supposed to be simple: insinuate an always-on listening device into customers’ lives to make it as easy as possible for them to instantly gratify their need for the widgets and whatsits that Amazon is uniquely poised to deliver, collecting as much metadata along the way as possible; multiple revenue streams — what could go wrong? Apparently a lot, because the only thing people didn’t do with Alexa was order stuff. Now Amazon is reportedly seeking an additional $10 a month for the improved AI version of Alexa, which will be on top of the ever-expanding Amazon Prime membership fee, currently at an eye-watering $139 per year. Whether customers bite or not remains to be seen, but we think there might be a glut of Echo devices on the second-hand market in the near future. We hate to say we told you so, but — ah, who are we kidding? We love to say we told you so.

Continue reading “Hackaday Links: July 28, 2024” →

An RC Tracked Robot, Without The Pain

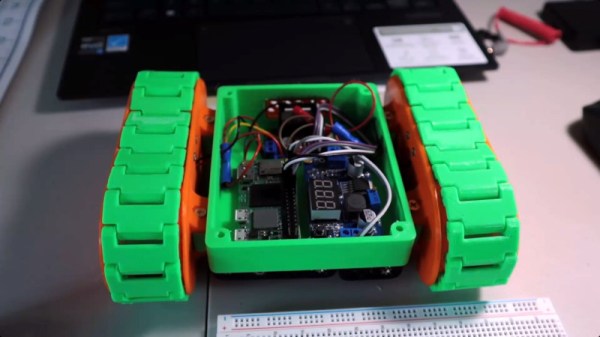
Small robots can be found at all levels from STEM toys for kids all the way through to complex hacker projects. Somewhere along that line between easy enough for anyone to build and interesting enough for hackers lies the PlayCar, from [ComfySpace]. It’s a small build-it-yourself tracked robot that’s controlled from your smartphone via an app.

At the PlayCar’s heart is a Raspberry Pi Zero 2W, and surrounding it are a set of inexpensive off the shelf modules for power and motor control. The juice meanwhile comes from a set of AA batteries, and the motors are geared DC units. Having acquired all the components, the 3D printable parts can then be downloaded from Printables, and the ComfySpace app can be downloaded for either Apple or Android platforms.

It’s clear that ComfySpace is a start-up targeting the education sector, and we wish them every success. The approach of making an open platform is one we like, as it has the potential to create a community feeding back designs and add-ons rather than remaining proprietary. You can take a  look at the video below the break for more information.

Continue reading “An RC Tracked Robot, Without The Pain” →

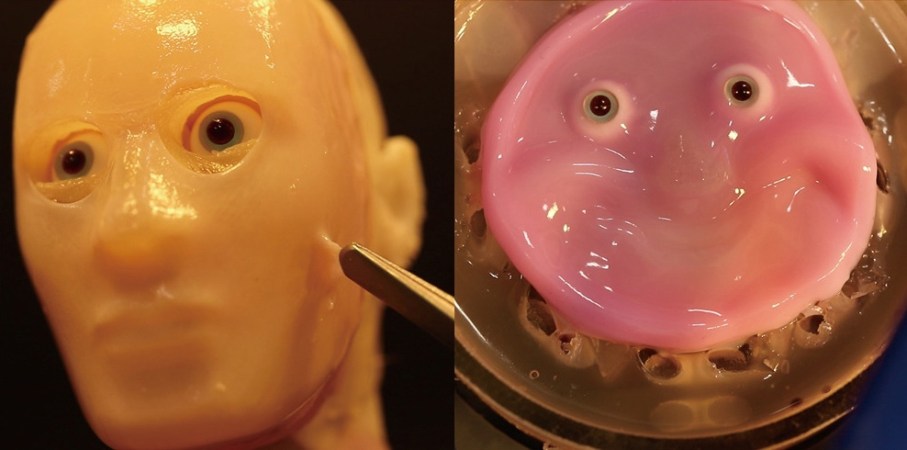
On the left, a transluscent yellowy-tan android head with eyes set behind holes in the face. On the right, a bright pink circle with small green eyes. It is manipulated into the image of a smiling face via its topography.

A Robot Face With Human Skin

Many scifi robots have taken the form of their creators. In the increasingly blurry space between the biological and the mechanical, researchers have found a way to affix human skin to robot faces. [via NewScientist]

Previous attempts at affixing skin equivalent, “a living skin model composed of cells and extracellular matrix,” to robots worked, even on moving parts like fingers, but typically relied on protrusions that impinged on range of motion and aesthetic concerns, which are pretty high on the list for robots designed to predominantly interact with humans. Inspired by skin ligaments, the researchers have developed “perforation-type anchors” that use v-shaped holes in the underlying 3D printed surface to keep the skin equivalent taut and pliable like the real thing.

The researchers then designed a face that took advantage of the attachment method to allow their robot to have a convincing smile. Combined with other research, robots might soon have skin with touch, sweat, and self-repair capabilities like Data’s partial transformation in Star Trek: First Contact.

We wonder what this extremely realistic humanoid hand might look like with this skin on the outside. Of course that raises the question of if we even need humanoid robots? If you want something less uncanny, maybe try animating your stuffed animals with this robotic skin instead?

Supercon 2023: Jesse T. Gonzalez Makes Circuit Boards That Breathe And Bend

Most robots are built out of solid materials like metal and plastic, giving them rigid structures that are easy to work with and understand. But you can open up much wider possibilities if you explore alternative materials and construction methods. As it turns out, that’s precisely what [Jesse T. Gonzalez] specializes in.

Jesse is a PhD candidate at Carnegie Mellon’s Human-Computer Interaction Institute, and an innovator to boot. His talk at the 2023 Hackaday Supercon covers his recent work on making circuit boards that can breathe and bend. You might not even call them robots, but his creations are absolutely robotic.

Continue reading “Supercon 2023: Jesse T. Gonzalez Makes Circuit Boards That Breathe And Bend” →

Robot Seeks And Sucks Up Cigarette Butts, With Its Feet

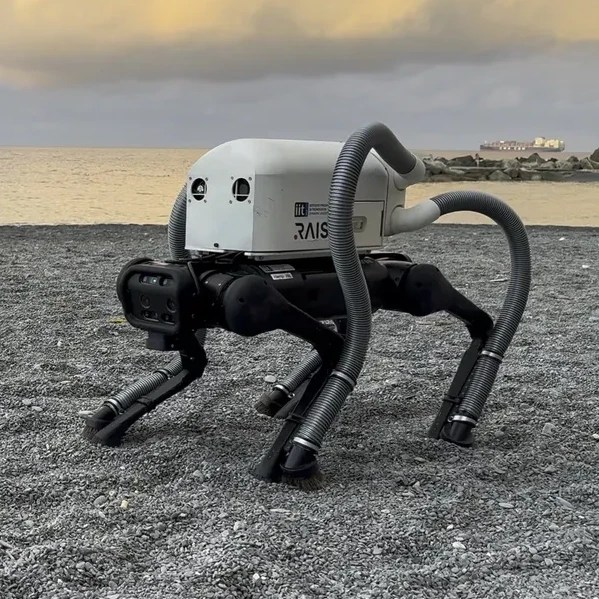
It would be better if humans didn’t toss cigarette butts on the ground in the first place, but change always takes longer than we think it should. In the meantime, researchers at the Italian Institute of Technology have used the problem as an opportunity to explore what seems to be a novel approach: attaching vacuum pickups to a robot’s feet, therefore removing the need for separate effectors.

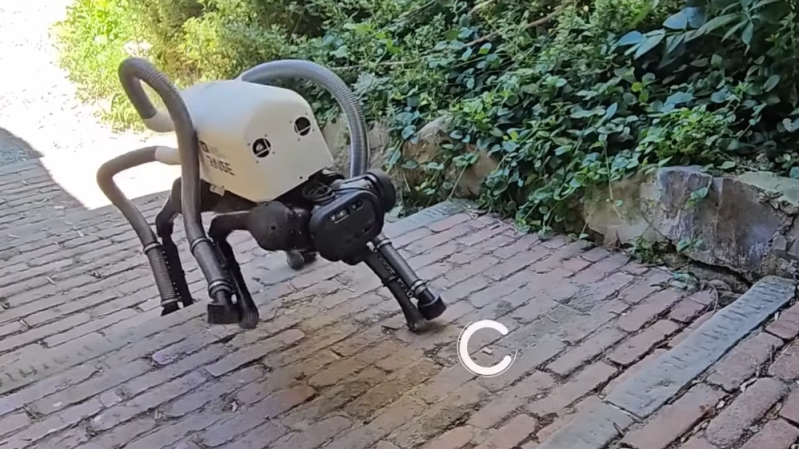
VERO (Vacuum-cleaner Equipped RObot) is a robotic dog with a vacuum cleaner “backpack” and four hoses, one going down each leg. A vision system detects a cigarette butt, then ensures the robot plants a foot next to it, sucking it up. The research paper has more details, but the video embedded below gives an excellent overview.

While VERO needs to think carefully about route planning, using the legs as effectors is very efficient. Being a legged robot, VERO can navigate all kinds of real-world environments — including stairs — which is important because cigarette butts know no bounds.

Also, using the legs as effectors means there is no need for the robot to stop and wait while a separate device (like an arm with a vacuum pickup) picks up the trash. By simply planting a foot next to a detected cigarette butt, VERO combines locomotion with pickup.

It’s fascinating to see how the Mini Cheetah design has really become mainstream to the point that these robots are available off-the-shelf, and it’s even cooler to see them put to use. After all, robots tackling trash is a good way to leverage machines that can focus on specific jobs, even if they aren’t super fast at it.

Continue reading “Robot Seeks And Sucks Up Cigarette Butts, With Its Feet” →