Center-Pivot System Modified To Mow Lawn

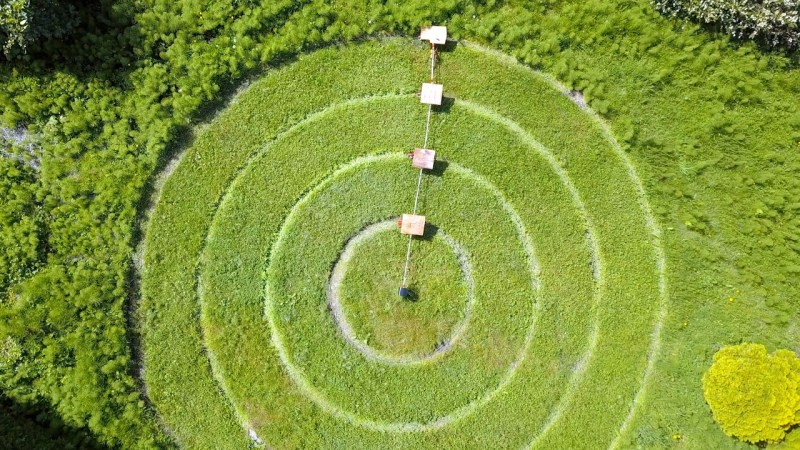
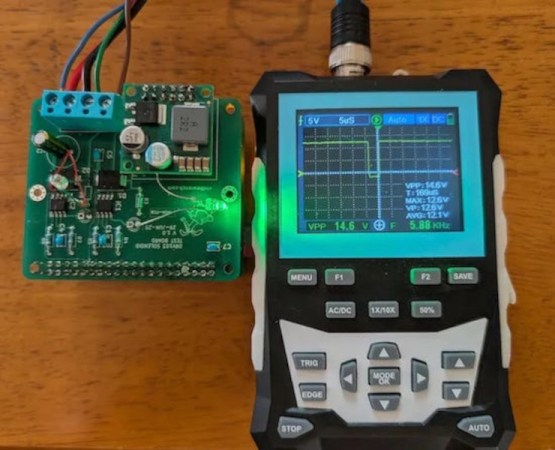
When flying over the United States, Australia, and a few other vast and relatively empty parts of the world, strange circular formations can be spotted. These are typically center-pivot irrigation systems, an effective way to irrigate crops if efficient use of space is not too big of a priority. Keeping these massive machines in a straight line is an interesting engineering problem, though, and [rctestflight] built a miniature version of his that works on the same principle but mows his lawn instead.

These systems work as semi-independent sections that are flexibly coupled at either end. The control scheme initially used here was to drive the outermost set of wheels at a constant speed, and then use limit switches at each coupling inside of that to drive inner sets of wheels once the outer set passes a setpoint. Eventually a potentiometer-based proportional controller was installed in place of the limit switches. With some other drivetrain issues sorted out it was on to building the mower attachment. This uses a pair of pivoting precision knives mounted to motors that ride along a carriage attached to any one of the linkages of the center-pivot system. Limit switches keep the carriage riding back and forth cutting the lawn as it traverses the grass.

With the system in place, [rctestflight] set out to optimize it mostly out of a desire to tinker with a thing that he had built. The challenge for him is that his location in the Pacific Northwest is generally very damp, so in addition to corrosion and other water damage on various parts, there were also issues of mud complicating the way the wheels navigated the terrain, as well as the plant growth being fairly rapid and often impeding the process of the robot as well. One of the perks, though, was that the circular area was already largely carved out thanks to some of his earlier projects testing the durability of RC cars.
Continue reading “Center-Pivot System Modified To Mow Lawn” →

Converting A Sprinkler System To DC

Famously, Nikola Tesla won the War of the Currents in the early days of electrification because his AC system could use transformers to minimize losses for long distance circuits. That was well before the invention of the transistor, though, and there are a lot of systems that still use AC now as a result of electricity’s history that we might otherwise want to run on DC in our modern world. Sprinkler systems are one of these things, commonly using a 24V AC system, but [Vinthewrench] has done some work to convert over to a more flexible 24 VDC system instead.

The main components of these systems that are set up for AC are solenoids which activate various sets of sprinklers. But these solenoids can take DC and still work, so no major hardware changes are needed. It’s not quite as simple as changing power supplies, though. The solenoids will overheat if they’re fully powered on a DC circuit, so [Vinthewrench] did a significant amount of testing to figure out exactly how much power they need to stay engaged. Once the math was done, he uses a DRV103 to send PWM signals to the solenoids, which is set up to allow more current to pull in the solenoids and then a lower holding current once they are activated.

With a DC power supply like this, it makes it much easier to have his sprinkler system run on a solar powered system as well as use a battery backup without needing something like an inverter. And thanks to the DRV103 the conversion is not physically difficult; ensuring that the solenoids don’t overheat is the major concern here. Another great reason to convert to a DIY sprinkler controller is removing your lawn care routine from an unnecessary cloud-based service.

Autonomous Mower Hits Snag

Interfacing technology and electronics with the real world is often fairly tricky. Complexity and edge cases work their way in to every corner of a project like this; just ask anyone who has ever tried to operate a rover on Mars, make a hydroponics garden, or build almost any robotics project. Even those of us who simply own a consumer-grade printer are flummoxed by the ways in which they can fail when manipulating single sheets of paper. This robotic lawnmower is no exception, driving its creator [TK] to extremes to get it to mow his lawn.

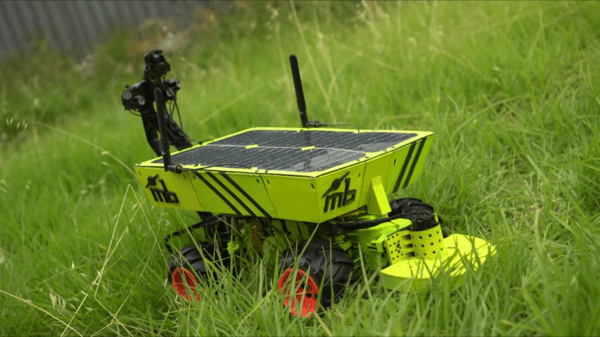
[TK] actually had a platform for his autonomous mower ready to go thanks to a previous build using this solar-powered robot to explore the Australian outback. Adding another motor to handle the grass trimming seemed simple at first and he set about wiring it all up and interfacing it to the robot. After the first iteration he found the robot was moving too fast to effectively cut the grass, so he added a more powerful cutting motor and a gearbox to help the mower crawl more slowly over the lawn. Disaster struck when his 3D printed mount for the steel cutting blades shattered, but with [TK] uninjured he pushed on with more improvements.

As it stands right now, the mower can effectively cut the grass moving forward even with the plastic-only cutting blades that [TK] is using now for safety reasons. The mower stripped its reverse gear so there still are some improvements to make before this robot is autonomously cutting the lawn without supervision. Normally we see lawnmowers retrofitted with robotics rather than robotics retrofitted with a lawnmower, but we’re excited to see any approach that lets us worry about one less household chore.

Thanks to [Rob] for the tip!

Continue reading “Autonomous Mower Hits Snag” →

Raspberry Pi Waters Your Lawn, Serves HTML

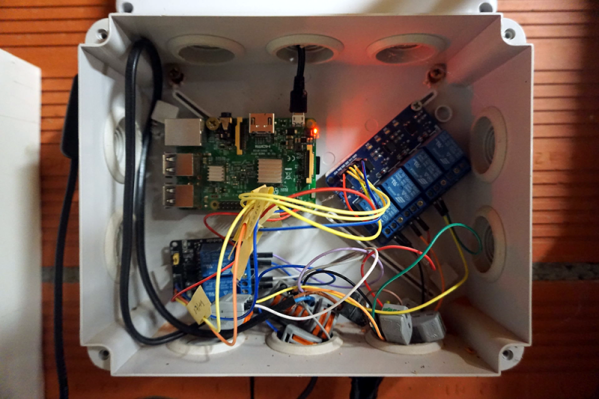
It is easy to take a Raspberry Pi and treat it like a cheap Linux PC or server. Running an ad blocker or a VPN gateway is simple and doesn’t require any real interfacing. However, it is a big leap to actually use the Pi to control something and a good example can go a long way to helping you develop your own projects. [Joeseph Luccisano] posted a tutorial with just that aim. The goal: build a low-cost lawn watering system.

It is an interesting project since it has hardware and software components, of course. But it also has a hydraulic part, so you have to deal with all three domains coming together.

Continue reading “Raspberry Pi Waters Your Lawn, Serves HTML” →

DIY Lawnmower Doesn’t Cut Grass Short

[nodemcu12ecanada] is serious about saving water, which is why they built this strange lawnmower that can cut grass taller.

Short lawns are one of those clever marketing victories, like convincing people to eat a lot of sugar, that’s been doing more harm than good ever since the victory was won. Short grass is weak grass, with shallow roots, weakness to weeds, and a lot of water requirement. On top of that the grass is always in a state of panic so it grows extra fast to get to a more “natural” height. It’s great if you want to sell fertilizer, seeds, and lawnmowers. Maybe not so great for the environment.

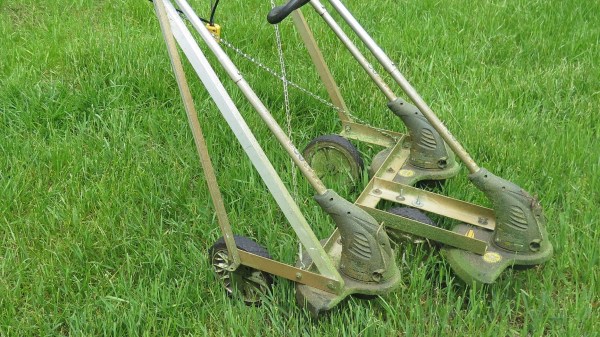
Most lawnmowers can’t even be set high enough for healthy grass so [nodemcu12ecanada] took three electric weed whackers and bolted them to an angle iron frame. It has a lot of advantages. It’s light. You don’t need to sharpen a blade. It’s quiet. It’s electric. It’s strange appearance will scare your neighbors off from borrowing any of your tools. We love it!

Skid Steer Mows Airport Grass Autonomously

Sure, mowing the lawn is a hassle. No one really wants to spend their time and money growing a crop that doesn’t produce food, but we do it anyway. If you’re taking care of a quarter acre in the suburbs it’s not that much of a time sink, but if you’re taking care of as much grass as [Roby], you’d probably build something similar to his autonomous skid-steer mower, too.

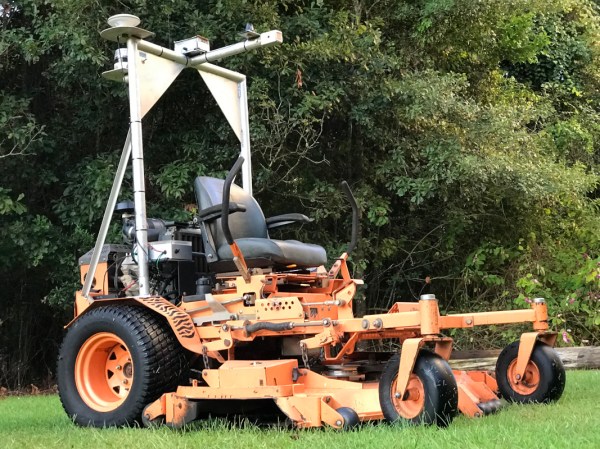
This thing isn’t a normal push mower outfitted with some random electronics, either. This is a serious mower that is essentially a tractor with blades attached to it. Since it’s a skid steer, it turns by means of two handles that control the speed of the left or right drive wheels. Fabricating up some servo linkages to attach them to specialized servos takes care of the steering portion, and the brain is ArduPilot hooked up to a host of radios, GPS, and a compass to allow it to drive all around the runways at the airport without interfering with any aircraft.

This is a serious build and goes into a lot of detail about how servos and linkages should behave, how all the software works, and the issues of actually mounting everything to the mower. The entire project is open source too, so even if you don’t have a whole airport runway to mow you might be able to find something in there to help with your little patch of grass.

Thanks to [Vincent] for the tip!

Continue reading “Skid Steer Mows Airport Grass Autonomously” →

Rechargeable Robot Mows Lawns

Perhaps one day our robot overlords will look back on all of the trivial things that humans made them do and take retribution on us. Until then, though, there’s no problem having them perform all of our chores. [v.loschiavo] is also exploiting our future rulers and built a robot that mows his lawn automatically as his entry into the 2018 Hackaday Prize.

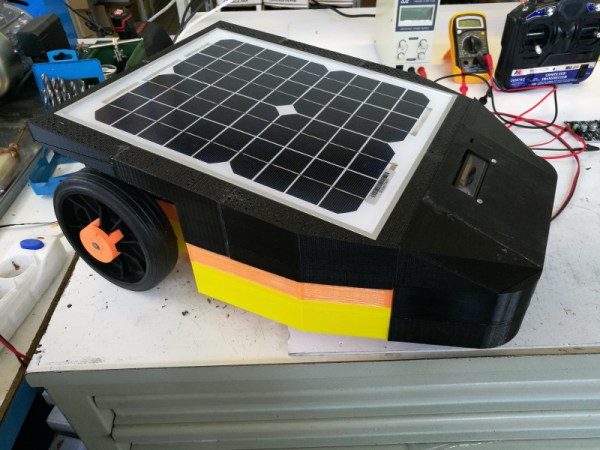
The robot uses a rechargeable battery system to drive a nylon blade for grass cutting. It also has an obstacle detection and avoidance system that allows it to find the borders of your yard and keep from getting stuck against shrubs and flower beds. And don’t worry about safety, either. There’s a built-in system of sensors that prevents any injuries from occurring. The robot also has a 10 Watt solar panel on the top that helps recharge the battery, but it can also recharge at a base station similar to a Roomba.

The whole robot was 3D printed with the exception of some parts like the cutting motor, solar panel, and gear motors. While nothing except for the pictures and a general overview of the robot has been posted to the project page yet, we hope [v.loschiavo] updates the project with the G-code files, code, and schematics so we can build our own.