Tiny Two-Legged PCB Robot

YouTuber and electronics engineer [Carl Bugeja] has a knack for finding creative uses for flexible PCBs. For the past year, he has been experimenting with PCB motors, using them on drones, robot fish, and most recently swarm robots. This is his final video in the vibro-bot series, and he’s got his best results to date. (Embedded below.)

He started off with flexible PCB actuators as robotic legs and magnets fitted into 3D-printed shells. The flexible PCB actuators work as inefficient electromagnets, efficient enough to react to a magnet when a current runs through, but not so efficient that they don’t release immediately.

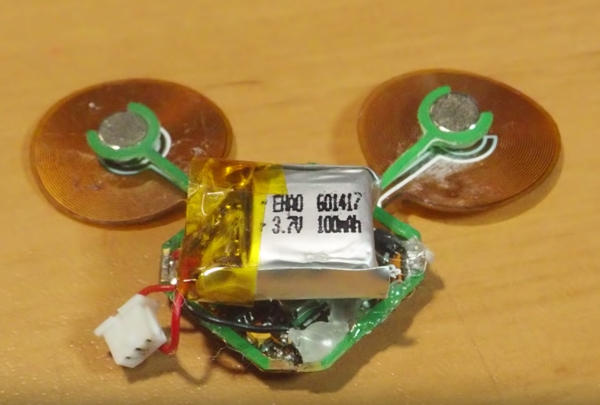
The most recent design uses a rigid 0.6 mm FR4 PCB that acts as the frame to prevent the middle of the robot from bending. The “brain” of the robot is located at its center, which is connected to the flexible PCB actuators. Since the biggest constraint on his past robots was weight, he removed two of the legs to reduce the weight by 20%, resulting in straighter walks. He also added a Bluetooth module to wirelessly control the robot and replaced his old LiPo with a new, lighter battery (28 mAh, 15 C, 420 mA).

His latest video now shows that the robot is able to move forwards, backwards, and side to side. That’s a huge improvement over his previous attempts, which mostly resulted in the robot vibrating in place or flopping around his workbench. It’s not going to fetch you a beer, but it’s really cool.
Continue reading “Tiny Two-Legged PCB Robot” →

[Jessica] Is Soft On Robot Grippers

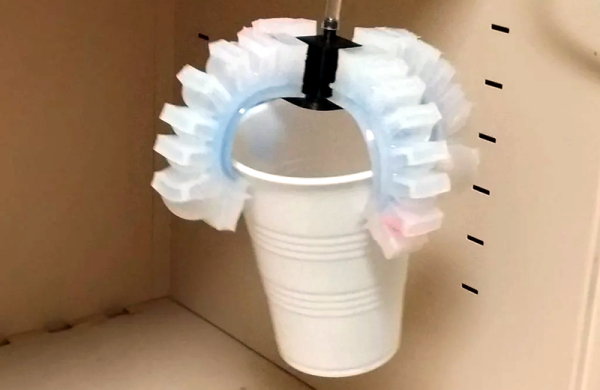
It is an old movie trope: a robot grips something and accidentally crushes it with its super robot strength. A little feedback goes a long way, of course, but futuristic robots may also want to employ soft grippers. [Jessica] shows how to build soft grippers made of several cast fingers. The fingers are cast from Ecoflex 00-50, and use air pressure.

A 3D-printed mold is used to cast the Ecoflex fingers, which are only workable for 18 minutes after mixing, so it’s necessary to work fast and have everything ready before you start.

Continue reading “[Jessica] Is Soft On Robot Grippers” →

DIY Personal Assistant Robot Hears And Sees All

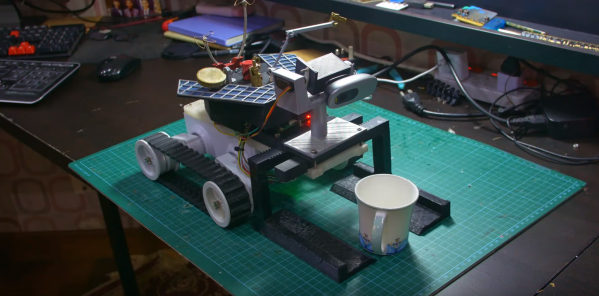
Who wouldn’t want a robot that can fetch them a glass of water? [Saral Tayal] didn’t just think that, he jumped right in and built his own personal assistant robot. This isn’t just some remote-controlled rover though. The robot actually listens to his voice and recognizes his face.

The body of the robot is the common “Rover 5” platform, to which [Saral] added a number of 3D printed parts. A forklift like sled gives the robot the ability to pick things up. Some of the parts are more about form than function – [Saral] loves NASA’s Spirit and Opportunity Mars rovers, so he added some simulated solar cells and other greebles.

The Logitech webcam up front is very functional — images are fed to machine learning models, while audio is processed to listen for commands. This robot can find and pick up 90 unique objects.

The robot’s brains are a Raspberry Pi. It uses TensorFlow for object recognition. Some of the models [Saral] is using are pretty large – so big that the Pi could only manage a couple of frames per second at 100% CPU utilization. A Google Coral coprocessor sped things up quite a bit, while only using about 30% of the Pi’s processor.

It takes several motors to control to robot’s tracks and sled. This is handled by two Roboclaw motor controllers which themselves are commanded by the Pi.

We’ve seen quite a few mobile robot rovers over the years, but [Saral’s] ‘bot is one of the most functional designs out there. Even better is the fact that it is completely open source. You can find the code and 3D models on his GitHub repo.

Check out a video of the personal assistant rover in action after the break.

Continue reading “DIY Personal Assistant Robot Hears And Sees All” →

Etch-A-Selfie

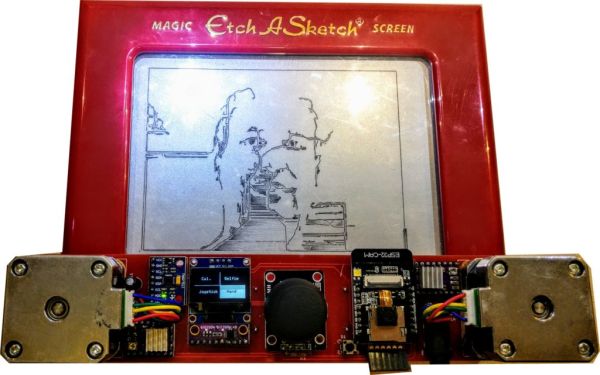
Taking a selfie before the modern smartphone era was a true endeavor. Flip phones didn’t have forward-facing cameras, and if you want to go really far back to the days of film cameras, you needed to set a timer on your camera and hope, or get a physical remote shutter. You could also try and create a self portrait on an Etch a Sketch, too, but this would take a lot of time and artistic skill. Luckily in the modern world, we can bring some of this old technology into the future and add a robot to create interesting retro selfies – without needing to be an artist.

The device from [im-pro] attaches two servos to the Etch a Sketch knobs. This isn’t really a new idea in itself, but the device also includes a front-facing camera, taking advantage of particularly inexpensive ESP32 Camera modules. Combining the camera features with [Bart Dring]’s ESP32 Grbl port is a winner. Check the code in [im-pro]’s GitHub.

Once the picture is taken, the ESP32 at the heart of the build handles the image processing and then drawing the image on the Etch a Sketch. The robot needs a black and white image to draw, and an algorithm for doing it without “lifting” the drawing tool, and these tasks stretch the capabilities of such a small processor. It takes some time to work, but in the end the results speak for themselves.

The final project is definitely worth looking for, if not for the interesting ESP32-controlled robot than for the image processing algorithim implementation. The ESP32 is a truly versatile platform, though, and is useful for building almost anything.

Continue reading “Etch-A-Selfie” →

Punch The World With A Raspberry Pi

Robots have certainly made the world a better place. Virtually everything from automobile assembly to food production uses a robot at some point in the process, not to mention those robots that can clean your house or make your morning coffee. But not every robot needs such a productive purpose. This one allows you to punch the world, which while not producing as much physical value as a welding robot in an assembly line might, certainly seems to have some therapeutic effects at least.

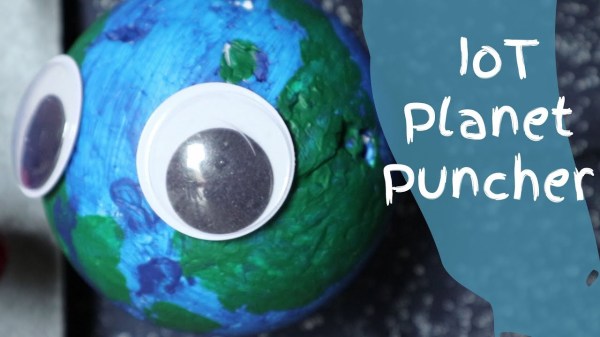
The IoT Planet Puncher comes to us from [8BitsAndAByte] who build lots of different things of equally dubious function. This one allows us to release our frustration on the world by punching it (or rather, a small model of it). A small painted sphere sits in front of a 3D-printed boxing glove mounted on a linear actuator. The linear actuator is driven by a Raspberry Pi. The Pi’s job doesn’t end there, though, as the project also uses a Pi camera to take video of the globe and serve it on a webpage through which anyone can control the punching glove.

While not immediately useful, we certainly had fun punching it a few times, and once a mysterious hand entered the shot to make adjustments to the system as well. Projects like this are good fun, and sometimes you just need to build something, even if it’s goofy, because the urge strikes you. Continue reading “Punch The World With A Raspberry Pi” →

A 3D-Printable Mecanum Wheeled Robot Platform

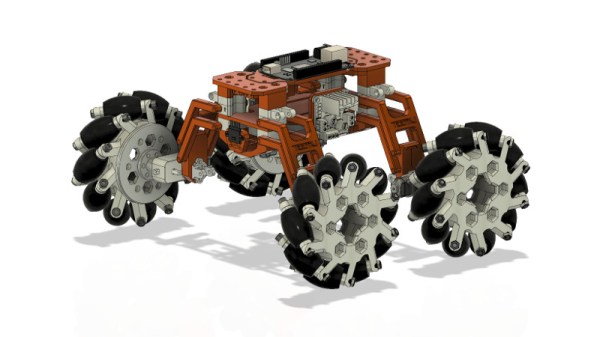
If your interest lies with robotics there are a multitude of different platforms for you to build. [Teemu Laurila] was frustrated with what was on offer, so designed his own with four-wheel double wishbone suspension and mecanum wheels for maximum flexibility.

It’s a design that has been through multiple revisions since its first iteration in 2015, and along the way it’s clear some thought has gone into it. That double wishbone suspension features an angle for a high ground clearance, and is fully sprung. Drive comes from small motor/gearboxes at each axle. The chassis meanwhile has plenty of space for a single-board computer, and has been specifically designed with the BeagleBone Black in mind.

This build isn’t fully DIY, as the mecanum wheels appear to be off-the-shelf items, but the rest of the project makes up for this. If you need to make your own, it’s hardly as though there aren’t any projects from which you can borrow components.

Continue reading “A 3D-Printable Mecanum Wheeled Robot Platform” →

Robot Harvesting Machine Is Tip Of The Agri-Tech Iceberg

Harvesting delicate fruit and vegetables with robots is hard, and increasingly us humans no longer want to do these jobs. The pressure to find engineering solutions is intense and more and more machines of different shapes and sizes have recently been emerging in an attempt to alleviate the problem. Additionally, each crop is often quite different from one another and so, for example, a strawberry picking machine can not be used for harvesting lettuce.

A team from Cambridge university, UK, recently published the details of their lettuce picking machine, written in a nice easy-to-read style and packed full of useful practical information. Well worth a read!

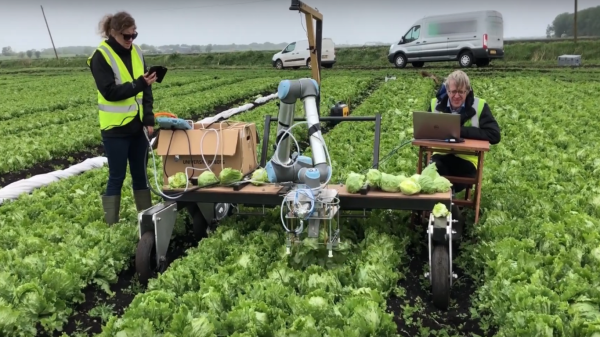
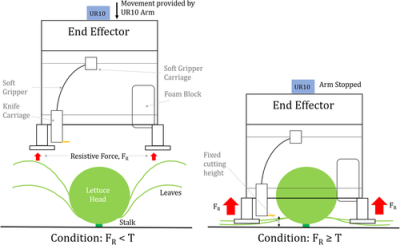
The machine uses YOLO3 detection and classification networks to get localisation coordinates of the crop and then check if it’s ready for harvest, or diseased. A standard UR10 robotic arm then positions the harvesting mechanism over the lettuce, getting force feedback through the arm joints to detect when it hits the ground. A pneumatically actuated cutting blade then attempts to cut the lettuce at exactly the right height below the lettuce head in order to satisfy the very exacting requirements of the supermarkets.

Rather strangely, the main control hardware is just a standard laptop which handles 2 consumer grade USB cameras with overall combined detection and classification speeds of about 0.212 seconds. The software is ROS (Robot Operating System) with custom nodes written in Python by members of the team.

Although the machine is slow and under-powered, we were very impressed with the fact that it seemed to work quite well. This particular project has been ongoing for several years now and the machine rebuilt 16 times! These types of machines are currently (2019) very much in their infancy and we can expect to see many more attempts at cracking these difficult engineering tasks in the next few years.

We’ve covered some solutions before, including: Weedinator, an autonomous farming ‘bot, MoAgriS, an indoor farming rig, a laser-firing fish-lice remover, an Aussie farming robot, and of course the latest and greatest from FarmBot.

Video after the break:

Continue reading “Robot Harvesting Machine Is Tip Of The Agri-Tech Iceberg” →