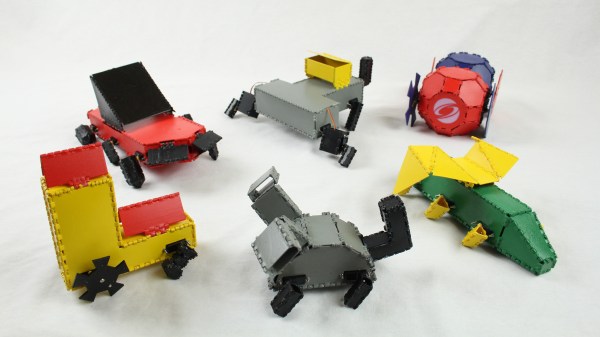
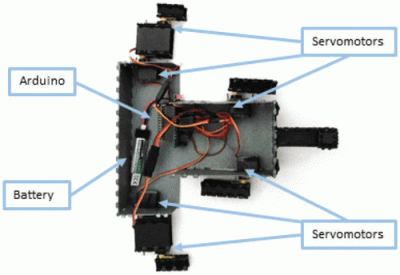
Internals of 3D printed “print and fold” robot. [Image source: MIT CSAIL]Robot design traditionally separates the body geometry from the mechanics of the gait, but they both have a profound effect upon one another. What if you could play with both at once, and crank out useful prototypes cheaply using just about any old 3D printer? That’s where Interactive Robogami comes in. It’s a tool from MIT’s Computer Science and Artificial Intelligence Laboratory (CSAIL) that aims to let people design, simulate, and then build simple robots with a “3D print, then fold” approach. The idea behind the system is partly to take advantage of the rapid prototyping afforded by 3D printers, but mainly it’s to change how the design work is done.
To make a robot, the body geometry and limb design are all done and simulated in the Robogami tool, where different combinations can have a wild effect on locomotion. Once a design is chosen, the end result is a 3D printable flat pack which is then assembled into the final form with a power supply, Arduino, and servo motors.
A white paper is available online and a demonstration video is embedded below. It’s debatable whether these devices on their own qualify as “robots” since they have no sensors, but as a tool to quickly prototype robot body geometries and gaits it’s an excitingly clever idea.
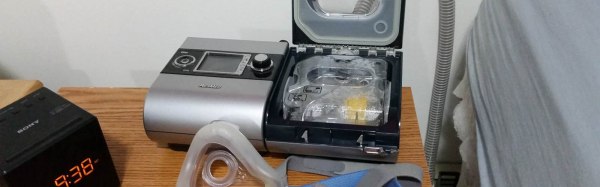
CPAP (Continuous Positive Airway Pressure) machines can be life-changing for people with sleep apnea. [Scott Clandinin] benefits from his CPAP machine and devised a way to improve his quality of life even further with a non-destructive modification to monitor his machine’s humidifier.
With a CPAP machine, all air the wearer breathes is air that has gone through the machine. [Scott]’s CPAP machine has a small water reservoir which is heated to humidify the air before it goes to the wearer. However, depending on conditions the water reservoir may run dry during use, leading to the user waking up dried out and uncomfortable.
To solve this in a non-invasive way that required no modifications to the machine itself, [Scott] created a two-part device. The first part is a platform upon which the CPAP machine rests. A load cell interfaced to an HX711 Load Cell Amplifier allows an Arduino Nano to measure the mass of the CPAP machine plus the integrated water reservoir. By taking regular measurements, the Arduino can detect when the reservoir is about to run dry and sound an alarm. Getting one’s sleep interrupted by an alarm isn’t a pleasant way to wake up, but it’s much more pleasant than waking up dried out and uncomfortable from breathing hot, dry air for a while.
The second part of the device is a simple button interfaced to a hanger for the mask itself. While the mask is hung up, the system is idle. When the mask is removed from the hook, the system takes measurements and goes to work. This makes activation hassle-free, not to mention also avoids spurious alarms while the user removes and fills the water reservoir.
Non-invasive modifications to medical or other health-related devices is common, and a perfect example of nondestructive interfacing is the Eyedriveomatic which won the 2015 Hackaday Prize. Also, the HX711 Load Cell Amplifier has an Arduino library that was used in this bathroom scale refurb project.
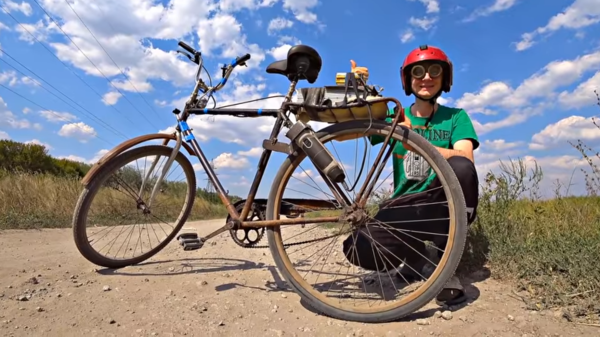
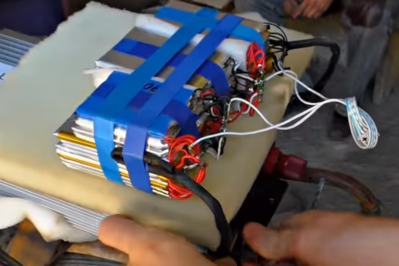
When it comes to bringing an idea to life it’s best to have both a sense of purpose, and an eagerness to apply whatever is on hand in order to get results. YouTube’s favorite Ukrainians [KREOSAN] are chock full of both in their journey to create this incredible DIY e-bike using an angle grinder with a friction interface to the rear wheel, and a horrifying battery pack made of cells salvaged from what the subtitles describe as “defective smartphone charging cases”.
Battery pack made from cells salvaged out of defective equipment. Sometimes, you use what you have on hand.
What’s great to see is the methodical approach taken to creating the bike. [KREOSAN] began with an experiment consisting of putting a shaft on the angle grinder and seeing whether a friction interface between that shaft and the tire could be used to move the rear wheel effectively. After tweaking the size of the shaft, a metal clamp was fashioned to attach the grinder to the bike. The first test run simply involved a long extension cord. From there, they go on to solve small problems encountered along the way and end up with a simple clutch system and speed control.
The end result appears to work very well, but the best part is the pure joy (and sometimes concern) evident in the face of the test driver as he reaches high speeds on a homemade bike with a camera taped to his chest. Video is embedded below.
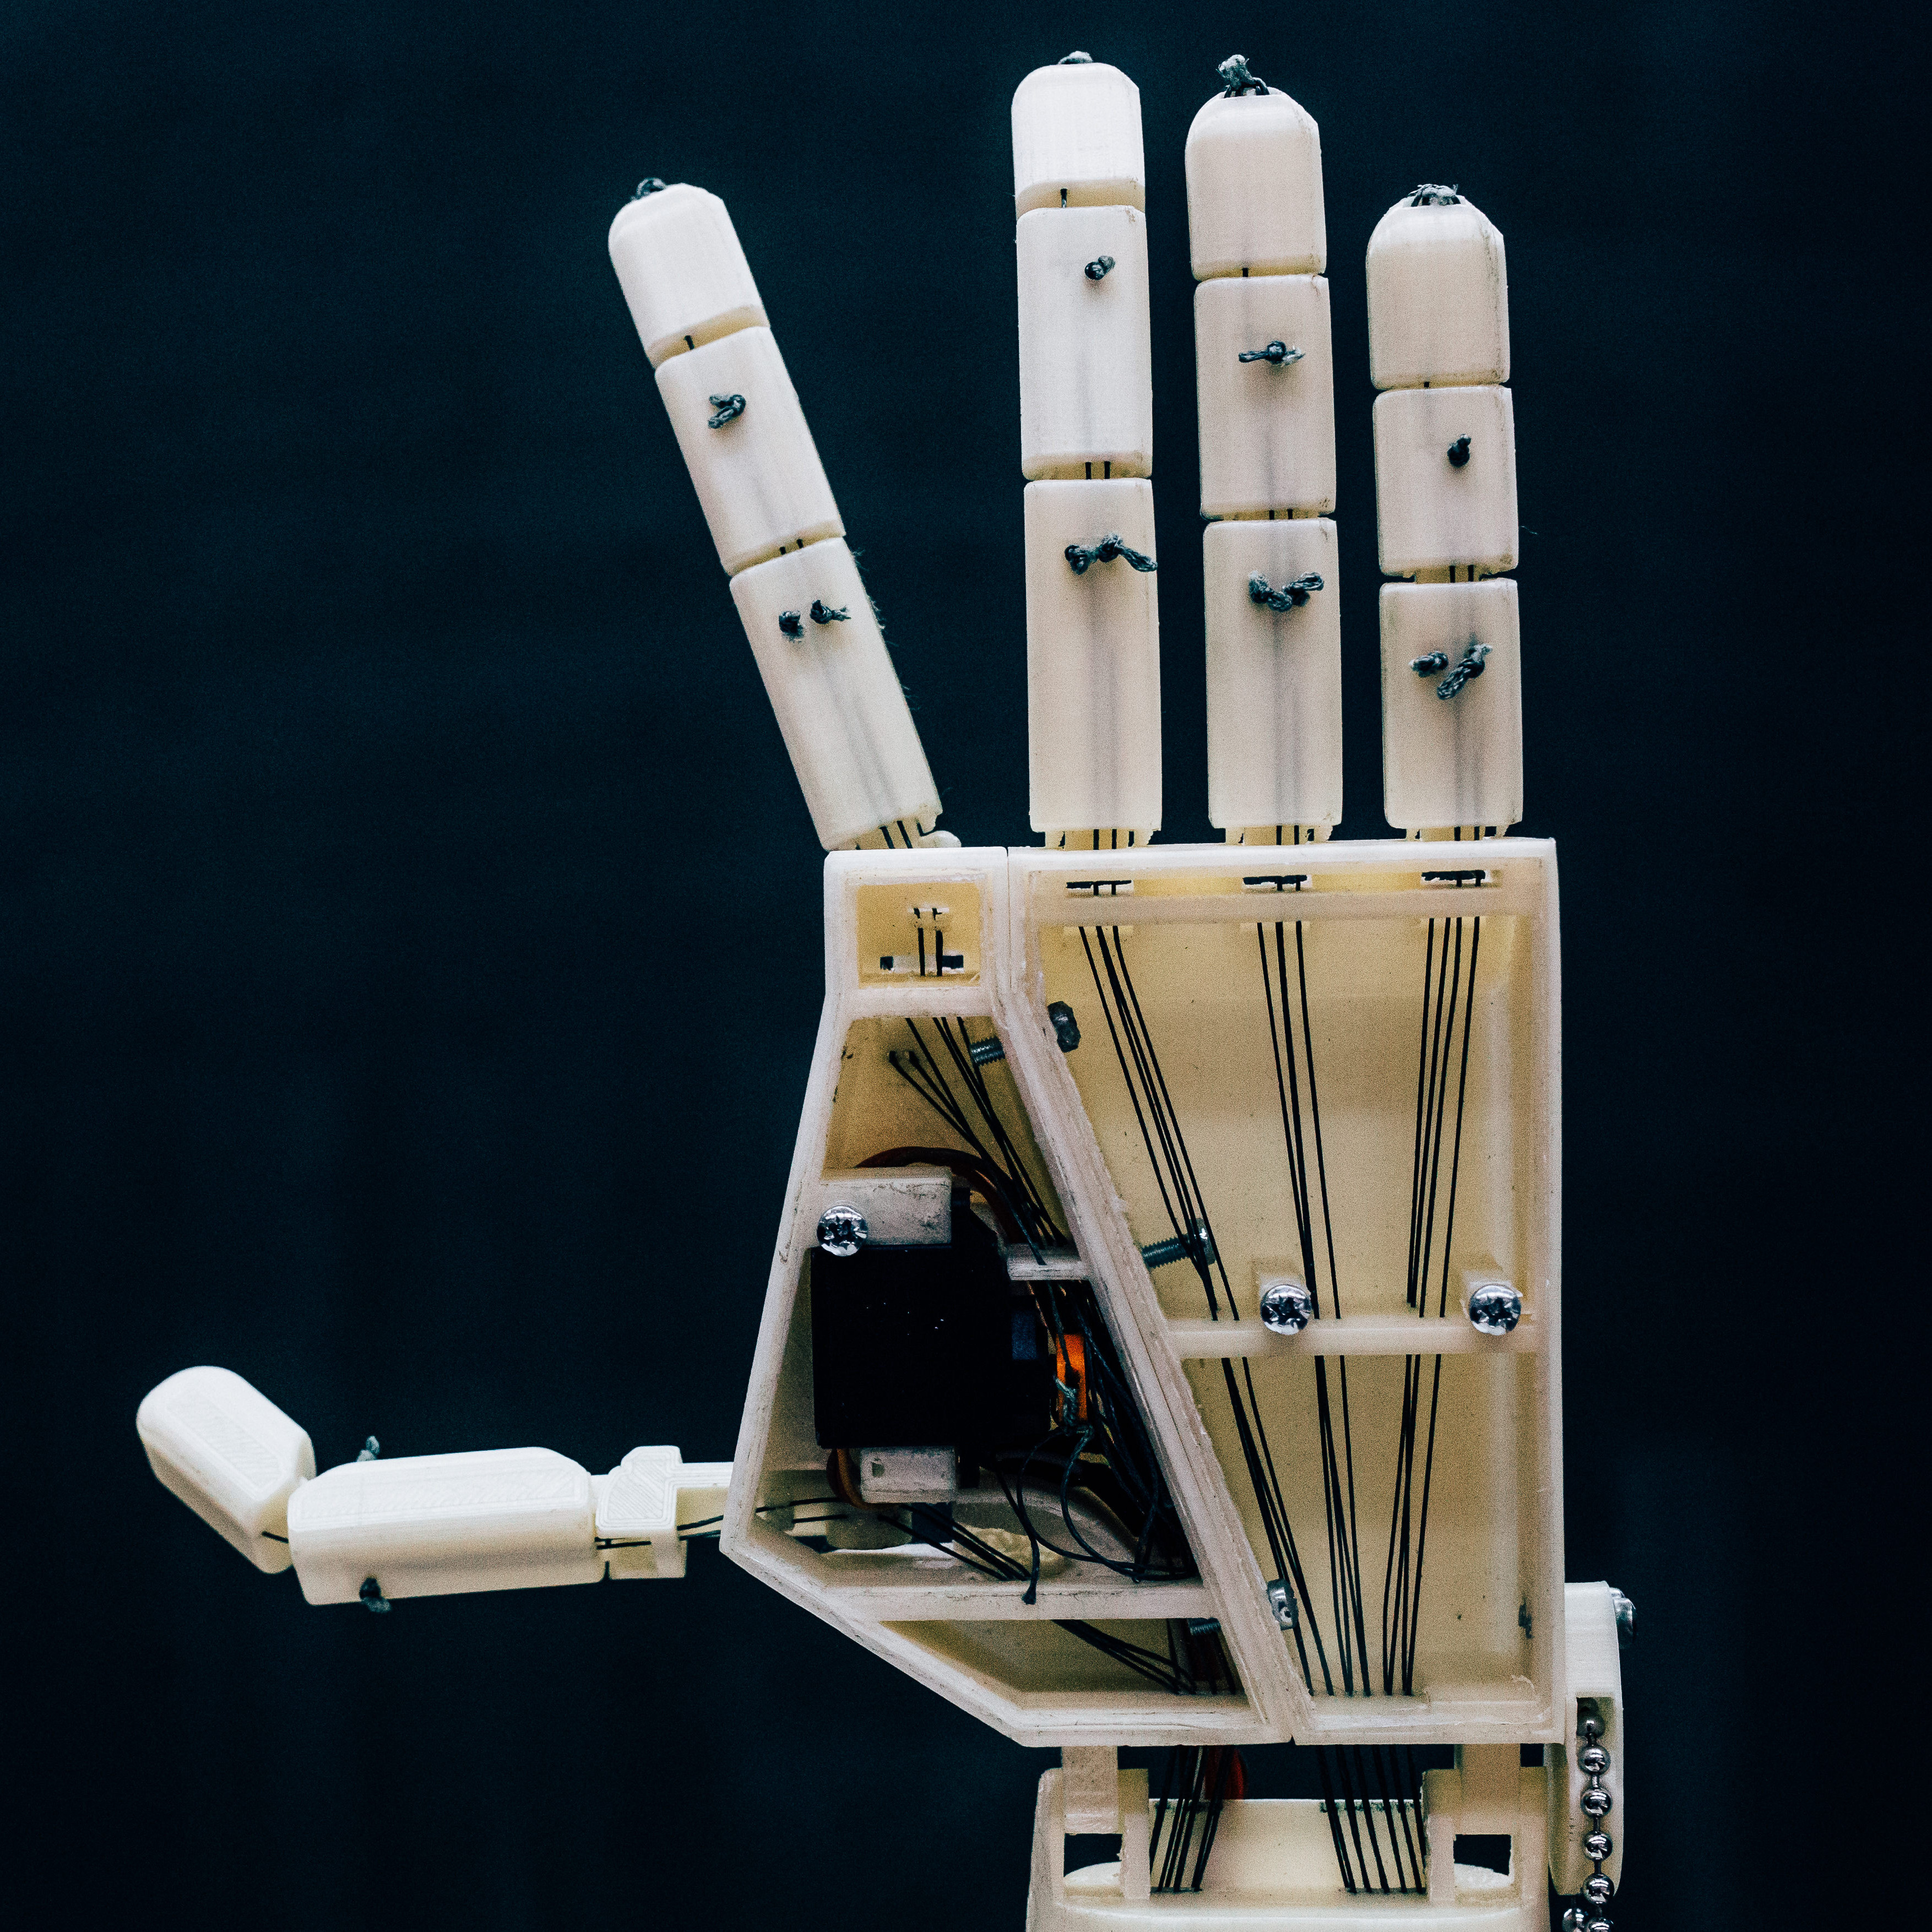
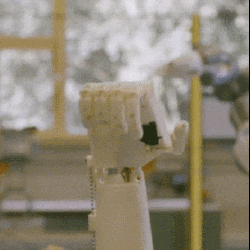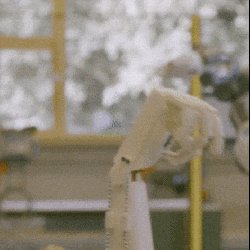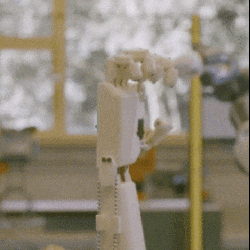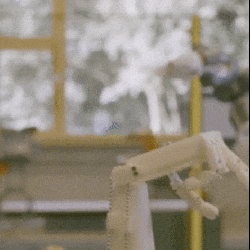
A team of students in Antwerp, Belgium are responsible for Project Aslan, which is exploring the feasibility of using 3D printed robotic arms for assisting with and translating sign language. The idea came from the fact that sign language translators are few and far between, and it’s a task that robots may be able to help with. In addition to translation, robots may be able to assist with teaching sign language as well.
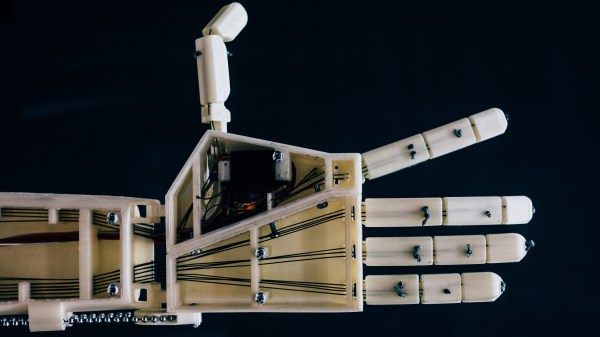
The project set out to use 3D printing and other technology to explore whether low-cost robotic signing could be of any use. So far the team has an arm that can convert text into finger spelling and counting. It’s an interesting use for a robotic arm; signing is an application for which range of motion is important, but there is no real need to carry or move any payloads whatsoever.
Closeup of hand actuators and design. Click to enlarge.
A single articulated hand is a good proof of concept, and these early results show some promise and potential but there is still a long ways to go. Sign language involves more than just hands. It is performed using both hands, arms and shoulders, and incorporates motions and facial expressions. Also, the majority of sign language is not finger spelling (reserved primarily for proper names or specific nouns) but a robot hand that is able to finger spell is an important first step to everything else.
Future directions for the project include adding a second arm, adding expressiveness, and exploring the use of cameras for the teaching of new signs. The ability to teach different signs is important, because any project that aims to act as a translator or facilitator needs the ability to learn and update. There is a lot of diversity in sign languages across the world. For people unfamiliar with signing, it may come as a surprise that — for example — not only is American Sign Language (ASL) related to French sign language, but both are entirely different from British Sign Language (BSL). A video of the project is embedded below.
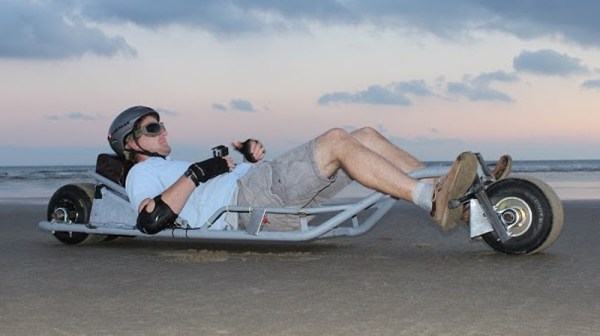
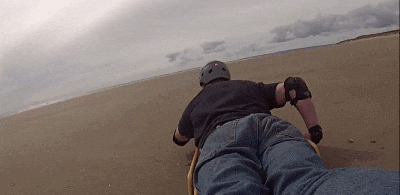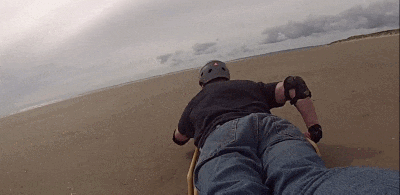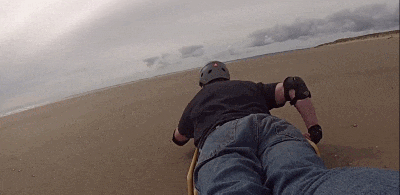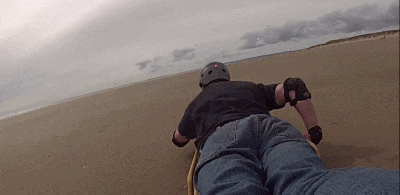
[John Dingley] describes his Electric Beach Luge Project as an exciting mashup between “a downhill luge board, a kite surf buggy, a go-kart, and a Star Wars Land Speeder” and it’s fresh from a successful test run. What’s not to like? The DIY experimental vehicle was made to run on long, flat, firm stretches of sand while keeping the rider as close to the ground as possible. The Beach Luge is mainly intended to be ridden while lying on one’s back, luge-style, but it’s also possible to lay prone in the “Superman” position.
The whole unit was built from the ground up, but [John] points out that the design isn’t particularly complicated. There is no fancy self-balancing or suspension involved and steering is simple. A tube bender and a welder took care of making the frame. The rest is mainly used go-kart parts obtained cheaply from eBay, driven by a 500W 24V electric motor from an old Golf Kart. Like a luge sled, the goal is for the vehicle itself to interfere as little as possible between the user and the earth to make the experience as visceral as it can be.
You can see it in action in the two videos embedded below, but even more videos and some great pictures are available on the project’s page. [John] says it’s great fun to ride, but feels it could use twice as much power!
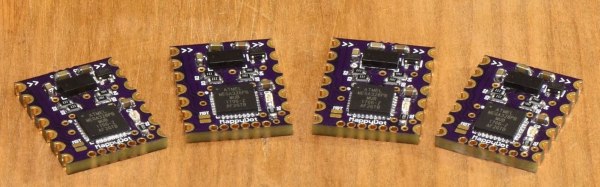
[Blecky]’s entry to the Hackaday Prize is MappyDot, a tiny board less than a square inch in size that holds a VL53L0X time-of-flight distance sensor and can measure distances of up to 2 meters.
MappyDot is more than just a breakout board; the ATMega328PB microcontroller on each PCB provides filtering, an easy to use I2C interface, and automatically handles up to 112 boards connected in a bus. The idea is that one or a few MappyDots can be used by themselves, but managing a large number is just as easy. By dotting a device with multiple MappyDots pointing in different directions, a device could combine the readings to gain a LiDAR-like understanding of its physical environment. Its big numbers of MappyDots [Blecky] is going for, too: he just received a few panels of bare PCBs that he’ll soon be laboriously populating. The good news is, there aren’t that many components on each board.
It’s great to see open sourced projects and tools in which it is clear some thought has gone into making them flexible and easy to use. This means they are easier to incorporate into other work and helps make them a great contestant for the Hackaday Prize.
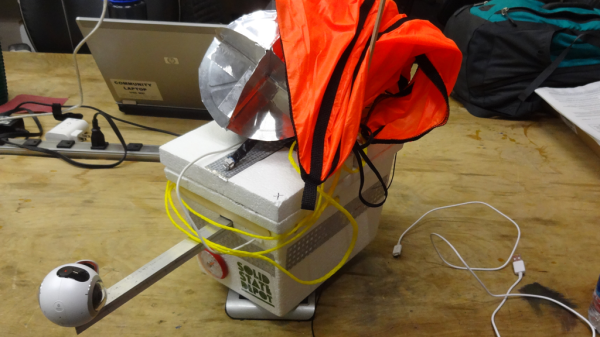
[Dan Julio] let us know about an exciting project that he and his team are working on at the Solid State Depot Makerspace in Boulder: the Solar Eclipse High Altitude Balloon. Weighing in at 1 kg and bristling with a variety of cameras, the balloon aims to catch whatever images are able to be had during the solar eclipse. The balloon’s position should be trackable on the web during its flight, and some downloaded images should be available as well. Links for all of that are available from the project’s page.
High altitude balloons are getting more common as a platform for gathering data and doing experiments; an embedded data recorder for balloons was even an entry for the 2016 Hackaday Prize.
If all goes well and the balloon is able to be recovered, better images and video will follow. If not, then at least a post-mortem of what the team thinks went wrong will be posted. Launch time in Wyoming is approximately 10:40 am Mountain Time (UTC -07:00) Mountain Daylight Time (UTC -06:00) on Aug 21 2017, so set your alarm!

 A team of students in Antwerp, Belgium are responsible for